


Introduction to Mechatronics Engineering


Introduction to mechatronics engineering through the integrated design of mechanics, electronics, measurement, embedded computing, power conversion, control, and actuation.
Mechatronics engineering is not the practice of completing a mechanical product and then adding electronics and software. The physical plant, sensing, computation, power conversion, actuation, and feedback are designed against the same system requirements. A subsystem can be locally correct while the complete system behaves poorly because mechanical inertia, sensor bandwidth, sampling period, computation latency, drive limits, and actuator capability belong to the same closed loop.
This course connects the foundations established in Circuit Theory, Electronics I and II, Signals and Systems, and Microprocessors to a physical system. It does not reteach those subjects; it defines their interfaces and their roles in an integrated engineering workflow.
Unit 1: The Mechatronic System and Its Boundary
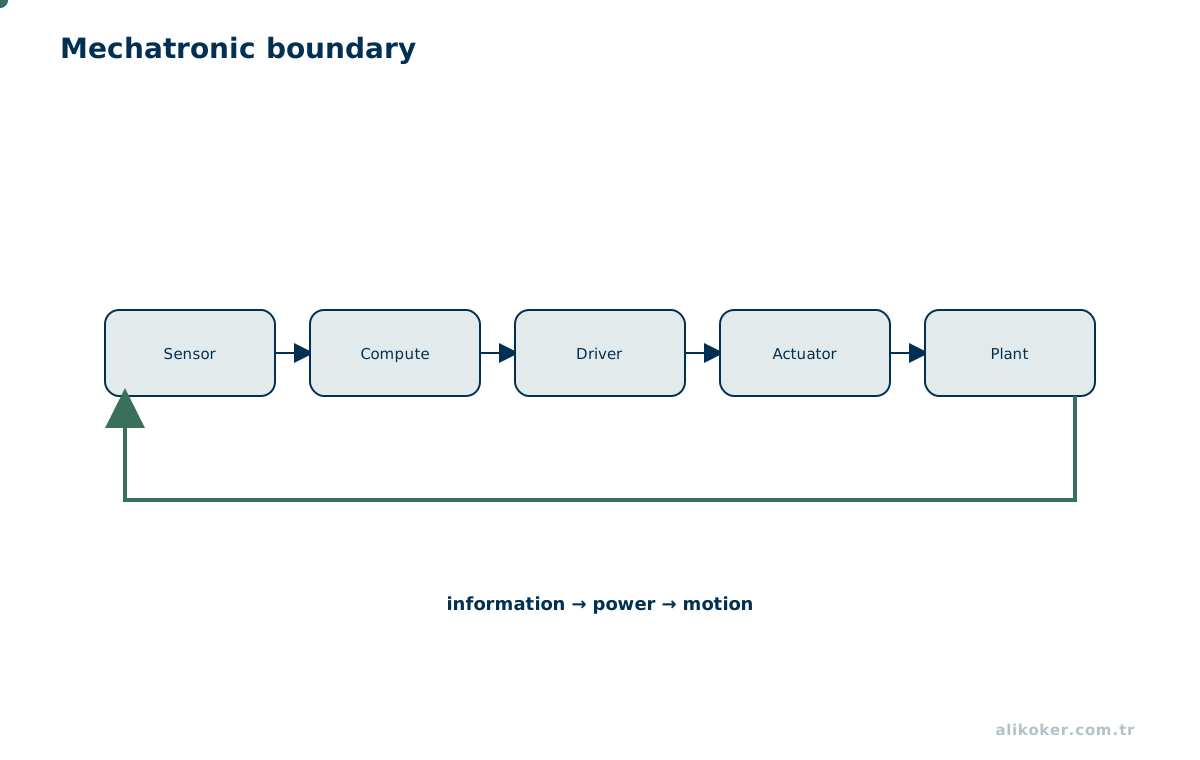
A mechatronic system receives energy and information from its environment, processes them, and produces a physical outcome. Inputs, outputs, states, disturbances, and constraints cannot be defined consistently until the system boundary is chosen.
A typical closed loop is:
reference -> controller -> power stage -> actuator -> physical plant
                  ^                              |
                  |                              v
                  +------ measurement <- sensor -+
Two flows must be followed together. Information flow moves from sensing toward computation and command generation. Energy flow moves from the source through the power stage and actuator to the mechanical load. A valid information path cannot compensate for an undersized energy path.
1.1. From Requirements to the System Boundary
A system boundary is not merely a box on a diagram; it defines which flows of energy, information, and responsibility belong to the design. For a positioning axis, the motor, gearbox, load, encoder, drive, and controller may be inside the same boundary, while the upstream computer or power source may remain external. That decision determines which disturbances are modeled as inputs and which failures are treated as internal faults.
Requirements should be measurable. “Move fast” is replaced by target velocity, settling time, overshoot, repeatability, load range, and ambient temperature. Likewise, “be safe” is not sufficient: the safe state after loss of energy, brake behavior, and faults that require independent hardware protection must be stated. This moves architecture from component selection to an engineering requirements problem.
Unit 2: Concurrent Design
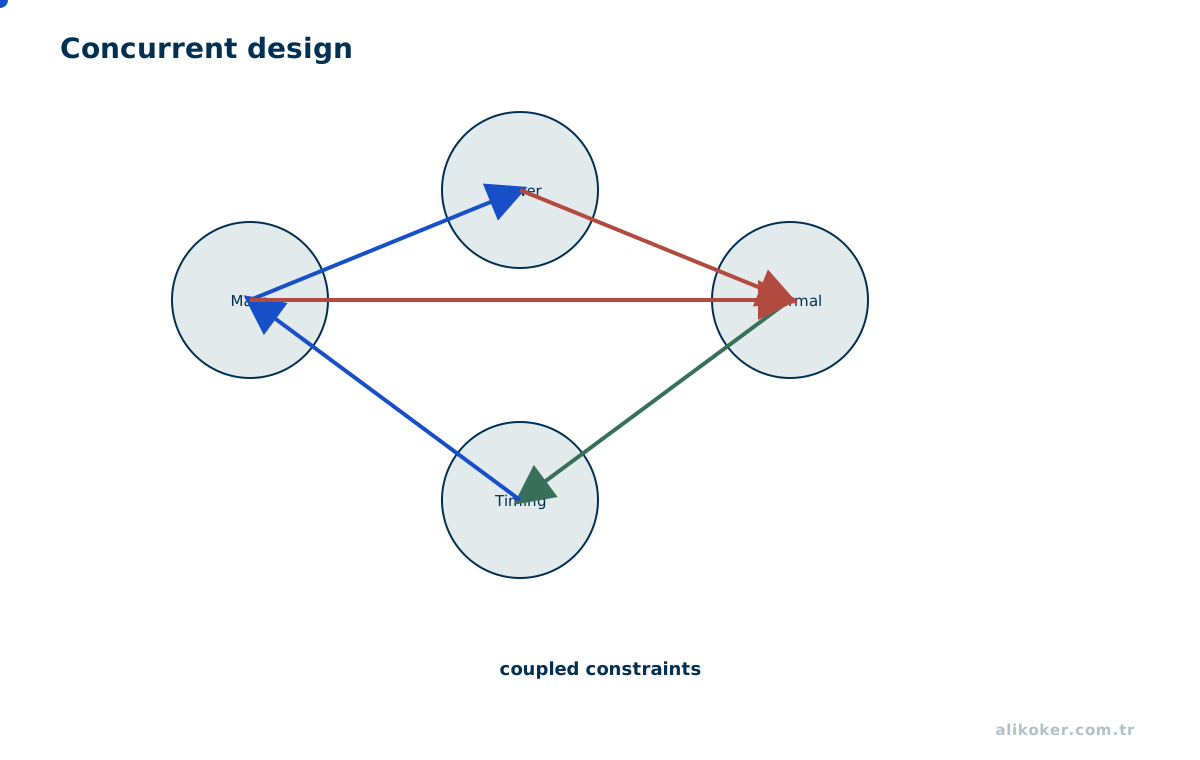
A sequential process may finish the mechanical design first and add electronics, control, and software later. Mechatronic design favors concurrent decisions because those domains are coupled.
Selecting a larger motor changes more than available torque: inertia, drive current, power supply sizing, thermal load, mechanical support, and attainable control bandwidth can all change. Increasing sensor resolution does not remove backlash, noise, or timing error. The objective is therefore not to select the strongest or most accurate individual component, but to satisfy the system requirements with balanced margins.
Concurrent design does not treat mechanical, electronic, and software requirements as independently completed parts. Begin with measurable system-level objectives and limits, then trace each objective to the subsystems on which it depends. Revisit a design choice whenever it changes another subsystem's power, space, sampling, or response-time budget. Compare alternatives under both nominal operation and credible worst-case loads and faults.
2.1. Coupled Design Variables
A single mechatronic parameter often affects several disciplines. Increasing a gear ratio changes reflected inertia, reduces output speed, may increase backlash effects, and modifies the bandwidth available to the controller. A higher-resolution encoder does not automatically improve mechanical accuracy when eccentricity, compliance, or backlash dominates the error budget.
Early design therefore compares candidate architectures rather than searching for one locally “best” component. Mass, power, cost, maintenance, reliability, and controllability are evaluated together. Decisions are checked not only at the nominal operating point but also during startup, stopping, faults, and environmental extremes.
Unit 3: Mechanical Subsystem
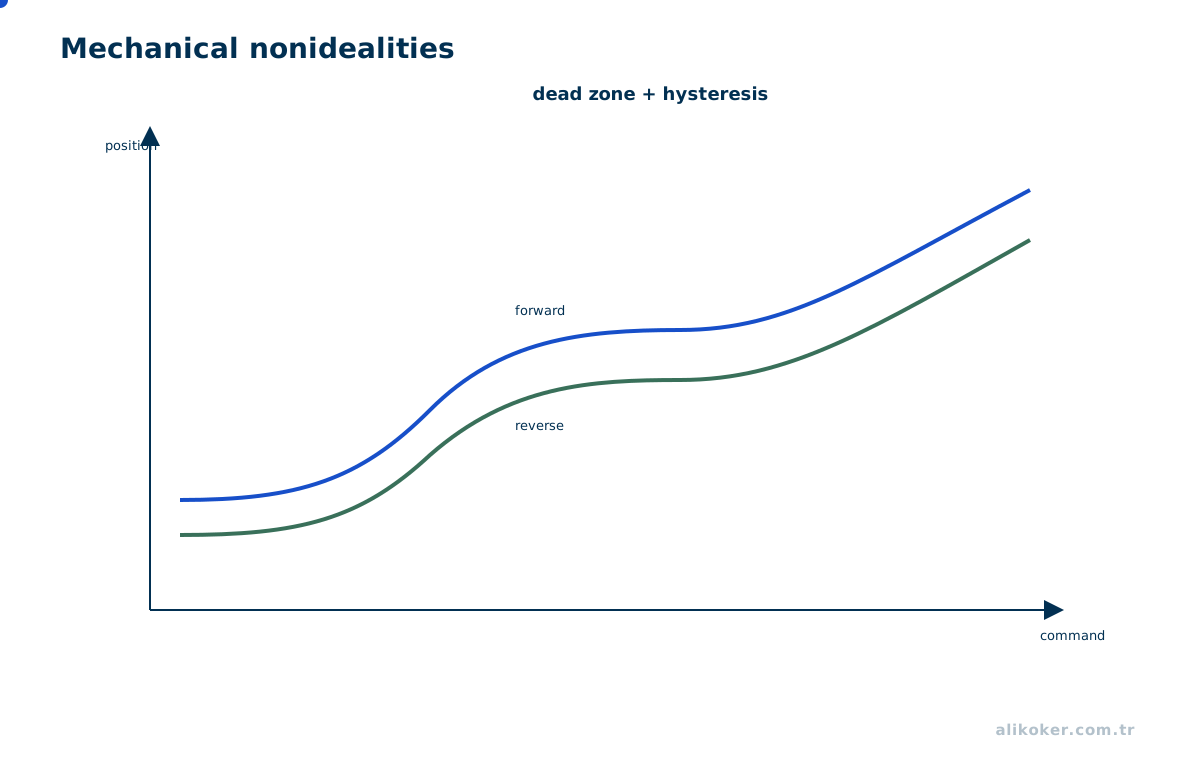
Shafts, bearings, gears, belt drives, couplings, springs, lead screws, and structural elements transmit force and motion. Real mechanisms exhibit friction, backlash, compliance, saturation, and wear.
For an idealized reduction stage:
ω_out=(ω_in)/(N), T_out≈ η N T_inwhere N is the reduction ratio and η is efficiency. Increasing the ratio can raise output torque while reducing speed, and it also changes reflected inertia and closed-loop dynamics.
3.1. Mechanical Nonidealities
Friction, backlash, and compliance are not minor corrections in a closed-loop system. Coulomb friction can create dead-zone-like behavior at low speed, backlash can temporarily decouple command and output after a direction reversal, and flexible shafts or couplings can introduce resonant modes. High-gain position loops can turn these effects into vibration or limit cycles.
Bearing preload, shaft stiffness, critical speed, assembly tolerance, and lubrication create physical limits that software cannot simply remove. A mechatronic design treats control as a partner of the mechanical design, not as a layer intended to hide poor mechanics.
Unit 4: From the Physical Plant to a Model
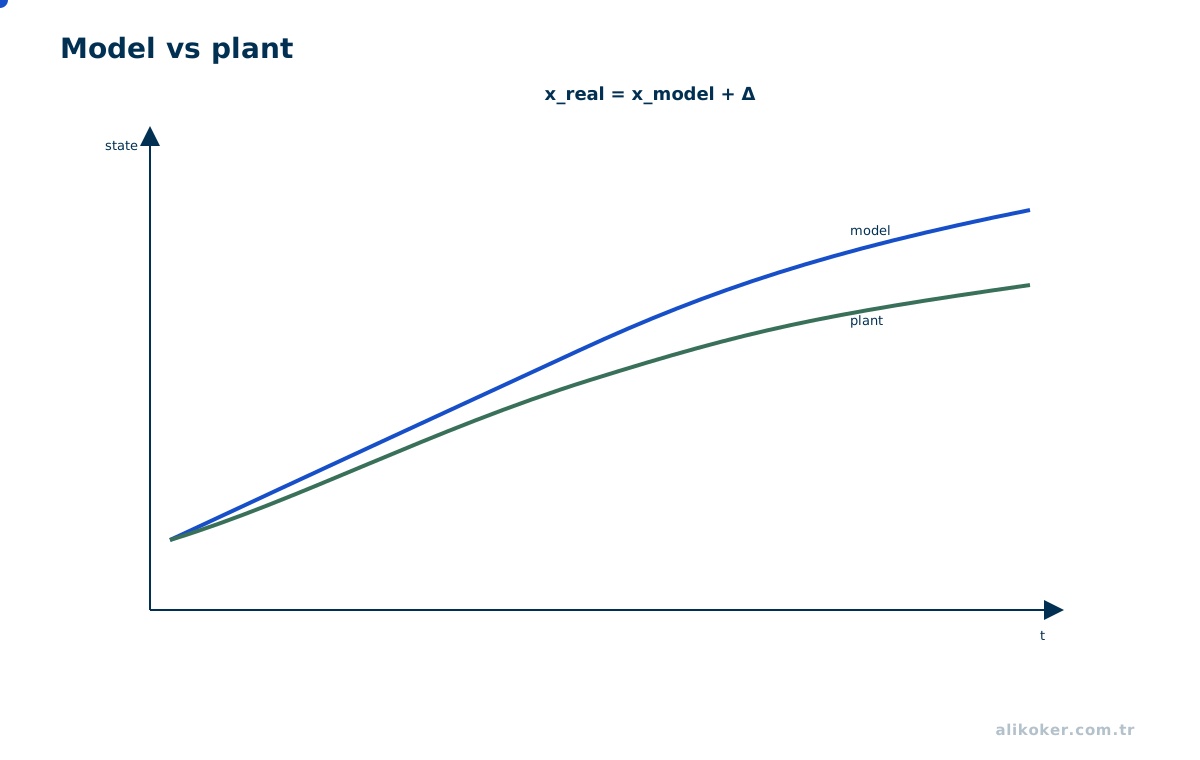
A model is a purpose-dependent representation of the physical system. A rotating load may begin with:
Jdω/dt=T_m-T_L-Bωand the electrical side of a DC motor may be represented by:
V=Ri+L(di)/(dt)+K_eωThese equations are developed in System Modeling and Simulation. Their role here is to show that electrical and mechanical states participate in one physical behavior.
Unit 5: Sensing and Measurement
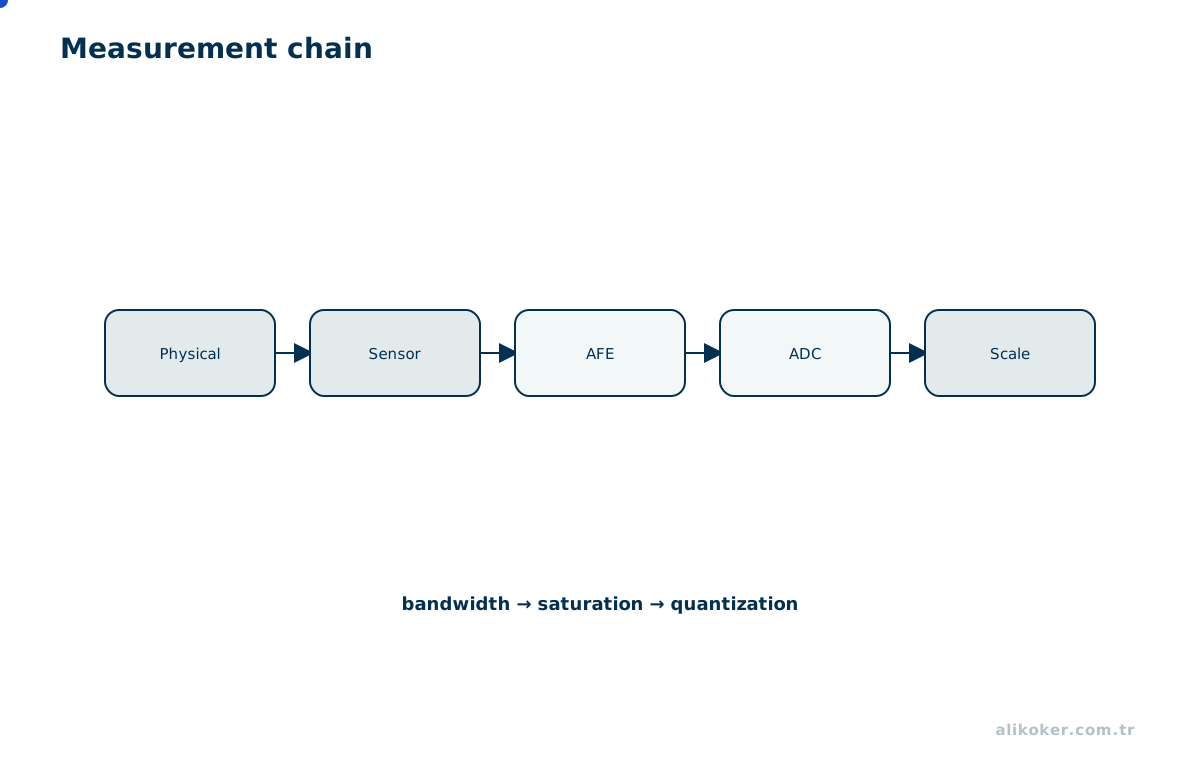
A sensor converts a physical or chemical quantity into a processable signal. A measurement system determines with what accuracy, uncertainty, bandwidth, and timing that signal can be used.
physical quantity
    -> sensor
    -> signal conditioning
    -> ADC / digital interface
    -> scaling and calibration
    -> time-stamped measurement
The conversion physics belongs to Sensors and Sensing Systems; the reliability of the resulting value belongs to Measurement Systems.
Designing a sensing chain starts with the physical quantity of interest and proceeds through sensor range, sampling, conditioning, conversion, and decision stages. At each stage, examine how resolution, noise, delay, and calibration error affect the final result. A higher sampling rate alone does not guarantee better information; analog bandwidth limiting and timestamp accuracy must also be checked. The final decision should rely on a measurement chain demonstrated to distinguish the events of interest.
5.1. Information Loss Along the Measurement Chain
The path from a physical quantity to a digital value contains multiple irreversible operations. The sensor has dynamics, the analog front end imposes gain and bandwidth, the ADC quantizes, and software scales and timestamps the result. Once a stage saturates, later processing cannot reconstruct the missing information.
A high sampling rate cannot restore vibration content that was already removed by a low-bandwidth sensor. Similarly, digital filtering cannot reliably remove aliasing created before sampling. Measurement must therefore preserve amplitude, timing, and validity information as one engineering chain.
Unit 6: Electronic Interface
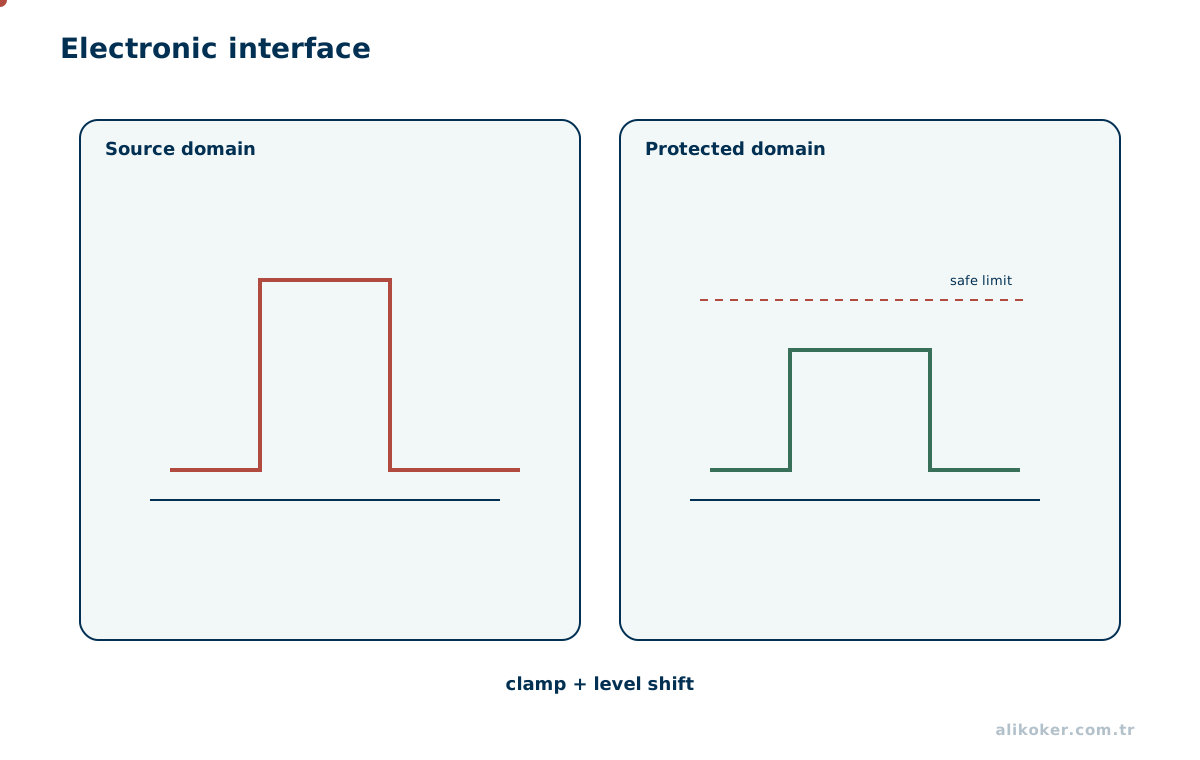
Sensor outputs and controller inputs are rarely ideal matches. Amplification, filtering, buffering, galvanic isolation, level translation, ADC/DAC conversion, and protection may be required.
The device-level foundation is covered in Electronics I and II. At system level, the interface must provide sufficient bandwidth, dynamic range, and error margin without materially disturbing the quantity being observed.
Unit 7: Embedded Computation and Real-Time Behavior
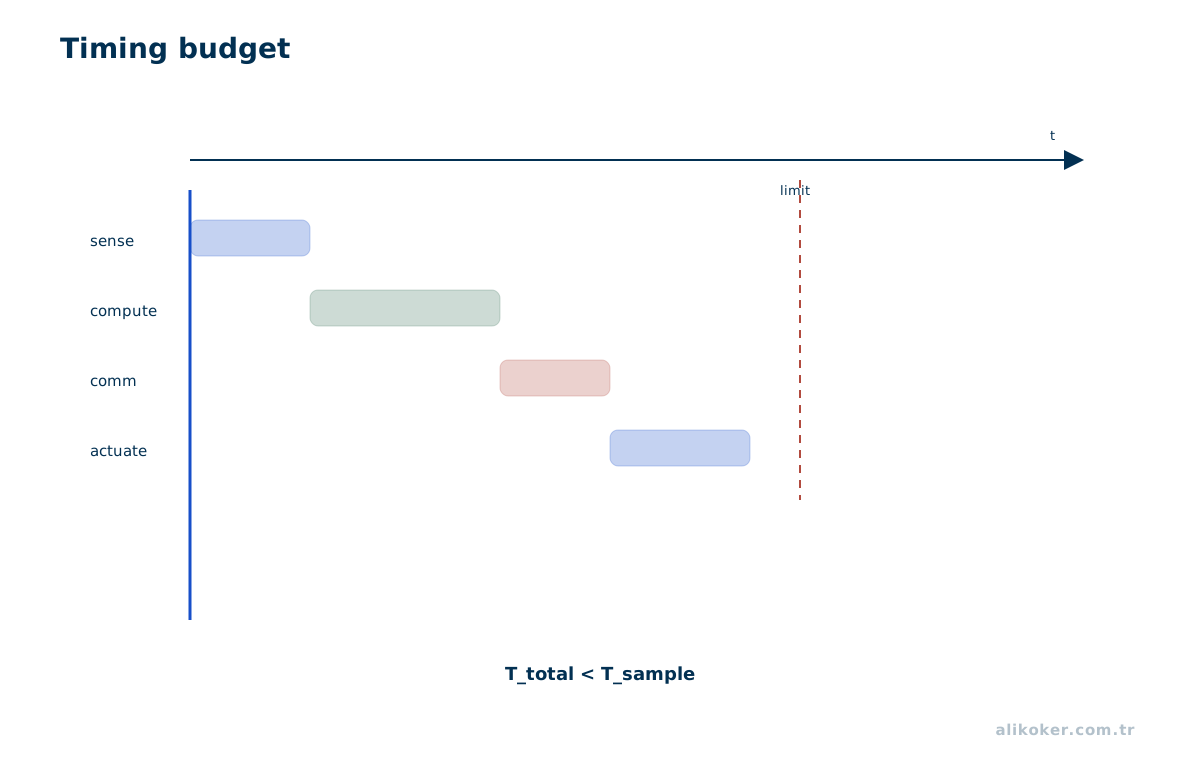
A microcontroller does more than evaluate equations; it also establishes the time axis of the physical loop. Timers, interrupts, ADC triggers, capture/compare units, PWM peripherals, and communication interfaces determine when events are observed and acted upon.
Average execution time is not sufficient for a critical loop. Sampling period, interrupt latency, worst-case execution time, jitter, deadlines, and timestamp consistency must be considered together. The processor-side mechanisms are treated in Microprocessors.
7.1. Timing Budget and Determinism
Real-time behavior is not equivalent to a fast processor. The total delay from sensing to actuation enters the closed-loop dynamics. An average execution time of 200 microseconds is insufficient for a 1 ms deadline if occasional execution takes 5 ms. Worst-case execution time, interrupt priorities, DMA behavior, and shared-state contention must therefore be included in the timing model.
A useful end-to-end budget is:
sensor conversion
+ bus transfer
+ interrupt latency
+ estimation
+ control computation
+ PWM update latency
= end-to-end control delay
Variation matters as much as the mean. Jitter can behave as a model error in high-bandwidth control and in time-aligned multi-sensor estimation.
Unit 8: Control and the Command Lifecycle
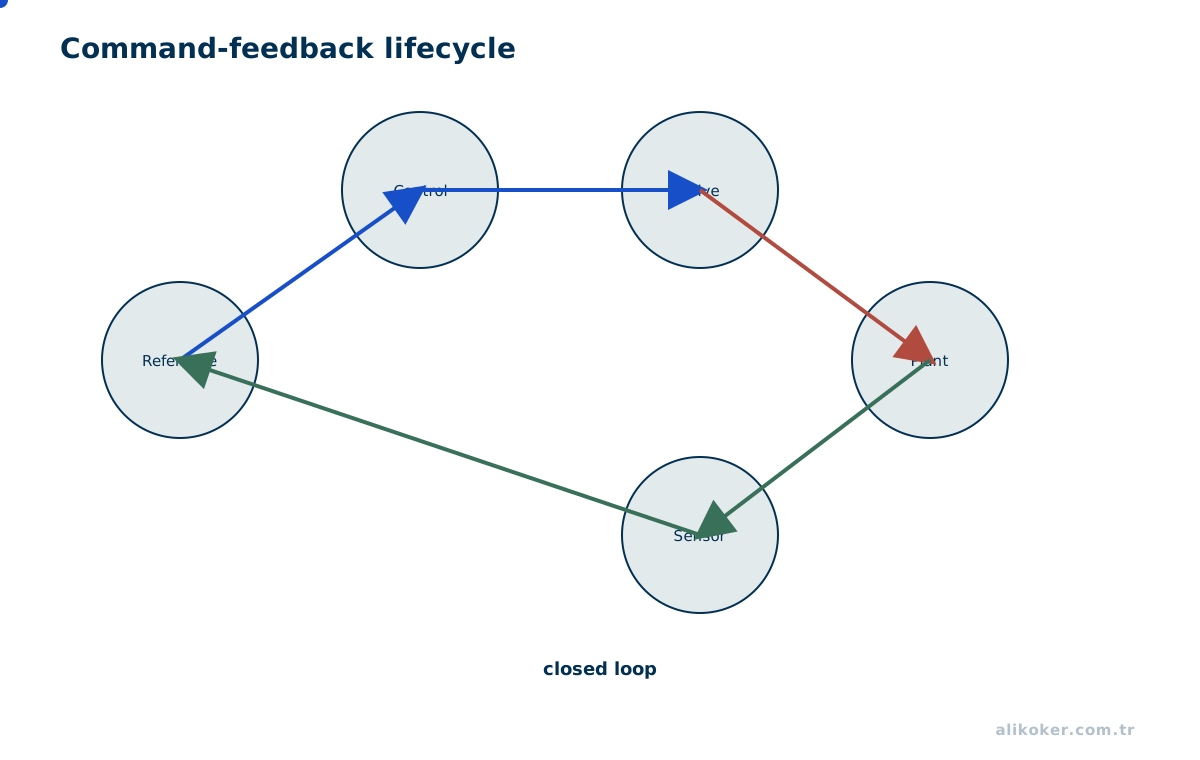
The controller produces a command from the difference between desired and observed behavior. A computed command is not automatically a physically realizable command. Actuator saturation, current limits, mechanical stops, speed limits, and source capability constrain what can be applied.
Closed-loop stability, PID design, state-space methods, and frequency-domain design belong to Automatic Control. Here the controller is positioned as one layer of the overall mechatronic architecture.
Unit 9: Power Stage
Most motors, solenoids, and valves cannot be driven directly by a processor output. Low-power control information must be translated into the voltage and current required by the load.
controller -> driver -> power switch -> loadMOSFET/IGBT drive, freewheeling paths, switching losses, DC-DC converters, and inverters are developed in Power Electronics.
Unit 10: Actuation
An actuator converts a command into motion, force, torque, pressure, or flow. Electric machines, solenoids, hydraulic actuators, and pneumatic actuators realize that conversion through different physical mechanisms.
Machine construction, torque-speed behavior, losses, thermal limits, and load matching are covered in Actuators, Electrical Machines and Drive Systems.
Unit 11: Communication and Distributed Behavior
UART, SPI, I²C, CAN, and related interfaces transport more than values; they introduce latency, priority, error-detection behavior, and timing constraints. In distributed systems, knowing when a measurement was acquired or a command was applied can be as important as knowing its numeric value.
Timeouts, sequence numbers, CRCs, and application-level plausibility checks can detect different communication faults. Protocol integrity, however, cannot prove that a physical sensor itself is correct.
11.1. Communication Is Part of Timing
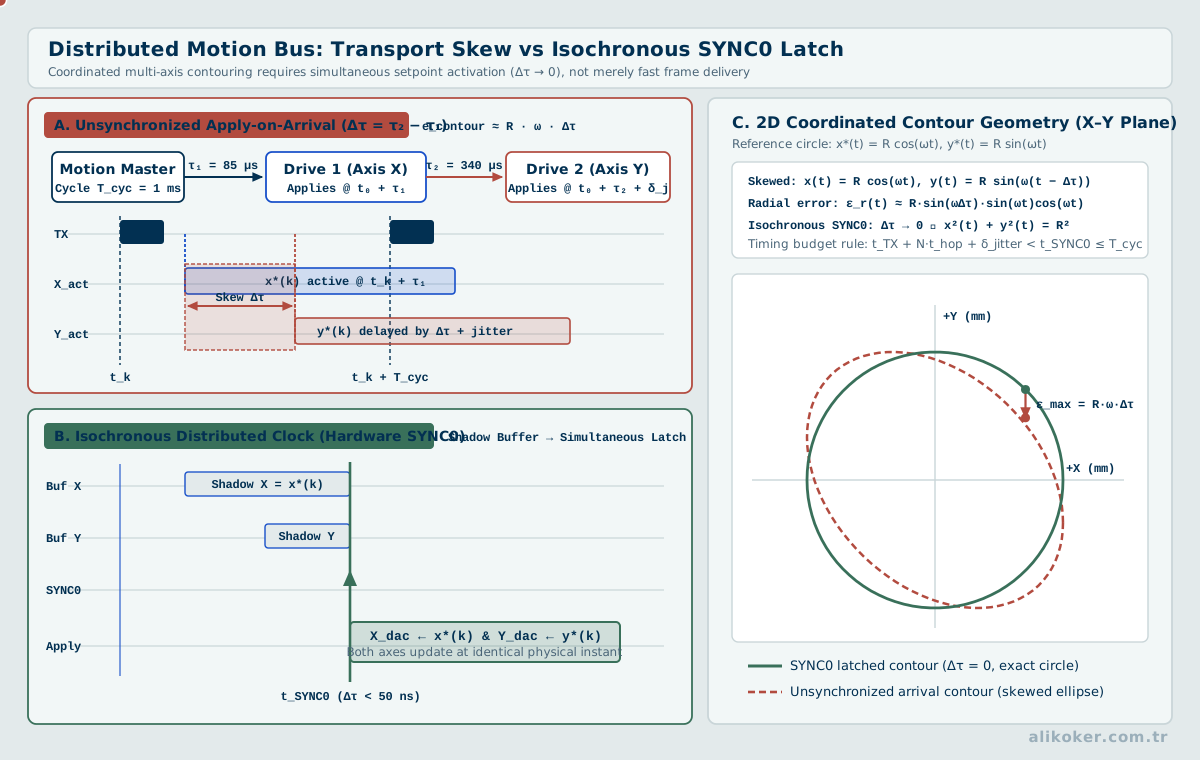
A received packet is not necessarily a current measurement. Source timestamps, sequence numbers, and timeout policy are needed to determine data age. On priority-based buses such as CAN, high-priority traffic can increase the latency of lower-priority messages; on UART links, baud rate, frame length, and software buffering determine transfer delay.
Fault detection is layered. A CRC may detect a corrupted frame but not a physically stuck sensor. A sequence number can reveal a lost packet but not an incorrect calibration coefficient. Communication integrity, temporal validity, and physical plausibility are separate checks.
Treating telemetry as if every arrival were a fresh physical observation can introduce control errors in a distributed mechatronic system. Source timestamps and monotonically increasing sequence numbers help distinguish a newly received packet from a recent measurement. If frame 42 has already been processed, a delayed frame 41 does not mean the physical state has moved backward. Once the freshness bound is exceeded, the controller should apply an explicit safe-state rule instead of holding the last value indefinitely.
Unit 12: Energy, Power, and Thermal Budgets
A mechatronic system cannot be sized by summing nominal power ratings. Motor starting current, regenerative energy, converter efficiency, cable voltage drop, battery internal resistance, and ambient temperature affect the available operating envelope.
Continuous and peak power must be separated. Energy-storing components and loads must be analyzed during transients as well as at steady state. In many systems the thermal constraint becomes binding before the nominal electrical limit.
12.1. Average Energy versus Peak Power
In a mobile or battery-powered system, average energy consumption may determine runtime while peak power determines the electrical architecture. Motor startup, solenoid pull-in, or high-power RF transmission can cause supply droop through battery and cable resistance even when the event is brief. A controller brownout while the power stage remains energized can create uncontrolled behavior.
Thermal budgeting tracks electrical losses over time. A device current rating does not imply that the current is continuously safe; package, copper area, airflow, and ambient temperature determine junction temperature. Energy analysis therefore includes source capability, conversion efficiency, transients, regeneration, and heat removal.
Unit 13: Noise, Grounding, and Electromagnetic Compatibility
Switching nodes with high di/dt and dv/dt can corrupt sensing and communication. Sharing an inductive or resistive return path between high-current switching and a low-level measurement creates ground bounce and measurement error.
Short current loops, appropriate bypassing and decoupling, controlled return paths, shielding, physical placement, and galvanic isolation where required are design decisions rather than afterthoughts.
13.1. Current Return Paths Are Part of the Design
High motor current and microvolt-level sensing may share a physical reference, but conductors have finite impedance. Rapid power-current changes create voltage on common impedance, which can appear as analog offset or communication error. Layout and return-current geometry therefore belong to the functional design.
EMC can be analyzed as source, coupling path, and victim. Reducing switching-loop area at the source, improving layout or shielding in the coupling path, and increasing filtering or common-mode rejection at the victim are complementary actions. Adding a ferrite late in development is not a universal substitute for controlling the root cause.
Unit 14: Fault Behavior and Safe State
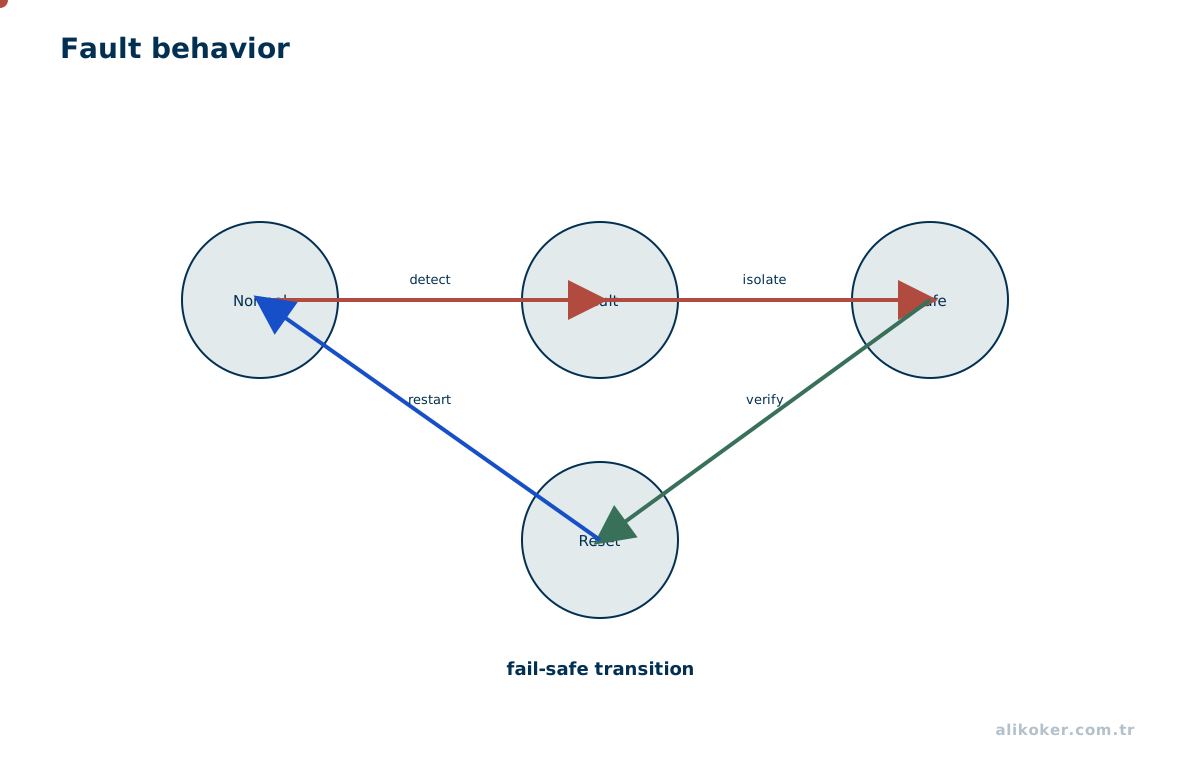
Sensor disconnection, drive failure, mechanical jamming, communication loss, software lockup, and overtemperature require predefined system responses. Watchdogs, limit switches, current limiting, thermal protection, and mechanical stops address different failure classes and should not be treated as interchangeable safeguards.
A safe state is not always equivalent to removing power. Some loads require controlled braking, a valve to move to a defined state, or stored energy to be discharged in a controlled manner.
14.1. Fault Assumptions and Independent Protection
A safety mechanism does not provide true independence when the same fault can disable both control and protection. If motor current is measured and switched off only by the same microcontroller, a processor lockup can defeat both functions. Critical limits may require hardware current limiting, thermal shutdown, or an independent enable path.
FMEA-style reasoning asks for cause, local effect, system effect, detection method, and safe response. An open sensor and a sensor that produces a plausible but incorrect value are different failures; the latter can pass range checks. Model-based plausibility and cross-checking with a different physical principle can therefore be important.
Unit 15: Simulation, Prototyping, and Verification
Model-in-the-loop, software-in-the-loop, and hardware-in-the-loop methods can expose different faults before full-scale physical testing. Simulation does not replace physical validation.
Model assumptions, time step, numerical solver, parameter source, and measurement conditions must be recorded if results are to be reproducible and useful for engineering decisions.
15.1. Purpose of Verification Levels
Model-in-the-loop evaluates the control concept against a mathematical plant; software-in-the-loop executes production-like software without the target hardware; hardware-in-the-loop connects the real controller to a controlled plant model. These levels are not interchangeable. Each is intended to reveal a different class of defects earlier and at lower cost.
Measurement points should be designed into the physical prototype. If current, voltage, position, temperature, and timing cannot be observed, diagnosis becomes guesswork. Testability is an architectural property rather than a feature added after implementation.
15.2. A Measurable Acceptance Condition for One Motion Axis
Verifying a drive axis requires explicit timing and error limits, not merely observing a completed move. Consider a 10 ms control cycle. If measured upper bounds are 0.6 ms for conversion, 0.9 ms for communication, 1.8 ms for estimation and control, 1.1 ms for the drive update, and 1.4 ms for scheduling variation, their sum is 5.8 ms. The nominal margin is 4.2 ms, but only for the assumed execution order and interference model. A newly introduced interrupt or blocking dependency can invalidate that margin. The highest duration observed in testing should not be presented as a proven worst-case bound.
Position accuracy calls for a different experiment. An encoder may measure the motor shaft while compliance and backlash separate that shaft from the load. Agreement between the commanded position and encoder count does not demonstrate that the load reached its target. Acceptance measurements should cover at least two known loads, both directions of reversal, and different initial thermal conditions, using an independent load-position reference. Commands, measurements, drive states, and reference observations must share a consistent time basis. This separates controller error from sensing location, timing, and mechanical transmission effects.
Unit 16: System Integration and Diagnosis
A position error does not imply that the control algorithm is wrong. Sensor offset, scaling error, backlash, insufficient torque, supply sag, sampling delay, or communication loss can create the same symptom.
Diagnosis should therefore follow the chain:
physical state
 -> raw sensor output
 -> conditioned signal
 -> digital measurement
 -> estimated state
 -> control command
 -> drive output
 -> actuator current / force
 -> mechanical result
Defining an observable quantity at each boundary makes root-cause analysis tractable across disciplines.
16.1. Cross-layer root-cause Analysis
The same symptom can originate in different engineering layers. Failure to reach a position target may result from controller tuning, supply droop, current limiting, mechanical binding, encoder scaling, or timestamp errors. Root-cause analysis should therefore separate measurable variables rather than disciplines.
A useful diagnostic chain records the requested command, the admissible limit, the actual drive output, and the physical response independently. “Software requested 5 A” and “the drive delivered 5 A” must not be treated as the same event. This distinction makes production diagnosis more deterministic.
Academic and Applied Context
The chronological position of these notes marks the transition from electronics and computer-engineering foundations toward mechatronic system integration. A 2014 RFID-reader, Arduino, and servo based access-control project was a small sensing-decision-actuation example. The Baykar internship in 2015 connected embedded software and communication with physical hardware, while the 2016–2019 AKINSOFT / AKINROBOTICS work provided a broader systems context involving robotic control, autonomy, telemetry, speech and vision processing, and physical behavior.
These examples provide provenance for the engineering perspective; they do not replace the general theory presented in the course.
Related Courses
- Foundations: Circuit Theory, Electronics I and II, Signals and Systems, Microprocessors
- Continuation: System Modeling and Simulation, Measurement Systems, Sensors and Sensing Systems, Actuators, Electrical Machines and Drive Systems, Power Electronics, Automatic Control, Robotics Engineering
Reading an End-to-End Mechatronic Axis
A single positioning axis is rich enough to expose the boundaries between courses. Once travel, payload, maximum speed, repeatability, and safe stop are defined, design choices become coupled: screw pitch and gear ratio on the mechanical side; motor torque-speed behavior; encoder resolution and location; DC-bus and peak current; sampling and control bandwidth.
motion requirement
 -> load and inertia
 -> motor / transmission
 -> drive and source
 -> position / speed sensing
 -> sampling and timing
 -> controller
 -> mechanical result
If a 1 mm position error appears, changing PID gains is not the first universal response. Requested position, raw encoder count, scale factor, motor current, drive saturation, and mechanical output are observed separately. The fault then becomes measurable at the layer where it is introduced.
A design must also survive boundary conditions: minimum supply, maximum payload, a hot motor, increased low-temperature friction, sensor loss, and emergency stopping. Mechatronics treats these as one system behavior rather than unrelated problems owned by separate disciplines.
References
- Bolton, W. Mechatronics: Electronic Control Systems in Mechanical and Electrical Engineering. Pearson, 2011.
- Isermann, R. Mechatronic Systems: Fundamentals. Springer, 2005.
- Billingsley, J. Mechatronics Experiments with Machine Vision. Springer Nature Switzerland, 2026. DOI: https://doi.org/10.1007/978-3-032-11218-7.
- Necsulescu, D. Advanced Mechatronics: Monitoring and Control of Spatially Distributed Systems. World Scientific, 2009. ISBN 978-981-277-181-0.