


Sensors and Sensing Systems

Sensors and sensing systems covering resistive, capacitive, inductive, Hall, piezoelectric, thermal, optical, position, inertial, force, pressure, flow, and interface principles.
A sensor converts a physical or chemical quantity into a signal that an electronic system can process. Sensor selection cannot be reduced to the question “what does it measure?”; conversion principle, operating range, sensitivity, bandwidth, environmental robustness, calibration, loading, and fault behavior belong to the same engineering decision.
This course connects measurement reliability from Measurement Systems to the physical conversion mechanism of the sensing element. Circuit-level details belong to Electronics I and II, time/frequency behavior to Signals and Systems, and closed-loop use to Automatic Control.
Unit 1: Sensor, Transducer, and Detector
A transducer is the general device that converts energy or a physical quantity from one form to another. A sensor is an input transducer that converts the measurand into a usable output. A detector often indicates the presence of a phenomenon or whether a threshold has been exceeded.
A sensor system therefore contains more than the sensing element:
stimulus
 -> sensing element
 -> transduction
 -> signal conditioning
 -> digital interface
 -> measurement
1.1. Position of the Terms in a System
Sensor, detector, and transducer overlap in practical terminology; the engineering requirement is to define the conversion between a physical input and a usable output. A thermocouple converts temperature difference to voltage, a strain gauge converts strain to resistance change, and an encoder converts angle to pulses or a digital code.
The sensor output is not yet the complete measurement result. Transfer characteristic, excitation, analog front end, digitization, calibration, and timing together produce the usable measurement. Selection should therefore be performed at measurement-chain level rather than component level.
Unit 2: Sensor Characteristics
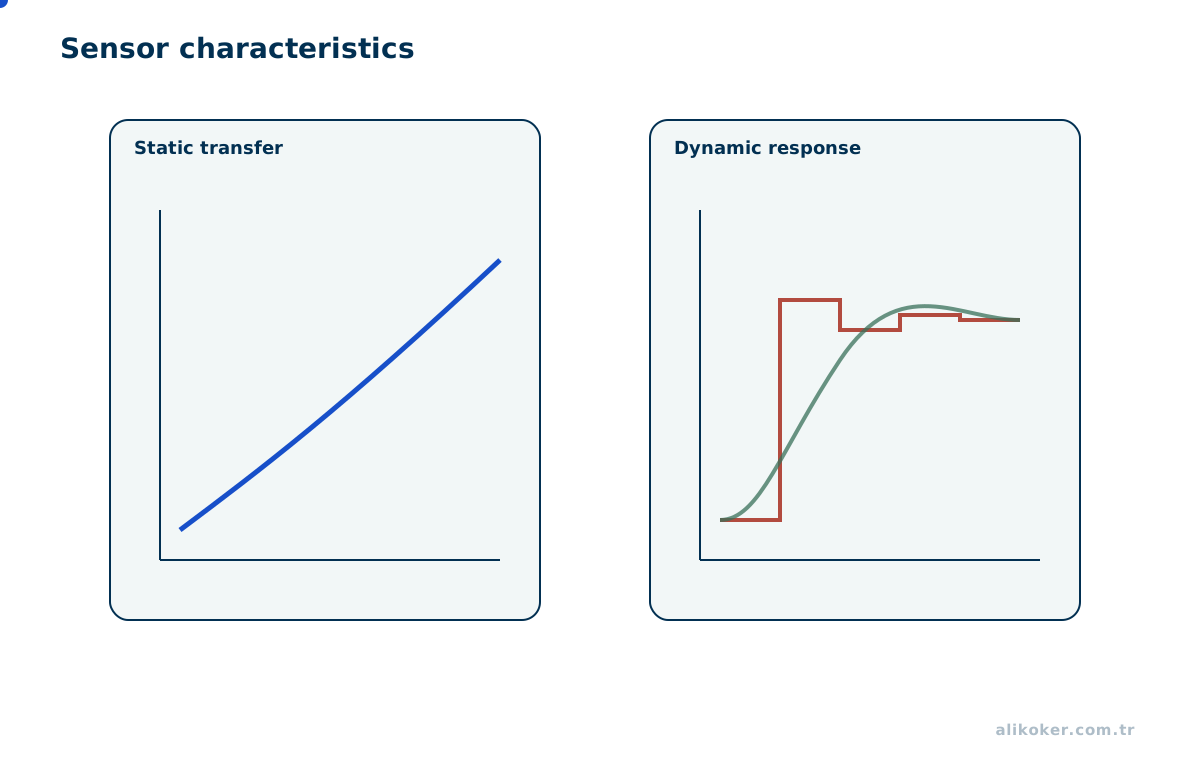
Important static characteristics include range, full-scale output, sensitivity, nonlinearity, hysteresis, repeatability, resolution, saturation, output impedance, and drift.
Dynamic characteristics include time constant, rise time, bandwidth, and resonance. Operating inside the catalog range does not guarantee that a sensor can reproduce a fast-changing phenomenon correctly.
A sensor should not be selected from a single accuracy figure. First define measurement range, bandwidth, environmental conditions, and permissible delay. Then compare the errors caused in the application by sensitivity, nonlinearity, hysteresis, drift, and noise. Test the calibration model across operating points and apply temperature compensation where justified. Select the sensor that meets the uncertainty budget under actual mounting and loading conditions, not merely the nominal data-sheet specifications.
2.1. Reading Static and Dynamic Characteristics Together
A sensor can be accurate in steady state yet too slow for a transient. Another can be fast but poor over long periods because of drift or temperature coefficient. Range, sensitivity, linearity, hysteresis, repeatability, drift, bandwidth, and noise must therefore be considered together.
A first-order approximation may be written as:
τ dy/dt + y = K xA larger τ produces slower tracking. Dynamic error is invisible in a static calibration and should be characterized by step response or frequency response.
2.2. Correlated Uncertainty in Combined Measurements
Uncertainties are not necessarily independent when several sensor readings are combined. For observations \(x_1,\ldots,x_n\) and an output \(y=f(x_1,\ldots,x_n)\), first-order uncertainty propagation can use the covariance matrix:
\[ \sigma_y^2\approx J\Sigma J^T,\qquad J=\begin{bmatrix}\partial f/\partial x_1&\cdots&\partial f/\partial x_n\end{bmatrix}. \]
For a difference \(y=x_1-x_2\), this becomes \(\sigma_y^2=\sigma_1^2+\sigma_2^2-2\operatorname{Cov}(x_1,x_2)\). Sensors drifting together because of a shared supply or temperature can make the covariance term important. Its sign also matters: a shared shift may cancel in a difference while remaining hidden in absolute readings.
Calibration reports should distinguish systematic offset, repeatability, and environmental drift instead of relying on one manufacturer's accuracy percentage. First-order propagation may be inadequate for strongly nonlinear mappings; physically constrained sampling or higher-order analysis may be needed. Uncertainty estimates inform not only sensor selection but also alarm thresholds and the validation of control decisions.
Unit 3: Self-Generating and Modulating Sensors
Some sensors generate an electrical output directly from the measurand. Thermocouples, photovoltaic devices, and piezoelectric elements are examples.
Resistive, capacitive, and inductive sensors generally require external excitation because the measurand modulates a circuit parameter. This distinction influences power budget, noise behavior, and interface design.
3.1. Difference in Energy Source
Thermocouples, piezoelectric elements, and photovoltaic cells can generate electrical output from the measurand itself. RTDs, strain gauges, and LDRs require excitation because the measurand modulates resistance, capacitance, or another electrical parameter.
Excitation is not merely a supply issue. Excitation noise, stability, and self-heating enter the measurement. Increasing RTD or strain-gauge current raises signal level but can heat the sensing element and disturb the quantity being measured.
Unit 4: Resistive Sensing
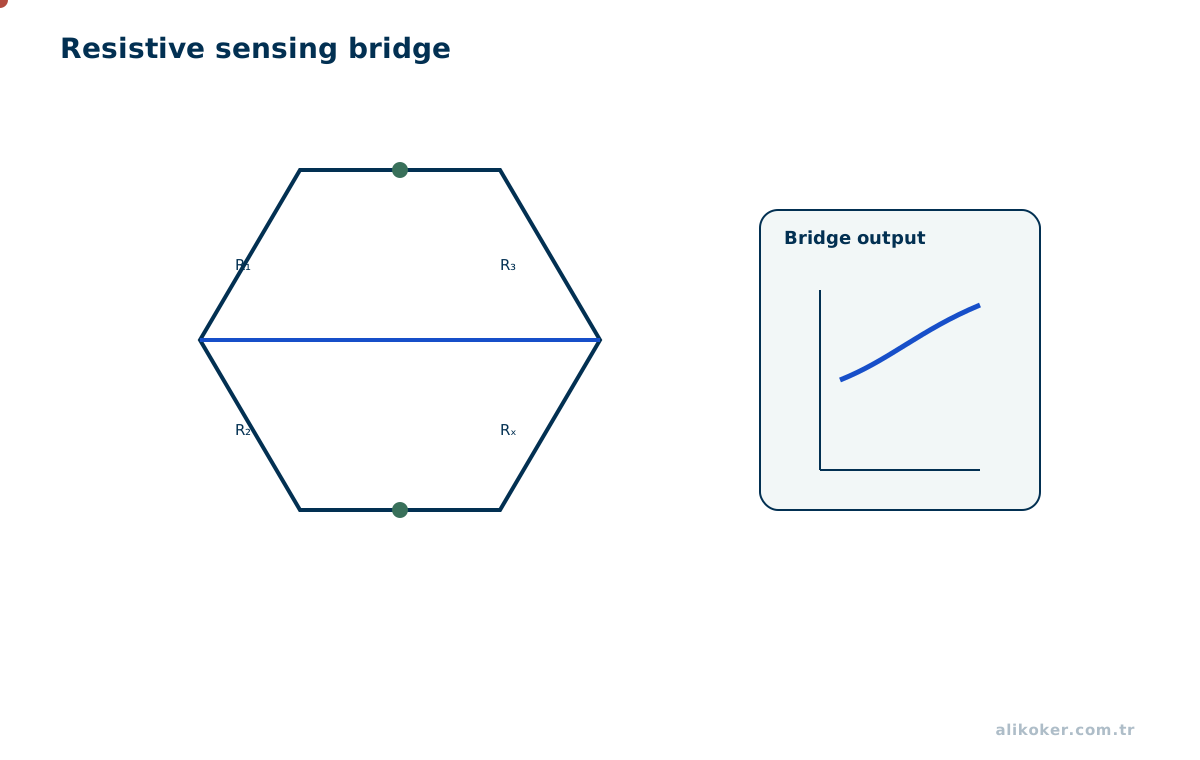
Because:
R=ρ(l)/(A)changes in material resistivity, length, or cross-sectional area can become measurable resistance changes.
Examples include potentiometric position sensors, RTDs, thermistors, strain gauges, and LDRs. Small changes are commonly converted into a differential signal with a Wheatstone bridge. Bridge analysis and uncertainty belong to Measurement Systems.
In resistive sensing, first establish the relationship between the physical quantity and resistance. Choose direct measurement, a divider, or a bridge according to the expected variation. If excitation current causes self-heating, account for its effect on the result. Checking input impedance, lead resistance, and readout resolution makes the contribution of circuit choice to total measurement uncertainty explicit.
4.1. Converting Resistance Change into a Signal
The practical problem is often not measuring resistance but resolving a very small change. For a strain gauge:
ΔR/R = GF * εwhere GF is gauge factor and ε is strain. Wheatstone bridges and differential amplification convert small changes into measurable voltage.
Lead resistance, contact resistance, and temperature coefficient matter for low-resistance RTDs and remote sensors. Two-, three-, and four-wire connections manage these errors differently. Sensor physics belongs here; detailed uncertainty accounting belongs to Measurement Systems.
Unit 5: Capacitive Sensing
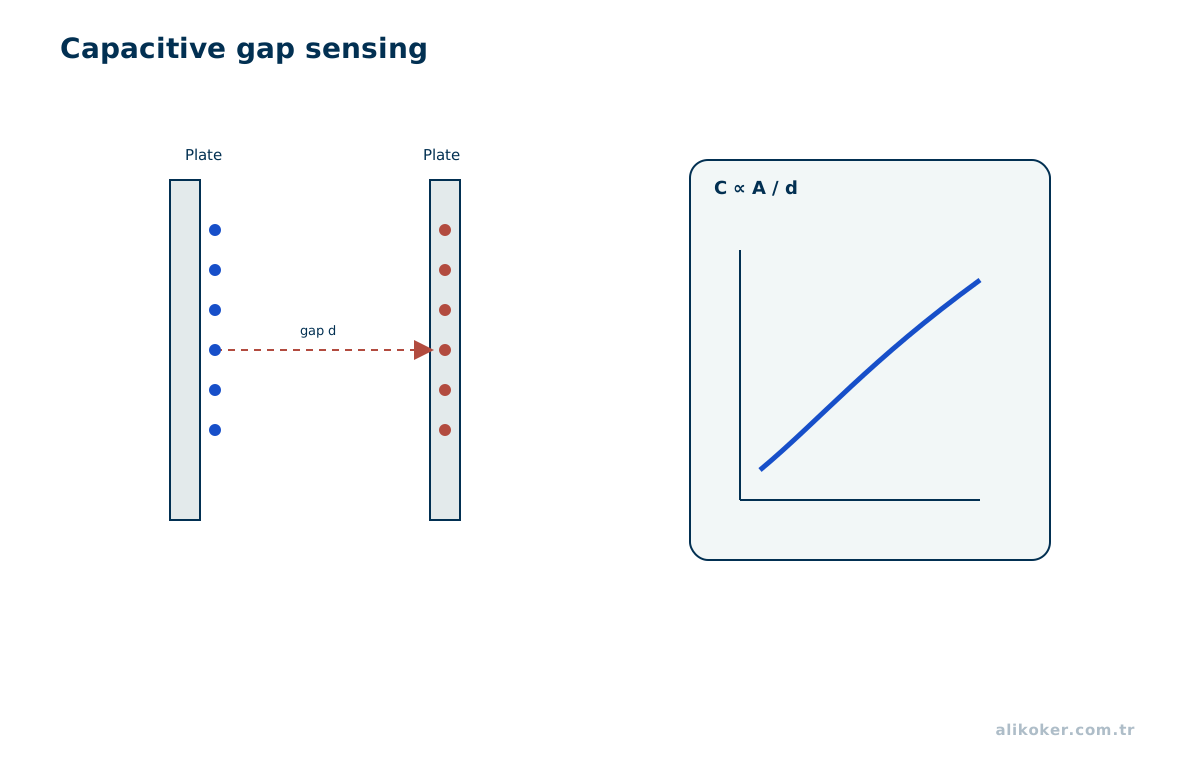
For a simple parallel-plate model:
C=ε(A)/(d)so a change in plate area, spacing, or dielectric constant changes capacitance.
Capacitive sensing is used for displacement, proximity, level, pressure, and humidity. Cable capacitance, nearby conductive objects, humidity, and input impedance can disturb the result. Guarding and shielding may reduce parasitic-capacitance effects.
5.1. Geometry, Dielectric, and Parasitics
For a simple parallel-plate model:
C = ε A / dCapacitive displacement, level, pressure, and proximity sensing use changes in area, gap, or dielectric.
Cables, PCB traces, and the environment add parasitic capacitance. Guard electrodes, shielding, differential structures, and mechanical geometry can reduce unwanted coupling. Very high-impedance nodes are sensitive to humidity and contamination, making packaging part of the electrical design.
Unit 6: Inductive and Electromagnetic Sensing
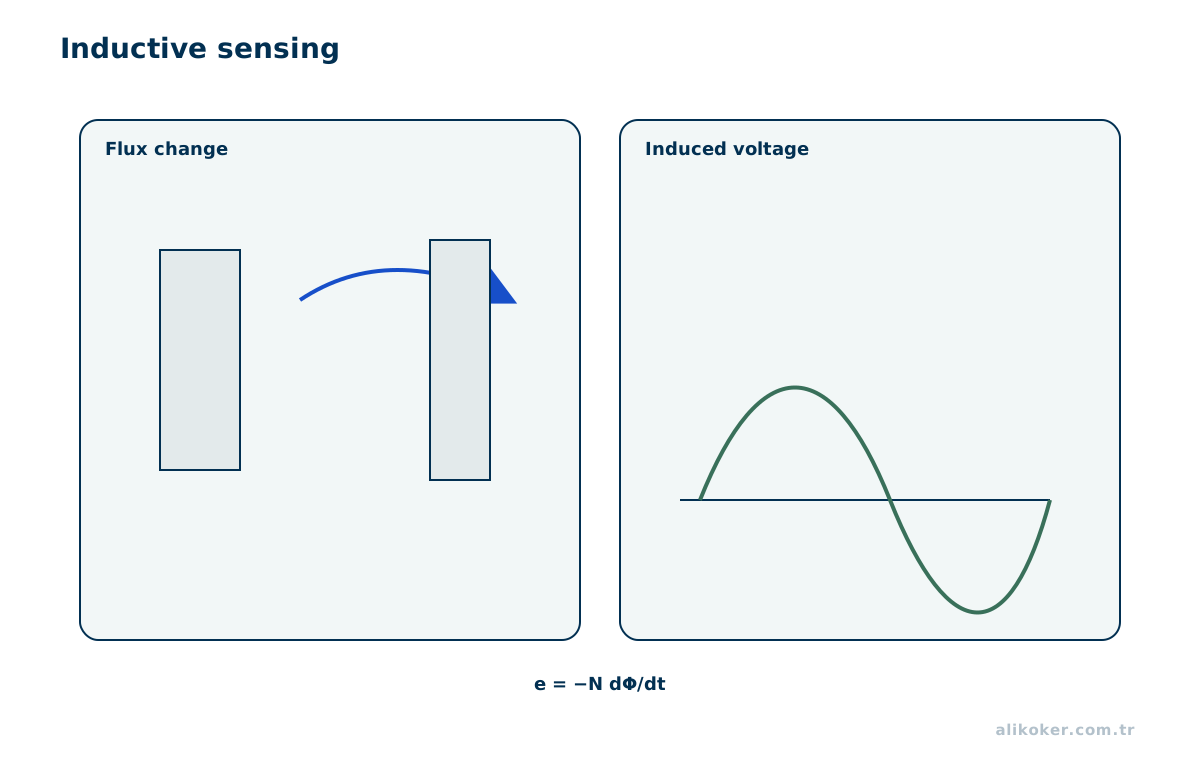
Faraday's law:
e=-N(dΦ)/(dt)shows how changing magnetic flux induces voltage. Variable-reluctance sensors, LVDTs, and electromagnetic velocity sensors use related mechanisms.
Inductive proximity sensors can detect conductive targets through changes caused by eddy currents. Range depends on target material, coil geometry, and operating frequency.
6.1. From Faraday Induction to Motion Sensing
A changing magnetic flux induces voltage:
e = -N dΦ/dtVariable-reluctance speed sensors and pickup coils use this principle. Output amplitude can depend strongly on target speed, making low-speed detection more difficult.
LVDTs use changing transformer coupling to convert displacement into a differential AC signal. Excitation frequency, demodulation, phase, and mechanical centering all contribute to system accuracy.
Unit 7: Hall and Magnetic Sensors
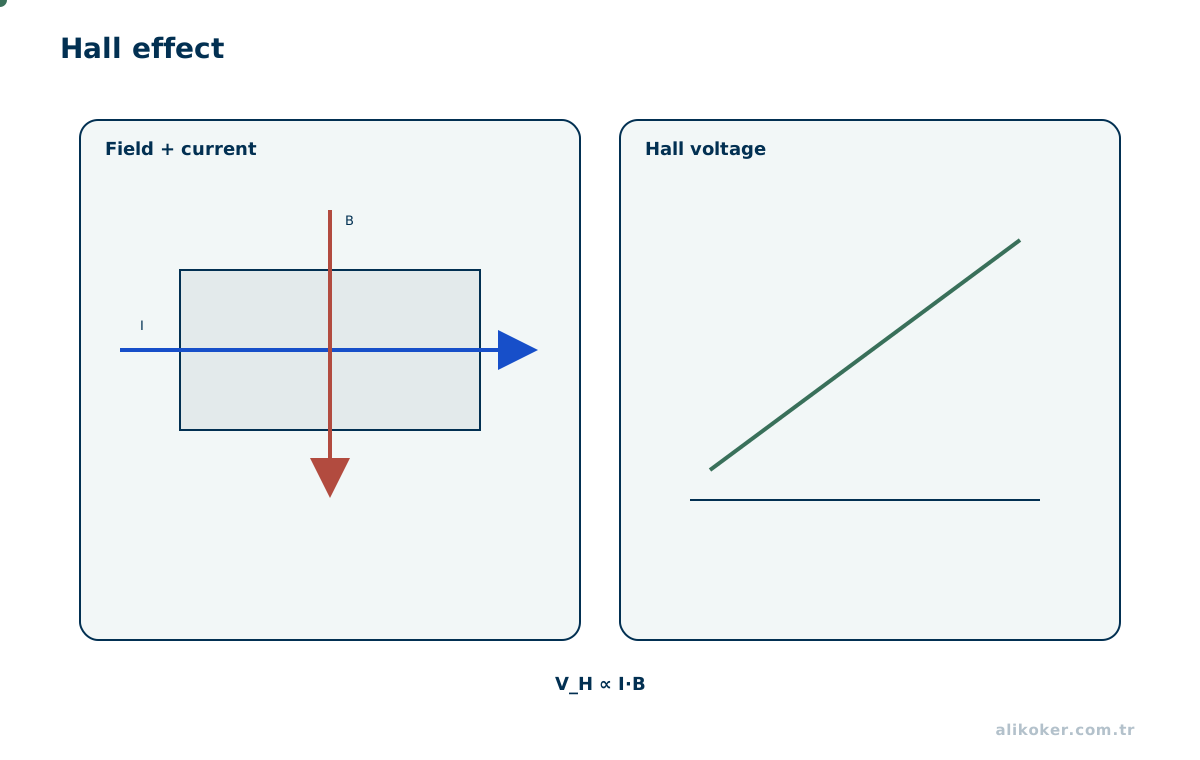
The Hall effect produces a transverse voltage when a current-carrying material is exposed to a magnetic field. Hall sensors are used for magnetic field, current, position, speed, and BLDC rotor-position sensing.
Field range, offset, temperature coefficient, bandwidth, and sensitivity to external magnetic fields are important selection parameters.
7.1. Direct Sensing of Magnetic Field
The Hall effect creates a transverse voltage when charge carriers move in a magnetic field. Hall devices are used for current, rotor position, proximity, and magnetic-field measurement. Open-loop Hall current sensors measure the field from a conductor; closed-loop magnetic sensors can provide higher accuracy.
Offset, temperature drift, external fields, and hysteresis of nearby ferromagnetic material affect magnetic measurements. Magnet-to-sensor geometry and mechanical tolerances can dominate position accuracy even when the sensor's field range is adequate.
Unit 8: Piezoelectric and Piezoresistive Sensing
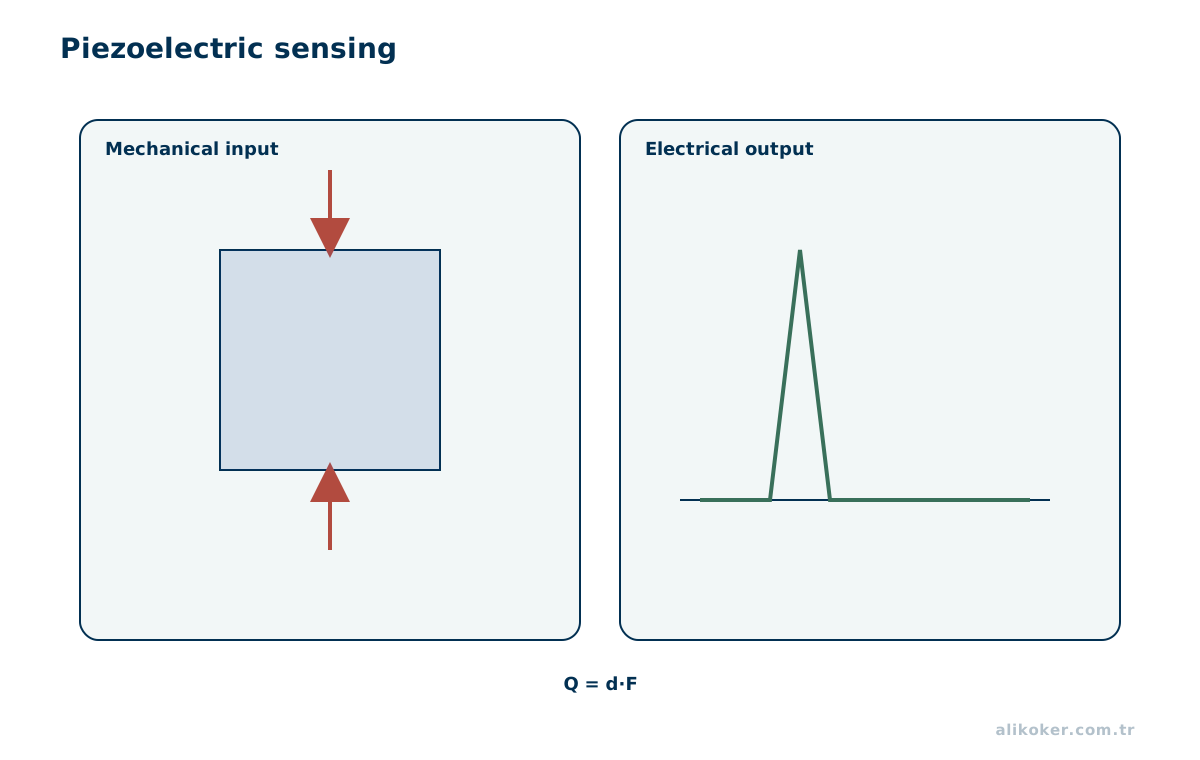
Piezoelectric materials generate charge under mechanical stress and are well suited to vibration, impact, dynamic force, and pressure measurement. Charge leakage and interface impedance limit static or very-low-frequency measurement.
Piezoresistive sensing converts mechanical strain to resistance change. For a strain gauge:
GF=(Δ R/R)/(ε)defines the gauge factor.
8.1. Dynamic versus Static Measurement
Piezoelectric material produces charge under force or strain. With a charge amplifier or very-high-impedance front end it is well suited to vibration, impact, and dynamic pressure. Charge leakage makes classical piezoelectric sensing less suitable for very long static-force measurements.
Piezoresistive structures change resistance under mechanical strain. MEMS pressure sensors can place piezoresistors on a diaphragm in a bridge. Temperature coefficient and package stress can shift zero, so calibration may require multiple points.
Unit 9: Temperature Sensors
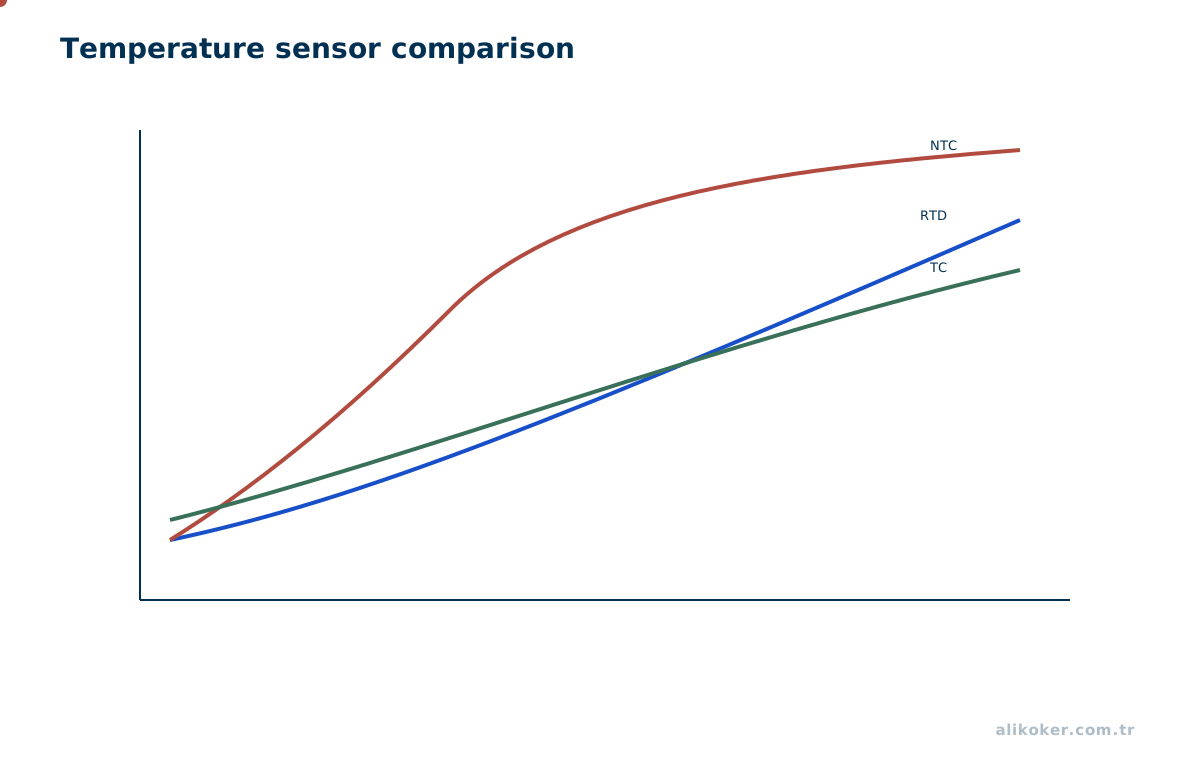
Common temperature-sensing mechanisms include RTDs, thermistors, thermocouples, semiconductor temperature sensors, and non-contact infrared sensing.
Thermocouples require cold-junction compensation. Lead resistance affects RTDs, thermistor nonlinearity and self-heating require attention, and IR measurement depends on emissivity and field of view.
9.1. Different Behavior of RTD, Thermistor, and Thermocouple
RTDs offer good stability and repeatability but require attention to self-heating and lead resistance. Thermistors provide high sensitivity but are strongly nonlinear. Simple models can be adequate over narrow ranges, while wider ranges may use Steinhart-Hart-type relationships.
A thermocouple produces thermoelectric voltage related to temperature difference, not absolute junction temperature. Cold-junction compensation is therefore required. Cable type, connector metals, and electromagnetic interference matter because the signal can be only microvolts.
Unit 10: Optical and Photoelectric Sensing
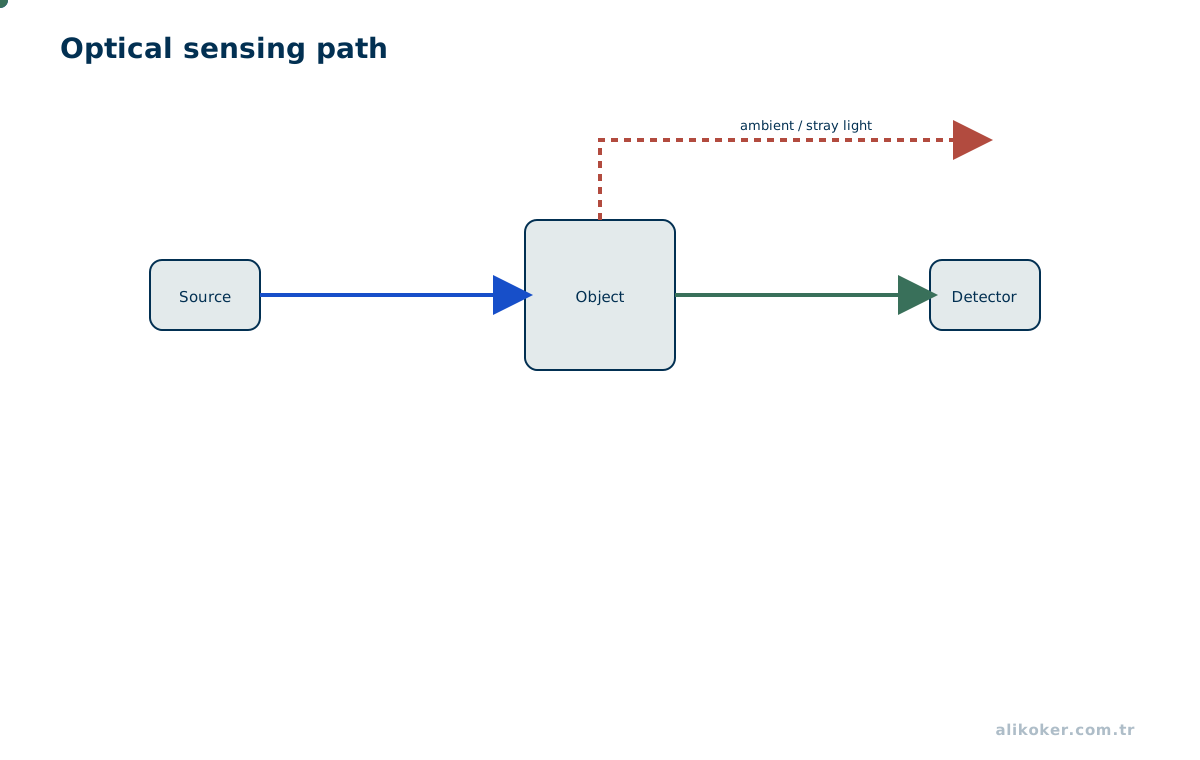
Optical sensors convert photon interaction into electrical behavior. LDRs, photodiodes, phototransistors, and photovoltaic cells differ in speed, sensitivity, and linearity.
A reverse-biased photodiode can be used for fast sensing, often with a transimpedance amplifier. Source spectrum, detector spectral response, ambient light, and geometric alignment all affect the optical measurement.
An optocoupler is primarily an optoelectronic signal-transfer and galvanic-isolation device rather than a general-purpose measurement sensor.
10.1. Source, Optical Path, and Detector Form One System
Photodiodes can operate in photovoltaic or reverse-biased photoconductive modes. Reverse bias can improve speed and linearity but changes dark current and noise. Photocurrent is commonly converted with a transimpedance amplifier.
Accuracy also depends on source aging, contamination, ambient light, target reflectivity, and alignment. Modulating the source and using synchronous detection can separate desired optical return from steady ambient illumination.
10.2. From Pixel Displacement to Physical Distance
Under the pinhole-camera approximation, a small horizontal displacement on a plane approximately normal to the optical axis obeys ΔX ≈ Z Δu / fx. Here Z is depth in metres, Δu is displacement in pixels, and fx is focal length expressed in pixel units. For Z = 2 m, fx = 800 pixels, and Δu = 2 pixels, the implied lateral displacement is approximately 5 mm. The calculation is meaningful only with known depth, valid calibration, and appropriately small motions.
Pixel coordinates are not world coordinates. Lens distortion, perspective, camera motion, rolling shutter, and changing object depth can give the same pixel difference different physical meanings. Matching frames by delivery timestamps alone is also risky because exposure and frame arrival occur at different instants. A useful measurement record therefore carries intrinsic calibration, the relevant coordinate transform, exposure timing, and an uncertainty bound. Recognizing an object in an image is not equivalent to measuring its position within a required physical tolerance.
Unit 11: Position and Displacement
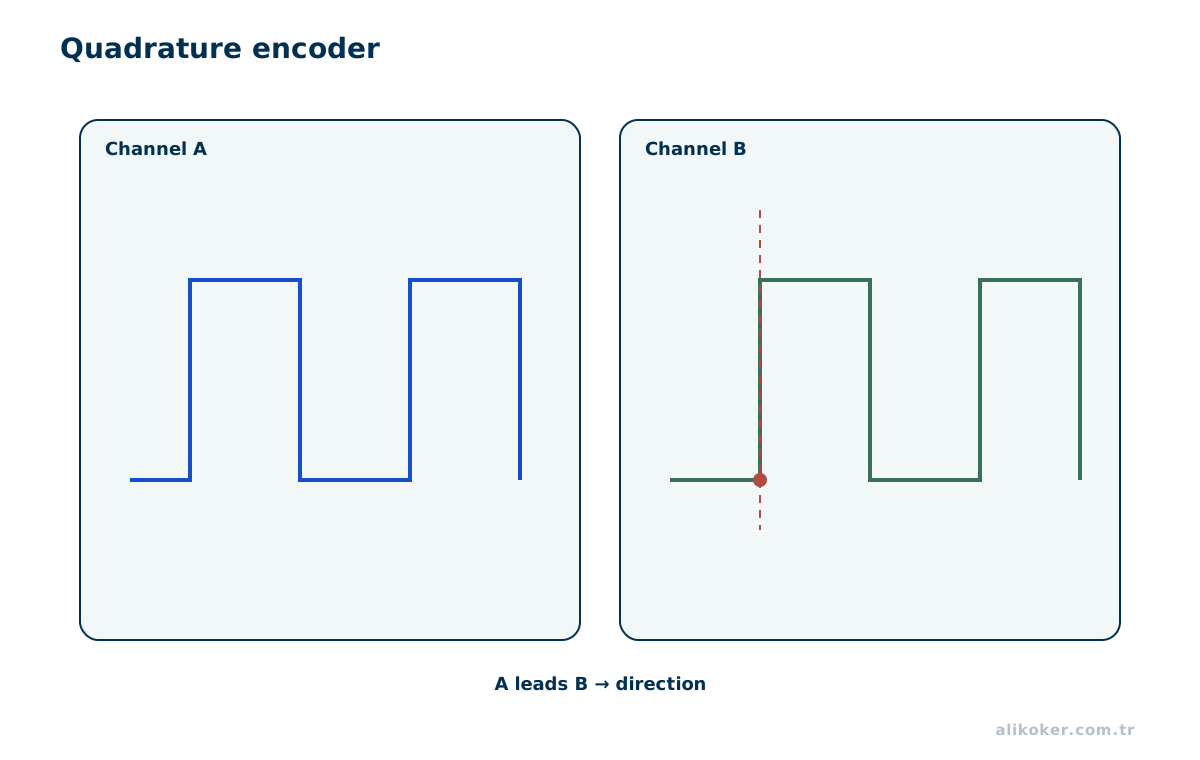
Position and displacement may be measured with potentiometers, capacitive sensors, LVDTs, optical or magnetic encoders, resolvers, and ultrasonic or optical ranging.
Incremental encoders do not inherently retain absolute position after power loss and may require homing. Resolvers produce analog sine/cosine signals and can provide robust position feedback in harsh environments.
11.1. Absolute and Incremental Measurement
A potentiometer can provide direct absolute position but has contact wear. An incremental encoder reports motion through pulse count and phase; after loss of reference it may require homing. An absolute encoder directly reports a coded position.
Resolvers produce sin/cos signals and are useful in harsh environments. Eccentricity, shaft runout, and coupling errors can produce periodic position error independently of nominal sensor resolution.
Converting encoder counts to speed and choosing the time window. An incremental encoder emits 1024 base pulses per revolution. If its A/B channels are decoded at four counts per cycle, one mechanical revolution corresponds to 4096 counts. Observing 8192 counts in a 0.5 s window means 8192/4096 = 2 revolutions, or 2/0.5 = 4 rev/s, equivalent to 240 rpm. This conversion assumes that counter rollover, direction, and the meaning of fourfold decoding are handled correctly. Short windows reduce reporting latency but increase the relative impact of one-count quantization; at low speed, measuring the time between edges may be more informative. Validation should include a known-speed reference, reverse rotation, and near-zero-speed behavior.
Unit 12: Velocity, Acceleration, and Inertial Measurement
Velocity is the time derivative of position and acceleration is the derivative of velocity. Numerical differentiation of noisy position data amplifies high-frequency noise, so direct velocity or acceleration sensing is often preferable.
MEMS accelerometers measure proof-mass displacement by capacitive or related mechanisms; gyroscopes measure angular rate. An IMU combines accelerometers and gyroscopes and may include a magnetometer. Bias and drift accumulate during dead-reckoning or orientation integration.
12.1. Differentiation Is Not Equivalent to Direct Sensing
Velocity is the derivative of position and acceleration the derivative of velocity, but numerical differentiation amplifies high-frequency noise. Direct physical velocity or acceleration sensors can therefore provide better results.
MEMS accelerometers sense proof-mass motion, often capacitively or piezoresistively. Gyroscopes estimate angular rate using Coriolis effects. Bias, scale factor, noise density, and temperature drift create growing error when integrated. IMU engineering is therefore also a coordinate-frame, timing, and calibration problem.
Unit 13: Force, Strain, and Torque
Force transducers may use load cells, strain gauges, piezoelectric elements, or other elastic mechanisms. A strain gauge converts small deformation of an elastic element into resistance change.
Torque can be measured through shaft shear strain, magnetoelastic effects, or angular twist. Mounting, parasitic loads, and temperature compensation matter as much as nominal sensor sensitivity.
13.1. Mechanical Load Path Matters
A load cell often uses a strain-gauge bridge on an elastic body. Side load, eccentric load, or poor mounting can degrade measurement even below rated capacity. Creep and hysteresis matter during sustained loading.
Torque sensors can measure shaft strain with strain gauges, magnetoelastic effects, or optical methods. Energy and data from a rotating sensor may use slip rings, telemetry, or contactless coupling. Mechanical safety margin and metrological operating range are not the same quantity.
Unit 14: Pressure Sensors
Pressure:
p=(F)/(A)is force per unit area. Absolute, gauge, and differential pressure use different reference definitions.
Capacitive, piezoresistive, strain-gauge, and piezoelectric structures can convert pressure to an electrical signal. Diaphragm material, media compatibility, overpressure capability, and temperature compensation are key design parameters.
14.1. Pressure Reference Matters
Absolute, gauge, and differential pressure use different references. Selecting the wrong reference can yield a correct sensor reading of the wrong system variable. Diaphragm sensors convert pressure to mechanical deflection and then to capacitive or piezoresistive electrical change.
Fluid compatibility, temperature, pulsation, and overpressure are selection criteria. Long impulse lines or narrow capillaries can slow the installed response, so catalog sensor bandwidth is not necessarily system bandwidth.
Unit 15: Flow and Level
Flow can be measured using differential pressure, turbine, electromagnetic, ultrasonic, thermal, or Coriolis principles. No single method is appropriate for every fluid and installation.
Level can be measured with floats, hydrostatic pressure, capacitance, ultrasound, radar, or optical methods. Foam, vapor, surface motion, dielectric properties, and tank geometry can disturb non-contact measurements.
15.1. Match the Sensing Principle to Process Conditions
Differential-pressure flow measurement introduces pressure drop; electromagnetic meters require conductive fluids; turbine meters contain moving parts and depend on flow profile; ultrasonic methods can avoid contact but are affected by bubbles and acoustic path quality.
Hydrostatic level depends on density, capacitive level depends on dielectric properties, and ultrasonic or radar level depends on surface reflection. Foam, vapor, agitation, geometry, and dead zones must be considered.
Unit 16: Acoustic and Ultrasonic Sensing
A microphone converts acoustic pressure into an electrical signal. Dynamic, condenser, and MEMS microphones use different conversion mechanisms and interface requirements.
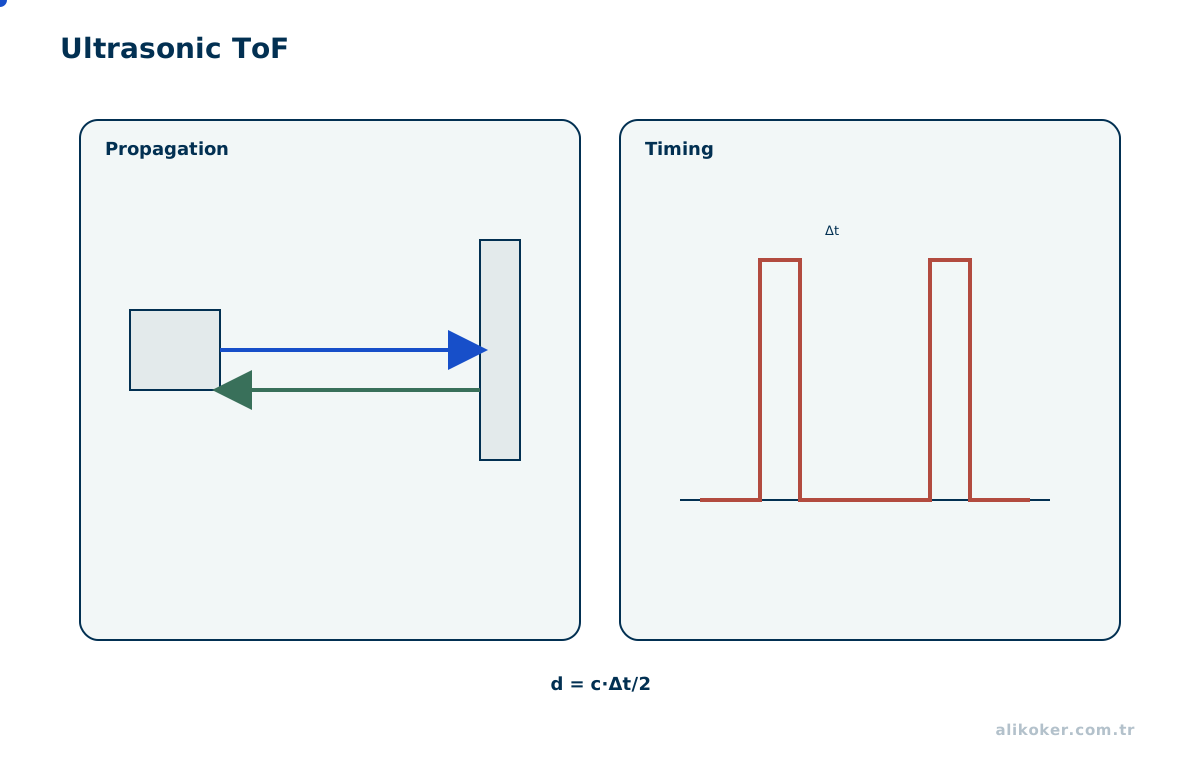
Ultrasonic time-of-flight ranging can be approximated by:
d=(ct)/(2)where c is the speed of sound and depends strongly on environmental conditions such as temperature. Target angle, absorption, and multipath reflections also influence the result.
16.1. Limits of the Acoustic Path
Microphone selection includes sensitivity, self-noise, frequency response, maximum SPL, and directivity. MEMS microphones may provide analog or digital output; digital output reduces analog-front-end requirements but introduces clock and interface constraints.
Ultrasonic ranging often starts from d=c t/2, assuming known sound velocity. Temperature, gas composition, and airflow change c. Soft, angled, or small targets can weaken the echo. Ring-down and dead zone determine minimum range.
Unit 17: Humidity and Chemical Sensors
Humidity sensors may use capacitive or resistive material changes. Chemical sensors may rely on electrochemical, semiconductor, optical, or catalytic mechanisms.
Selectivity, cross-sensitivity, aging, poisoning, temperature/humidity compensation, and calibration are central to reliable chemical measurement.
17.1. Selectivity and Aging
Chemical sensors can respond to compounds other than the target. Cross-sensitivity, poisoning, and humidity dependence are important in gas sensing. Long-term accuracy should not be assumed without reference exposure or calibration.
Capacitive humidity sensors use water absorption in a dielectric polymer to change capacitance. Hysteresis, temperature, and prolonged high humidity can alter behavior. Chemical data is often interpreted together with temperature and humidity.
Unit 18: Motion and Proximity Detection
PIR devices detect changes in infrared radiation within their field of view; microwave motion sensors can use Doppler shift; capacitive and inductive sensors respond to nearby targets through field or impedance changes.
False-trigger sources such as ambient temperature, vibration, electromagnetic interference, animal motion, and sunlight must be considered alongside the nominal detection principle.
18.1. Sources of False Triggering
A PIR detector does not directly detect “a person”; it detects changes in infrared distribution across its field of view. Sunlight, heaters, airflow, or moving warm objects can create false triggers. Fresnel optics shape detection zones.
Inductive proximity sensing is primarily sensitive to metal, while capacitive sensing can respond to conductive and dielectric targets. Distance depends on target material, size, mounting, and nearby structures, so catalog range should be verified in the final geometry.
Unit 19: Sensor Interface Electronics
Raw sensor outputs are often unsuitable for direct ADC connection. A typical path is:
sensor
 -> excitation
 -> bridge / current-voltage conversion
 -> amplification
 -> analog filter
 -> protection / isolation
 -> ADC
Instrumentation amplifiers are useful for low-level differential signals with strong common-mode components. Circuit implementation belongs to Electronics I and II, while measurement consequences belong to Measurement Systems.
19.1. Treat the Front End as Part of the Sensor
Instrumentation amplifiers are useful for small differential signals in the presence of common mode, but system CMRR also depends on resistor matching, layout symmetry, and wiring.
Photodiodes favor transimpedance stages, bridges favor differential amplification, and high-impedance piezoelectric sources may require charge amplifiers. Input protection must be checked for leakage and capacitance because protective components can disturb the measurand path.
Unit 20: Sensor Selection
Selection should consider operating and overload range, sensitivity, resolution, bandwidth, accuracy, repeatability, environmental limits, power, output type and impedance, packaging, calibration requirements, fault behavior, and lifecycle.
A sensor that is excellent in isolation can still be inappropriate if its bandwidth, interface, mounting, or failure mode conflicts with the system.
20.1. Selection Matrix
A practical selection matrix can include range, overload, resolution, accuracy, bandwidth, latency, temperature, environmental rating, vibration, supply, interface, calibration, cost, and lifecycle availability.
Failure mode is also a design variable. A broken sensor that moves to an obvious fault level can be easier to diagnose than one that remains plausible but wrong. Fault detectability can be as important as nominal accuracy in critical systems.
Sensor selection cannot be reduced to sensitivity and price; measurements must also share a time contract before they can be fused. If an IMU timestamp is assigned after transmission but a camera timestamp denotes the start of exposure, naïve alignment creates a systematic phase error. Measurement time, arrival time, delay distribution, and clock drift should be specified before resampling onto a common timeline. Axis alignment, scale, and temperature-dependent bias remain separate calibration problems even after temporal alignment.
Unit 21: Reliability and Fault Diagnosis
Open circuit, short circuit, stuck-at output, drift, saturation, and intermittent connection produce different symptoms. Simple min/max checks may be insufficient; rate-of-change limits, physical models, and redundant measurements can improve diagnosis.
Two sensors that share the same supply, bus, or sensing principle may share common-cause failures and therefore do not necessarily provide independent redundancy.
21.1. Common-cause Failures
Two identical sensors located together do not automatically provide independent redundancy. The same regulator, connector, bus, or environmental disturbance can defeat both. Common-cause paths should be considered explicitly.
Range, rate-of-change, and stuck-at checks are first-line diagnostics. Model-based residuals, cross-checking among sensors, or command-response consistency can detect subtler failures. False-positive and missed-detection behavior of the diagnostic algorithm also belongs to the reliability analysis.
21.2. Independent Evidence When Interpreting Residuals
Let ŷ[k] be a model-predicted observation and y[k] the measured signal. The residual r[k] = y[k] - ŷ[k] indicates disagreement, but a large residual alone does not prove sensor failure. Changing load, imperfect friction modeling, or timestamp misalignment can produce similar effects. A transient during acceleration may represent a dynamics-model mismatch, whereas persistent disagreement at steady operating conditions may motivate a calibration check.
Fault isolation benefits from independent observations. A motor-encoder estimate and a measurement of the mechanical output using a different physical principle may fail differently, provided they do not share an overlooked supply or mounting fault. Thresholds should be chosen from residual behavior under healthy operating conditions together with the cost of false alarms. Missing data must not be encoded as a measured zero: an invalid measurement and a verified zero are different states. Diagnostic confidence should be linked to explicit conditions for degraded operation or a safe controller state.
Application Connection
An sEMG acquisition chain can be used as a general signal-acquisition example rather than as medical guidance:
physical/biological signal
 -> electrode / sensor
 -> differential analog front end
 -> filtering
 -> ADC
 -> digital feature
 -> state / intent estimation
 -> controller
 -> drive
 -> actuator
The chain illustrates why sensing, measurement, signal processing, control, and actuation are separate but connected courses.
21.3. Common-Cause Disturbance in Multiple Sensors
Simultaneous deviations across sensors may reflect a real physical event, shared power failure or communications fault. Highly correlated channels do not provide independent confirmation. Validation requires modelling failure paths, timestamp alignment and physical connections. A single-channel outlier threshold cannot reliably isolate common-cause faults. Multivariate approaches are developed in Anomaly Detection.
Related Courses
- Measurement Systems: error, uncertainty, calibration, and data acquisition
- Electronics I and II: analog interfaces and conversion circuits
- Signals and Systems: bandwidth, sampling, and filtering
- Automatic Control: sensing inside the feedback loop
- Robotics Engineering: perception, estimation, and robotic integration
Designing a Complete Sensing System
A sensing system is not complete when the transducer is chosen. A strain-gauge load cell also requires the mechanical load path, bridge excitation, wiring, differential amplification, analog filtering, ADC reference, calibration, and software scaling to be designed as one measurement chain.
force
 -> elastic element
 -> strain-gauge bridge
 -> differential mV/V output
 -> instrumentation amplifier
 -> low-pass / anti-alias
 -> ADC
 -> calibration model
 -> result in N + quality state
Side load or preload can create error even when electronics are correct. Front-end saturation cannot be repaired by a higher-resolution ADC. One-point calibration may not remove temperature drift or nonlinearity. Sensing systems are therefore validated across physics, mechanics, electronics, and software.
The same reasoning applies to optical, magnetic, thermal, and inertial sensing. The design question is not merely “which sensor should we buy?” but “which physical principle and measurement chain can provide the required information quality?”
References
- Bolton, W. Mechatronics: Electronic Control Systems in Mechanical and Electrical Engineering. Pearson, 2011.
- Gürdal, O. Algılayıcılar & Dönüştürücüler. Bursa Orhangazi University Press, 2015.
- Isermann, R. Mechatronic Systems: Fundamentals. Springer, 2005.
- Kuşdoğan, Ş.; Kandemir Beşer, E. Elektrik Ölçme Ders Notları. 2018.
- Billingsley, J. Mechatronics Experiments with Machine Vision. Springer Nature Switzerland, 2026. DOI: https://doi.org/10.1007/978-3-032-11218-7.
- Necsulescu, D. Advanced Mechatronics: Monitoring and Control of Spatially Distributed Systems. World Scientific, 2009. ISBN 978-981-277-181-0.
- Simo Särkkä; Lennart Svensson. Bayesian Filtering and Smoothing, 2nd ed.. Cambridge University Press, 2023. https://doi.org/10.1017/9781108917407