


Measurement Systems


Measurement systems covering error and uncertainty, RMS and power, oscilloscopes, bridges, instrument transformers, R-L-C measurement, ADC/DAQ, calibration, traceability, and data quality.
Measurement is not merely the act of assigning a number to a physical quantity. A reliable measurement is defined together with its unit, method, loading effect, calibration, error and uncertainty, bandwidth, sampling, timing, and environmental conditions. More displayed digits do not make a result more trustworthy when parts of the measurement chain are unknown.
This course uses the foundations of Circuit Theory, Electronics I and II, and Signals and Systems. The physical conversion mechanisms of sensing devices are covered in Sensors and Sensing Systems; the focus here is how a sensor or instrument output becomes a defensible engineering measurement.
Unit 1: Measurement Chain and Units
A generic measurement chain is:
physical quantity
 -> sensor
 -> signal conditioning
 -> conversion / ADC
 -> digital processing
 -> display or storage
Each layer can introduce gain error, offset, noise, nonlinearity, delay, or saturation.
A measurement is incomplete without both a numerical value and a unit. SI base and derived units enable comparable technical communication across systems and laboratories. Dimensional analysis is also an effective early error-detection method in equations and software.
1.1. Context of a Measurement Result
A measurement result contains more than a number and a unit. Method, range, calibration state, timing, and environmental conditions affect interpretation. The same 10.00 V displayed by instruments with different input impedance, bandwidth, or sampling behavior may not represent the same physical information.
SI units and dimensional analysis are practical error-detection tools. Silent conversions between mV, V, mA, A, rpm, and rad/s are common software defects in measurement systems. Units should therefore be preserved with measurement metadata whenever possible.
Unit 2: Accuracy, Precision, Sensitivity, and Resolution
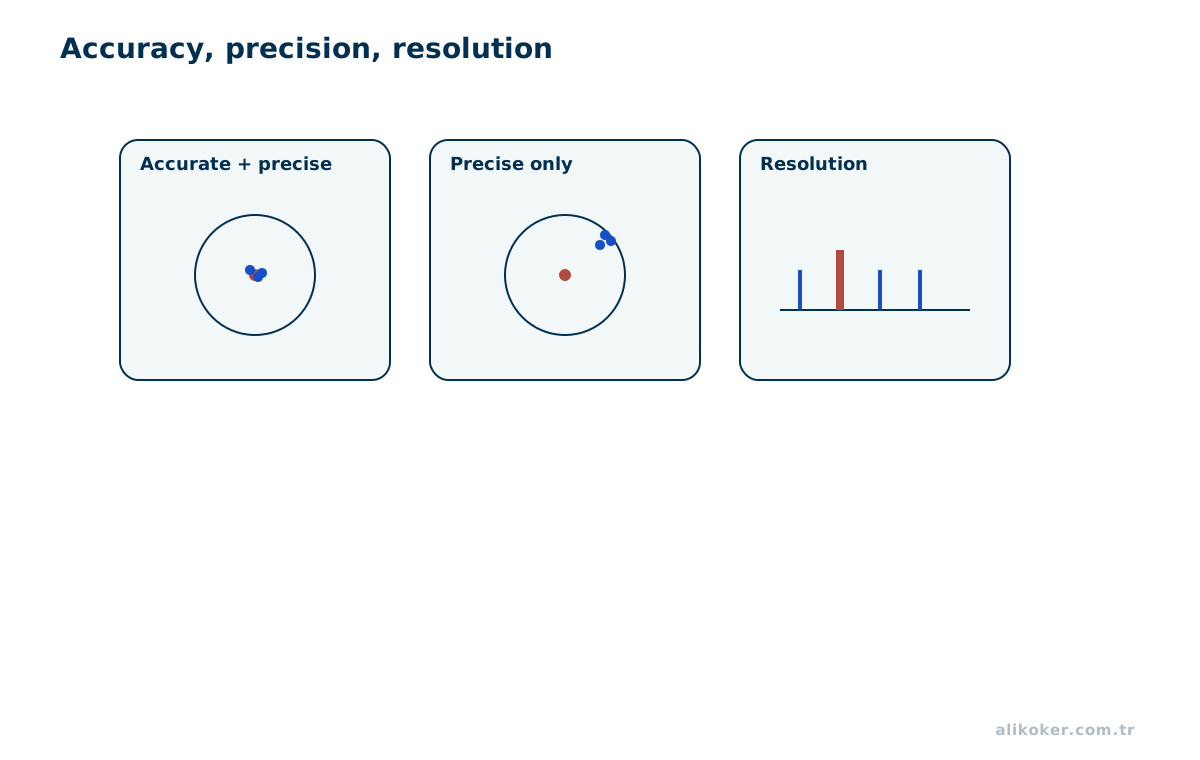
Accuracy expresses closeness to a reference or true value; precision expresses the agreement of repeated observations. Sensitivity relates output change to input change:
S=(Δ y)/(Δ x)Resolution is the smallest distinguishable change. High resolution does not imply high accuracy. A miscalibrated 24-bit acquisition chain can be less accurate than a lower-resolution system with traceable calibration.
2.1. Distinct Properties
Accuracy describes closeness to a reference, precision describes agreement among repeated results, resolution is the smallest distinguishable step, and sensitivity relates input change to output change. A high-resolution instrument can be inaccurate because of systematic offset; a repeatable sensor can still be miscalibrated.
For nonlinear sensors, local sensitivity can vary as S=dy/dx. One catalog sensitivity value may therefore not describe the full range. Resolution must also be compared with the noise floor; digital LSBs far below physical noise do not add useful information.
Unit 3: Sources of Error
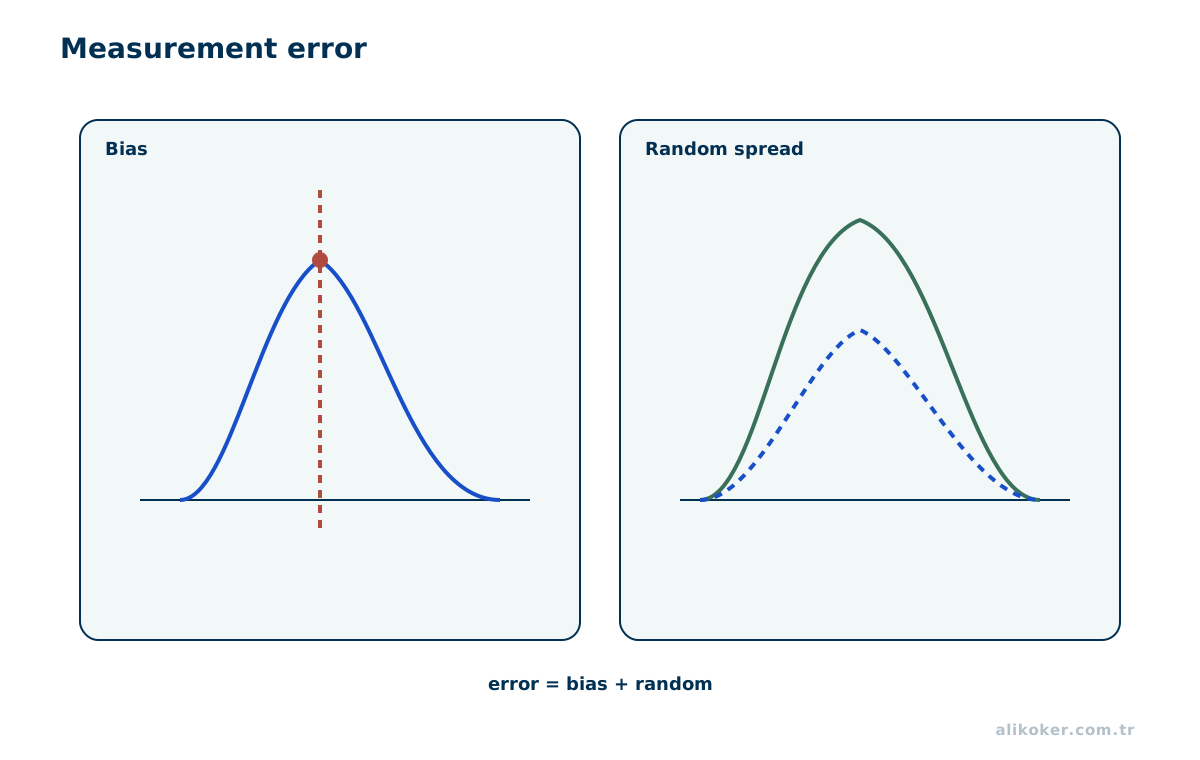
The error between a measured value x_m and a reference x_r may be written as:
e=x_m-x_rwith relative error:
e_r=(e)/(x_r)Practical error sources can be grouped as systematic effects, random effects, and gross or procedural mistakes. Systematic effects include calibration, method, offset, gain, and environmental influences. Random effects include noise and unpredictable variation across repeated observations. Connection mistakes, wrong range selection, and unit errors belong to a different procedural class.
A systematic offset does not disappear merely by averaging more samples.
To investigate measurement error, first establish reference measurement conditions. Repeated observations of the same quantity reveal dispersion; changes in temperature, frequency, or loading help identify systematic dependence. When a condition-dependent bias is found, check the correction model against independent measurements. Removing systematic bias does not eliminate random variation; their contributions to the uncertainty evaluation must remain distinct.
3.1. Separating Systematic and Random Components
Systematic errors do not disappear by averaging. Offset, gain error, method error, and temperature coefficients can remain in the same direction across repeated observations. Random components create scatter and can be characterized statistically.
The error budget extends beyond the sensor. Probe capacitance, lead resistance, ADC reference error, clock error, software scaling, and timing misalignment can all contribute. Measurement quality should therefore be analyzed end to end from the physical quantity to the reported value.
3.2. Effects of Electromagnetic Interference on the Measurement Chain
Electromagnetic interference can enter the measurement chain through sensors, cables, amplifiers, ADCs, and reference potentials. RF picked up at a high-impedance input can be rectified and appear as a low-frequency offset. Rapid common-mode transients can leave residual errors even in differential measurement because CMRR is finite. Not every spectral peak therefore belongs to the physical quantity under observation.
Source separation should compare sensor-connected, open-input, shielded-cable, source-off, and reference-load conditions. Introducing a Faraday enclosure is an experimental factor; improvement cannot be interpreted without considering changes in sensitivity, frequency response, and cable geometry. The instrument's own emissions may contribute to background interference.
Unit 4: Uncertainty and Propagation
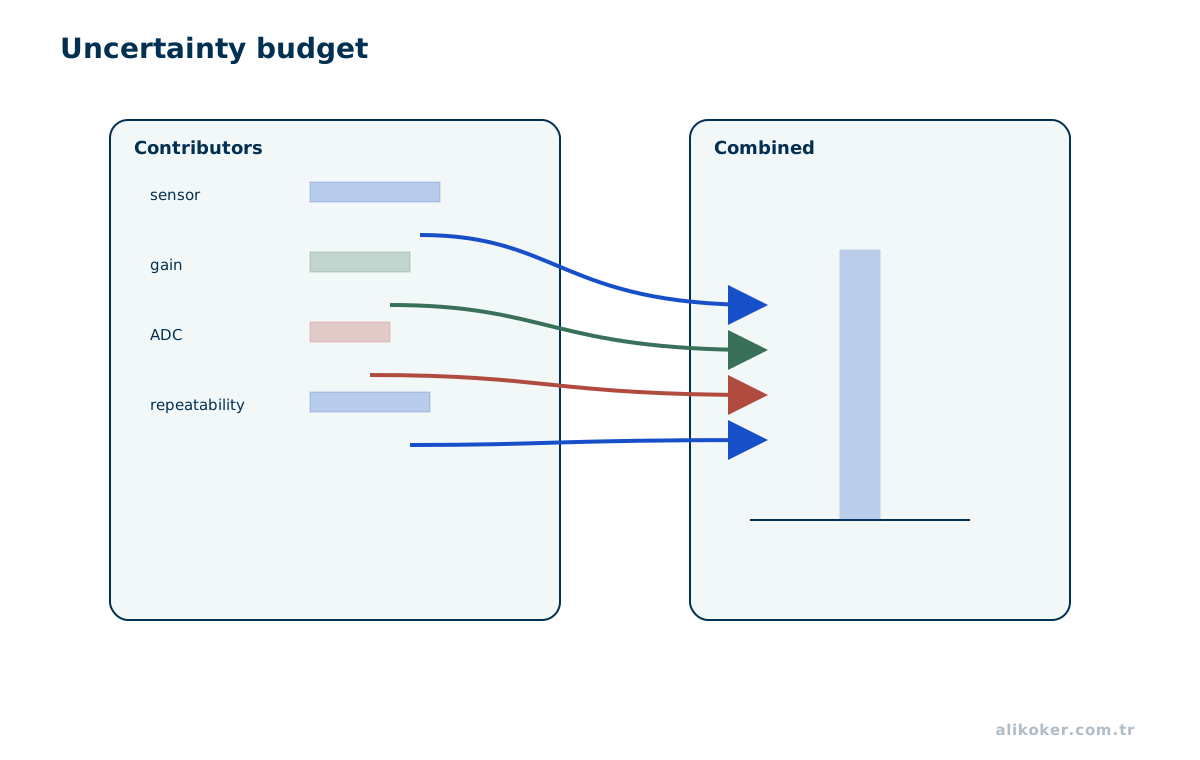
When a result is calculated from measured quantities, their uncertainties propagate into the result. For y=f(x_1,…,x_n) with small independent uncertainties:
u_y^2 ≈ Σ_i ((∂ f)/(∂ x_i))^2u_(x_i)^2is a common first-order approximation. Correlated inputs require covariance terms. Therefore simply adding all percentage errors is not generally valid.
A reported result should include value, unit, uncertainty, and appropriate coverage or confidence information when those are material to its use.
An uncertainty budget begins with an explicit measurement model and the identification of its input quantities. Evaluate each input uncertainty from the available evidence and propagate its effect through the sensitivity coefficients. Do not discard covariance for dependent inputs. After computing combined uncertainty, identify dominant contributors and determine which further measurements could reduce them. Reporting a numerical interval without stating the assumptions behind its coverage is insufficient.
4.1. Uncertainty Budget
For y=f(x1,x2,...,xn), a first-order combined standard uncertainty for independent inputs can be approximated by:
u_c^2(y) ≈ Σ (∂f/∂x_i)^2 u^2(x_i)Correlated inputs require covariance terms. This matters when two quantities share the same reference or environmental influence.
Uncertainty does not mean that the measurement is “wrong”; it quantifies the interval supported by available knowledge. Calibration uncertainty, resolution, repeatability, and environmental effects can all enter the budget with appropriate distributions and sensitivity coefficients.
4.2. Communicating Measurement Uncertainty Graphically
Before plotting an uncertainty budget, identify the displayed quantity: uncertainty of a single instrument reading, standard error of a sample mean, and uncertainty in a calibration correction are different objects. A short error bar does not necessarily demonstrate high precision; axis scaling or omitted components may create the same impression. A figure should state the coverage factor, the interpretation of its confidence or coverage level, and the units of uncertainty.
With asymmetric or multimodal repeated measurements, symmetric error bars around the mean may conceal the distribution's structure. Density displays, quantile dotplots or repeated hypothetical outcomes provide alternatives. Yet discrete steps induced by instrument resolution should not be smoothed away as though they were continuous random noise. A graph must not imply a level of discrimination that the measurement chain cannot support.
When measurements from several sensors are compared, correlations induced by a shared calibration reference may matter substantially. Independent error bars can misrepresent the uncertainty of their difference in either direction. The covariance contribution must be included when evaluating differences, and the statistical model underlying the graphic should remain explainable in its caption or accompanying text.
An uncertainty budget for a derived quantity. Suppose resistance is calculated as R = V/I from V = 12.00 V, u(V) = 0.12 V, I = 2.00 A, and u(I) = 0.04 A. Assume both input uncertainties are standard uncertainties and mutually independent. The nominal result is R = 6.00 Ω. First-order propagation gives relative combined uncertainty u(R)/R = √[(u(V)/V)² + (u(I)/I)²] = √(0.01² + 0.02²) ≈ 0.02236. Thus u(R) ≈ 0.134 Ω, and the result may be reported approximately as R = (6.00 ± 0.13) Ω, explicitly identifying ± as standard uncertainty rather than a coverage interval. Correlated inputs, for example due to common calibration, require covariance terms. The result shown applies only under independence. Establish the measurement model first, then dependencies, propagation, and reporting.
Unit 5: Statistics of Repeated Measurements
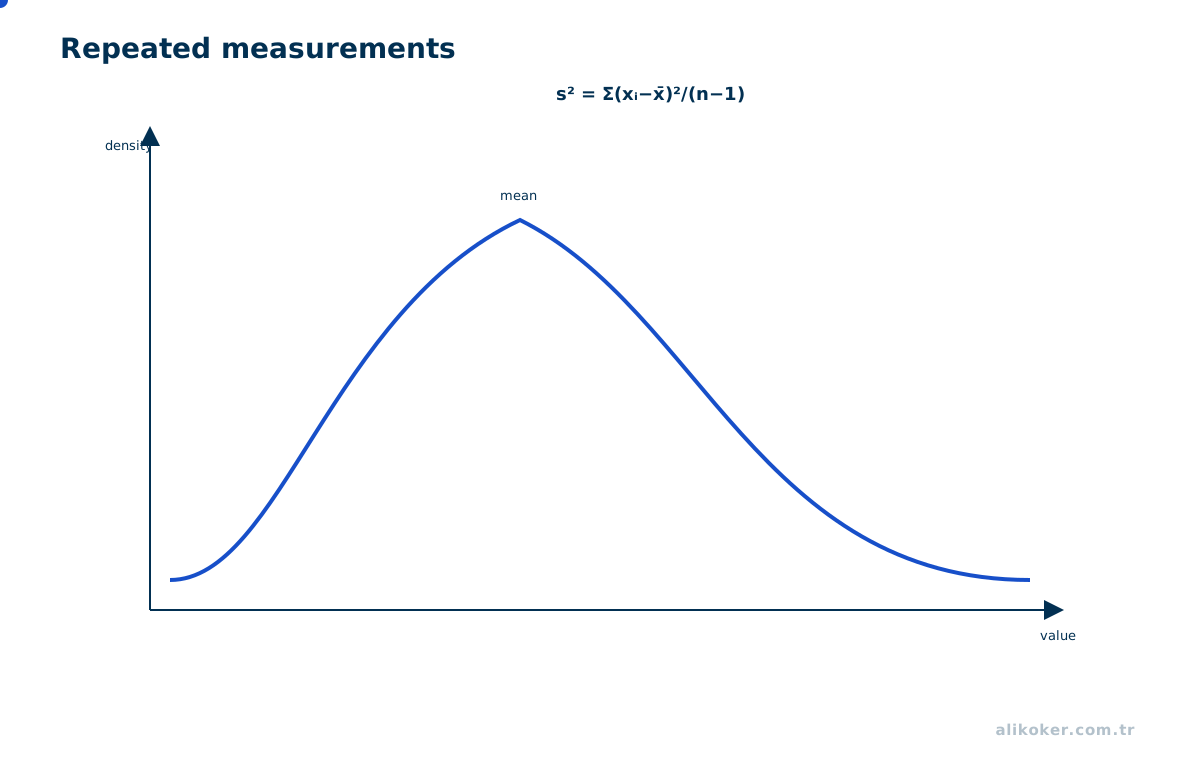
For n observations:
x̄=(1)/(n)Σ_(i=1)^nx_iand the sample standard deviation is:
s=√((1)/(n-1)Σ_(i=1)^n(x_i-x̄)^2)A small standard deviation does not prove accuracy; a systematic offset can produce tightly clustered but biased measurements. Outlier removal must also be justified and recorded rather than used as an undocumented way to improve results.
5.1. The Mean Is Not Enough
The arithmetic mean describes central tendency and standard deviation describes dispersion, but drift or autocorrelation violates the assumption of independent samples. Taking thousands of samples per second does not reduce uncertainty as 1/sqrt(N) when samples are strongly correlated.
Outliers should not be deleted automatically. Contact faults, packet loss, or genuine transients can have similar statistical appearance. Statistical processing should remain connected to the physics of the process.
Unit 6: Loading Effect
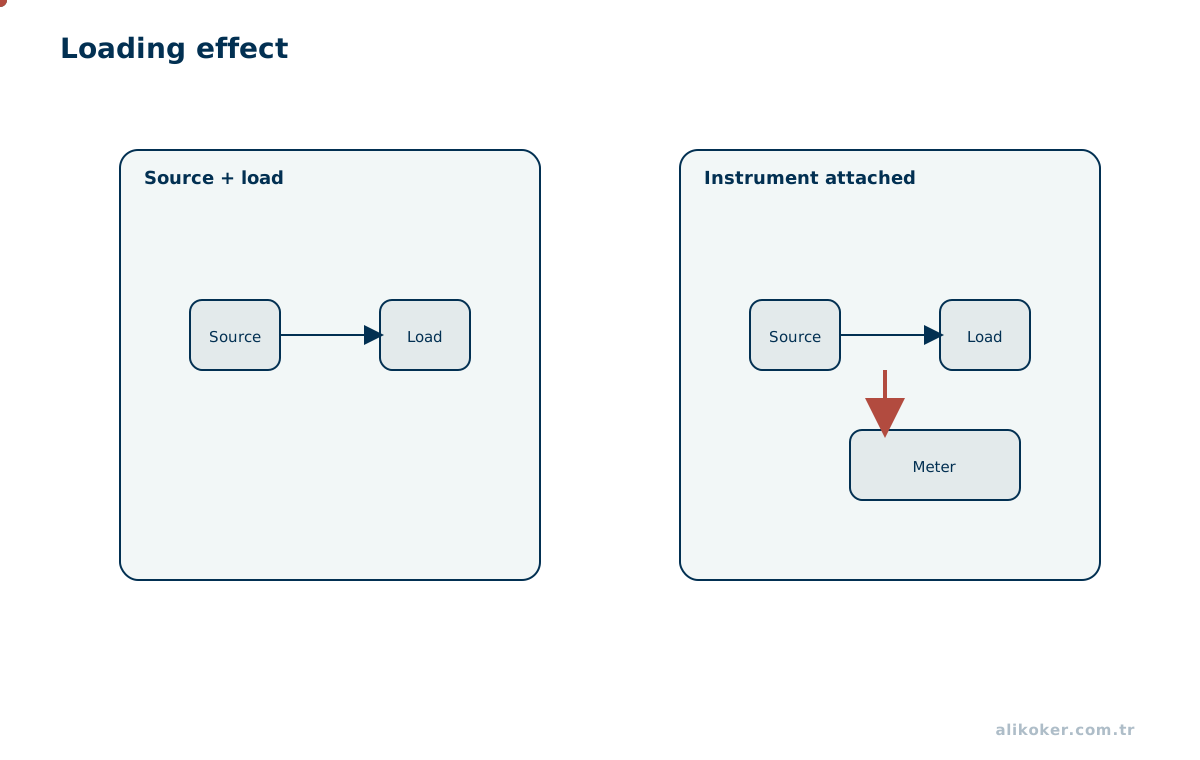
An ideal instrument would obtain information without drawing energy from the measured system. Real instruments alter the system to some degree.
For a Thevenin source V_th,R_th and voltmeter input resistance R_v:
V_m=V_th(R_v)/(R_th+R_v)A finite R_v therefore changes the voltage being measured. An ammeter should have sufficiently small series impedance. At high frequency, probe capacitance and lead inductance become part of the loading problem as well.
6.1. Measurement Changes the System
An ideal voltmeter has infinite input resistance and an ideal ammeter zero series resistance; real instruments modify the circuit. If voltmeter input resistance is comparable to a divider resistance, the node voltage changes when the meter is connected. A current shunt adds resistance and burden voltage to the current path.
An oscilloscope probe is also part of the circuit. Probe resistance and capacitance can disturb high-impedance or high-frequency nodes. A 10x probe often reduces capacitive loading at the cost of signal amplitude. Loading error is distinct from instrument accuracy.
Unit 7: Static and Dynamic Characteristics
Static characteristics include range, sensitivity, nonlinearity, hysteresis, repeatability, resolution, saturation, and drift.
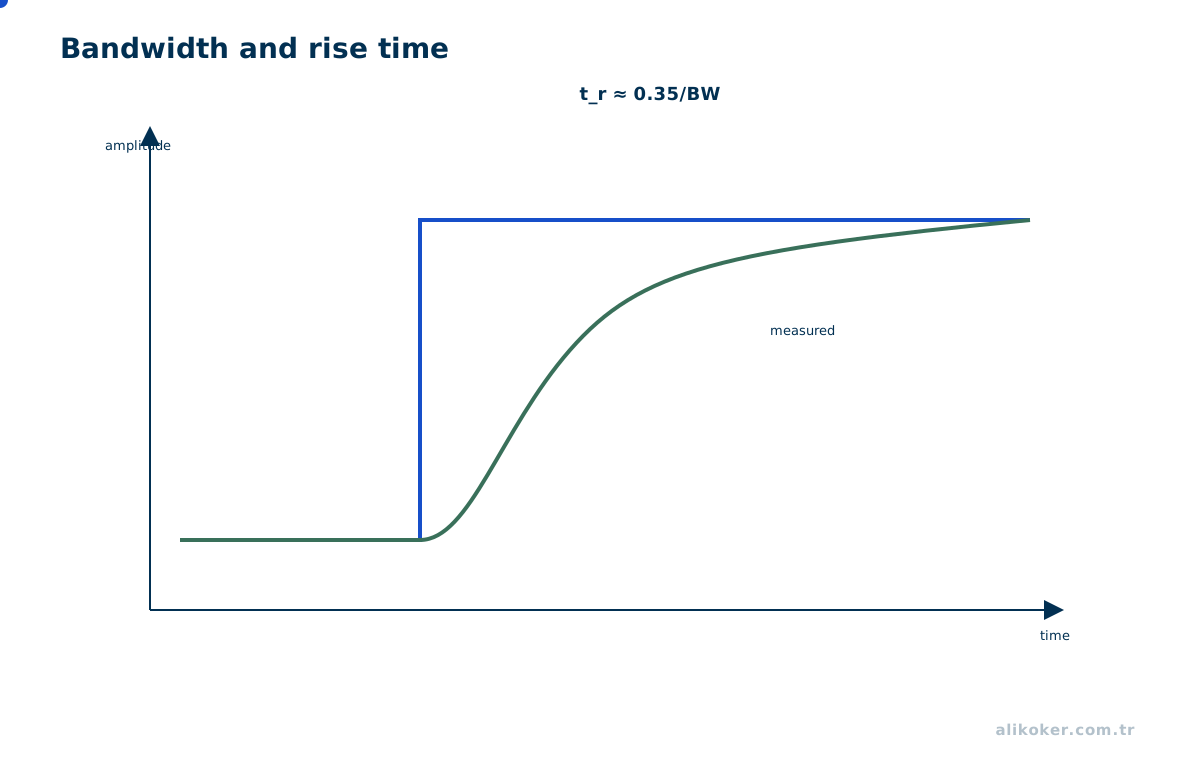
Dynamic measurement adds bandwidth and time constants. A first-order approximation:
τ dy/dt+y=Kxshows that a rapidly changing input cannot be reproduced instantly. Delay may originate in the physical sensing element and analog front end as well as in software.
7.1. Inferring Measurement Limits from a first-order Sensor Response
Take a unity-gain sensor described by τ dy/dt + y = x. For τ = 0.02 s, a unit-step input from zero initial state gives y(t) = 1 - exp(-t/0.02). At 40 ms, the reading is approximately 0.865: the sensor reports only 86.5% of the applied step. This difference may indicate incomplete dynamic settling rather than an incorrect static calibration factor.
The magnitude response is |H(jω)| = 1 / sqrt(1 + (ωτ)^2), with a -3 dB cutoff at 1/(2πτ) ≈ 7.96 Hz. At 20 Hz the amplitude ratio falls to roughly 0.37. Static calibration cannot remove this frequency-dependent attenuation. Experimental identification requires a reference with adequate bandwidth, excitation within the sensor's linear region, and aligned sampling clocks. A reported measurement is incomplete unless the frequency range over which its accuracy is required has been established.
7.2. Estimating Frequency Response with a Known Excitation
The frequency response of a dynamic measurement chain cannot be identified solely by observing an unknown environmental input. A verified stimulus x(t) is applied and output y(t) acquired synchronously. With input noise assumed negligible, a transfer estimate is H₁(f) = S_yx(f)/S_xx(f), using cross- and auto-spectral densities. Magnitude-squared coherence, γ²(f) = |S_yx(f)|²/[S_xx(f) S_yy(f)], lies between 0 and 1. Low coherence may indicate noise, time variation, or nonlinearity weakening a linear input–output model; it does not identify a unique cause.
For a swept-sine or band-limited broadband excitation, the test must confirm sufficient stimulus energy across the band. Windowing, record duration, clock alignment, and frequency resolution are reported. Without accounting for the reference microphone or probe response, the estimated transfer function describes the complete measurement chain, not the device under test alone. Repetition across stimulus levels and sessions helps distinguish saturation, drift, and instability.
Unit 8: Measurable Values of Periodic Signals
For a periodic signal x(t):
f=(1)/(T)Instantaneous value refers to a specific time, while peak value characterizes an extreme. The average over one period is:
X_avg=(1)/(T)∫_0^T x(t) dtand RMS is:
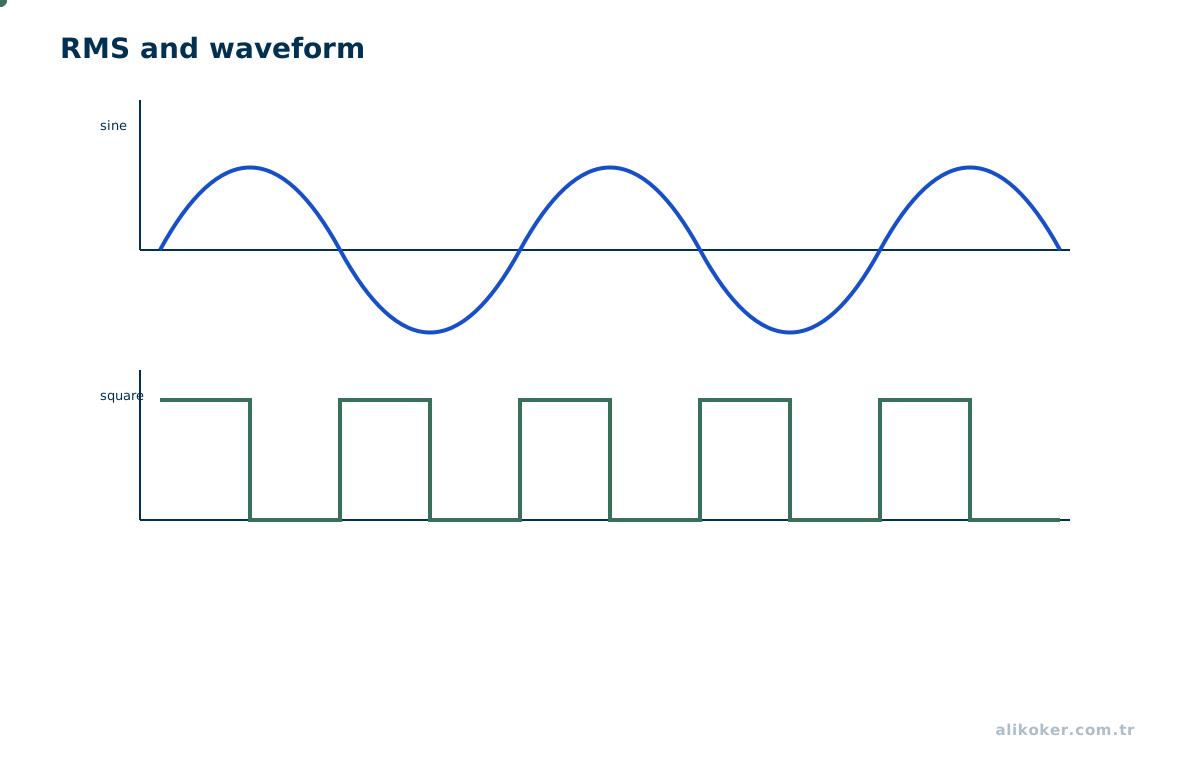
X_RMS=√((1)/(T)∫_0^T x^2(t) dt)RMS is related to equivalent heating in a resistive load. For nonsinusoidal waveforms, an average-responding meter should not be interpreted as a true-RMS instrument.
8.1. RMS and Waveform Dependence
RMS is the DC-equivalent heating value:
x_rms = sqrt((1/T) ∫ x^2(t) dt)For a sine wave, V_rms=V_peak/sqrt(2), but this relationship is not universal. PWM and rectified waveforms can produce different readings in true-RMS and average-responding instruments.
Crest factor, the ratio of peak to RMS, matters because an input stage can saturate on narrow peaks even when RMS remains within range.
Unit 9: Power Quantities
Instantaneous power is:
p(t)=v(t)i(t)For sinusoidal steady state:
P=V_RMSI_RMScosφQ=V_RMSI_RMSsinφS=V_RMSI_RMSand:
S^2=P^2+Q^2For nonsinusoidal signals, harmonics mean that power factor cannot be reduced to cosφ alone; instrument bandwidth and sampling method matter.
9.1. Power under Nonsinusoidal Conditions
For pure sinusoids, active power can be written as P=V_rms I_rms cosφ. Nonlinear loads such as rectifier inputs can draw nonsinusoidal current, so phase displacement alone is not sufficient. True active power is the time average of p(t)=v(t)i(t).
Apparent power remains S=V_rms I_rms, and power factor can be written as PF=P/S. Harmonic distortion can separate displacement factor from total power factor. Limited instrument bandwidth can also omit harmonic power contributions.
Unit 10: Voltage, Current, and Resistance Measurement
Voltmeters are connected in parallel and ammeters in series, but their internal impedances affect the circuit. Two-wire resistance measurement includes lead and contact resistance; four-wire Kelvin measurement can reduce that error for low resistances.
An ohmmeter must not be applied to an energized circuit. Measurement category, maximum input rating, fuse type, and probe rating are safety properties, not merely instrument specifications.
10.1. Current-measurement Choices
Current can be measured with a series meter, a differential shunt, a Hall device, or a current transformer. A shunt can be accurate and wideband but dissipates power and creates common-mode challenges. Hall sensing can provide isolation but introduces offset and bandwidth limitations.
Four-wire Kelvin measurement reduces lead and contact resistance error for low resistances. A two-wire measurement includes series lead and contact resistance in the result, so topology must match the resistance range.
Unit 11: Oscilloscope Measurements
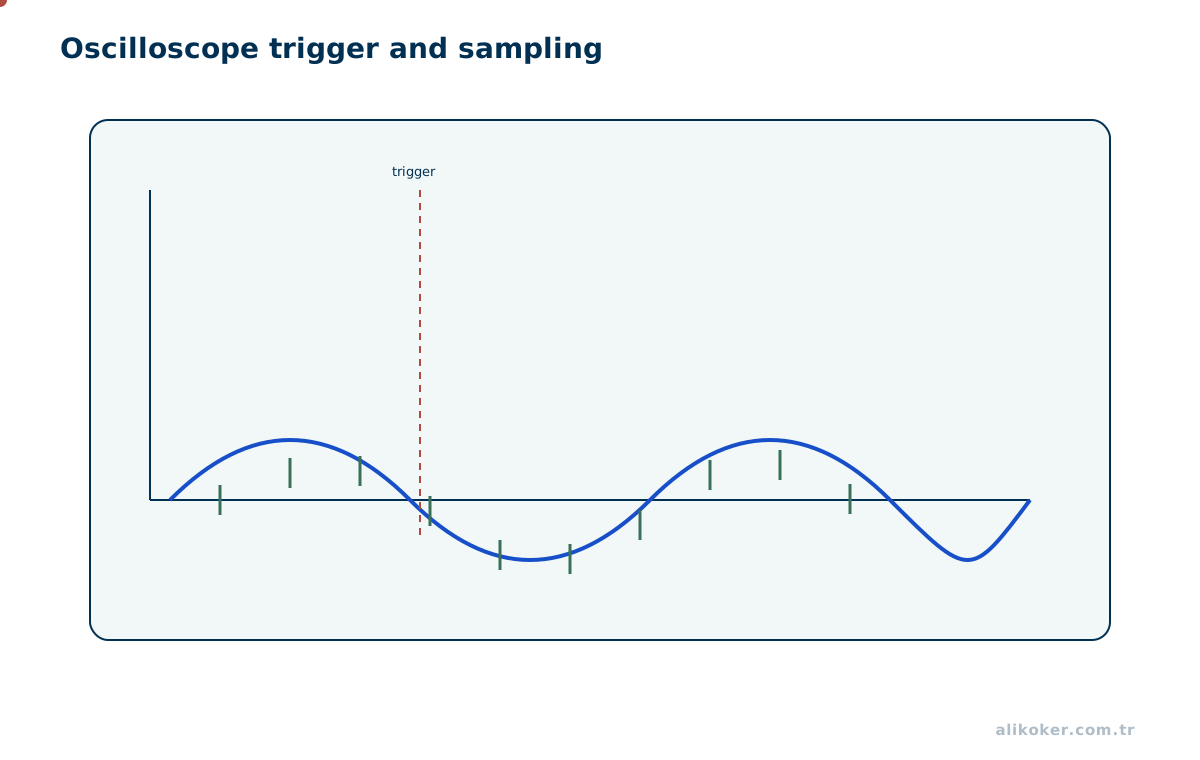
An oscilloscope is a primary tool for observing voltage, time, frequency, phase, rise time, duty cycle, and transient behavior.
Probe attenuation, input resistance, input capacitance, bandwidth, and ground connection are part of the measurement. A long ground lead can form an inductive loop and display ringing that is caused by the measurement setup rather than the circuit itself.
Connecting a conventional earth-referenced oscilloscope ground clip to mains-referenced or floating power-electronics nodes can create a short circuit and shock hazard. Differential or isolated measurement methods must be selected according to topology and instrument ratings.
11.1. Bandwidth, Rise Time, and Sampling
Analog bandwidth limits the frequency content that reaches the digitizer. For an approximately single-pole response, t_r ≈ 0.35/BW relates rise time and bandwidth. Fast digital edges require bandwidth beyond the clock fundamental because edge shape contains higher harmonics.
Sampling rate and analog bandwidth are different. A high sample rate cannot recover content already attenuated by the analog front end. Record length determines how long a signal can be captured at useful time resolution, while trigger configuration determines whether repetitive or rare events can be observed stably.
Ground leads can create both measurement error and safety hazards on line-referenced or high-side nodes. Differential probes, isolated architectures, or current probes should be selected according to circuit topology.
Unit 12: Signal Generators and Test Setup
Function generators produce controlled sine, square, triangle, and pulse signals. Displayed amplitude may be specified for a 50-Ω load or for high impedance. Misunderstanding this convention can make the actual test voltage appear roughly doubled or halved.
The grounding relationships between generator, oscilloscope, and device under test must be understood before connections are made.
12.1. Experimental Measurement of Faraday-Cage Shielding Effectiveness
Shielding effectiveness compares field levels obtained with and without an enclosure. Source, receiver, antenna orientation, frequency, distance, polarization, and surroundings must be defined for the reference experiment. If the geometry is altered when adding the screen, the difference cannot be attributed only to the enclosure. Results depend on receiver position and dynamic range; they are not a universal single number for the entire enclosure.
SE_E(f) = 20 log₁₀(|E_ref(f)| / |E_shielded(f)|) dB
SE_H(f) = 20 log₁₀(|H_ref(f)| / |H_shielded(f)|) dB
SE_P(f) = 10 log₁₀(P_ref(f) / P_shielded(f)) dB
When the shielded level approaches the receiver noise floor, only a lower bound may be established; an undetected signal is not necessarily zero. Units, receiver linearity, repetitions, and calibration status are documented. When a plane-wave far-field approximation is inappropriate, electric and magnetic near-field responses must be treated separately.
IEEE 299-2006 provides a historical reference for large-enclosure tests, but its inactive status in 2026 should be stated. Small equipment enclosures should not be forced into methods intended for room-sized structures.
Unit 13: Power and Energy Measurement
Wattmeters and digital power analyzers measure voltage and current together to derive power. Phase error becomes especially significant at low power factor.
Energy is the time integral of power:
E=∫ P(t) dtIn electronic meters, sampling, calibration, and timebase accuracy all contribute to the measurement result.
13.1. Channel Timing and Power Accuracy
Power measurement depends on channel phase alignment as well as amplitude accuracy. At low power factor, a small phase error can create a large relative active-power error. Propagation delays of different voltage and current probes may require deskew.
Energy is the time integral of power. Sampling gaps, counter rollover, and clock error can accumulate over long measurements. Timebase quality and data-loss policy therefore belong to the metrology chain.
Unit 14: Current and Voltage Instrument Transformers
Current transformers (CTs) and voltage transformers (VTs/PTs) translate high current and voltage to levels suitable for instrumentation and protection.
Ratio and phase errors of CTs propagate into power and energy measurements. A CT secondary must not be left open while primary current is flowing, because a dangerous high voltage can develop. A voltage-transformer secondary must not be short-circuited. Grounding and protection must follow the manufacturer's instructions and applicable standards.
14.1. CT and VT Safety Boundaries
A current-transformer secondary should normally see a low-impedance burden. Opening the secondary while primary current flows can drive core flux and secondary voltage to hazardous levels. A voltage-transformer secondary, in contrast, can produce excessive current if shorted. Their safe fault behavior is therefore fundamentally different.
Ratio error and phase error both affect power measurement. Burden, accuracy class, and frequency range should stay within specified limits. Protection CTs and metering CTs may intentionally use different saturation characteristics.
Unit 15: Wheatstone Bridge and DC Bridges
For a balanced Wheatstone bridge:
(R_1)/(R_2)=(R_3)/(R_x)An unbalanced bridge converts small resistance changes from strain gauges, RTDs, and similar sensors into a differential voltage.
Increasing bridge excitation increases signal level but can also increase sensor self-heating. Sensitivity and thermal error must therefore be evaluated together.
15.1. Using an Unbalanced Bridge as a Sensor Interface
A Wheatstone bridge is useful not only for finding an unknown resistance at null but also for converting small resistance changes from strain gauges or RTDs into differential voltage. Quarter-, half-, and full-bridge arrangements offer different sensitivity and temperature compensation.
Small changes can be approximated linearly; larger changes require the full bridge equation. Excitation stability, lead resistance, and instrumentation-amplifier offset all enter the low-level error budget.
Unit 16: AC Bridges
In AC bridges, resistances are generalized to complex impedances. Balance requires both magnitude and phase conditions. The complex relation:
Z_1 Z_3=Z_2 Z_4allows resistive and reactive components to be solved together. AC bridges can be used to measure capacitance, inductance, loss, and frequency-dependent element parameters.
16.1. Simultaneous Magnitude and Phase Balance
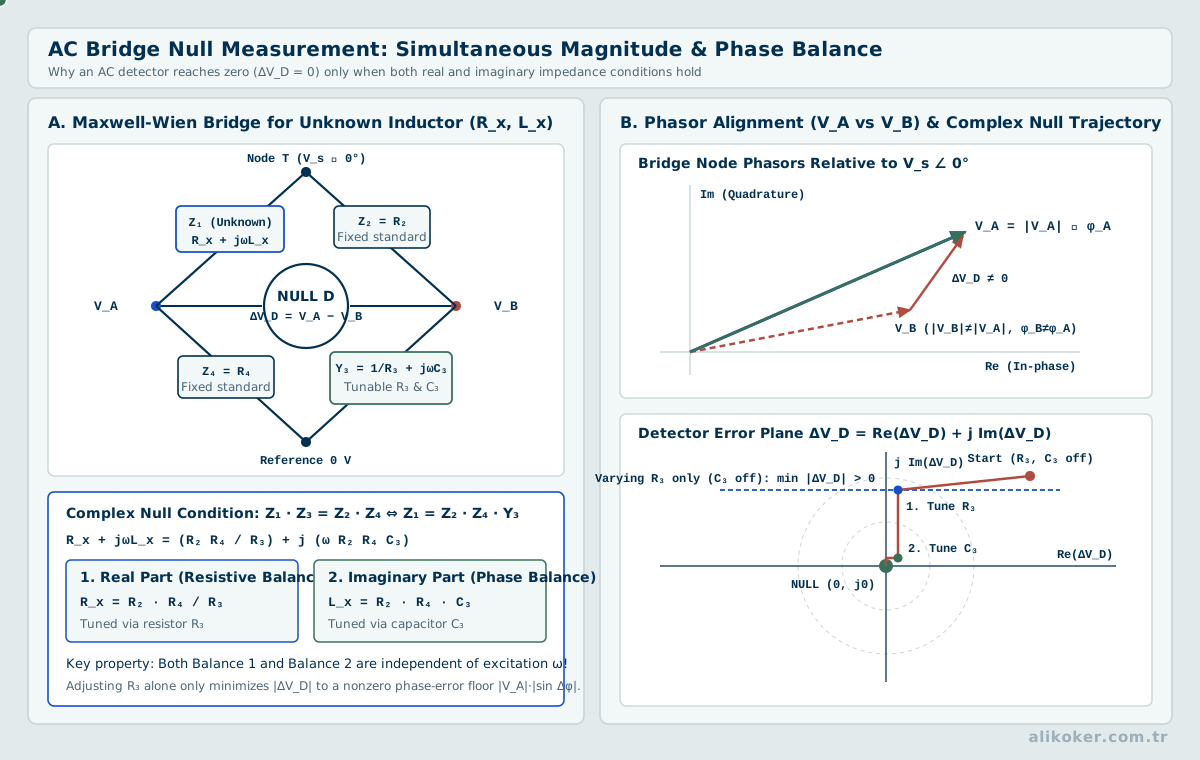
AC bridge elements are represented by complex impedance. Balance requires the appropriate relationship between real and imaginary components, producing independent magnitude and phase conditions.
Measurement frequency influences the apparent L or C and the associated loss model. Real capacitors have ESR and leakage, while inductors have winding resistance and parasitic capacitance. Ideal-element models lose validity as frequency rises.
Unit 17: Measuring R, L, C, and Mutual Inductance
Resistance, capacitance, inductance, and mutual inductance can be measured by several methods. In voltage-current methods, instrument impedance and phase error affect the result. At high frequency, parasitic capacitance and inductance invalidate ideal-element assumptions.
A real coil is not described by L alone; winding resistance, core loss, and parasitic capacitance shape its frequency-dependent behavior.
Unit 18: Digital Measurement and ADCs
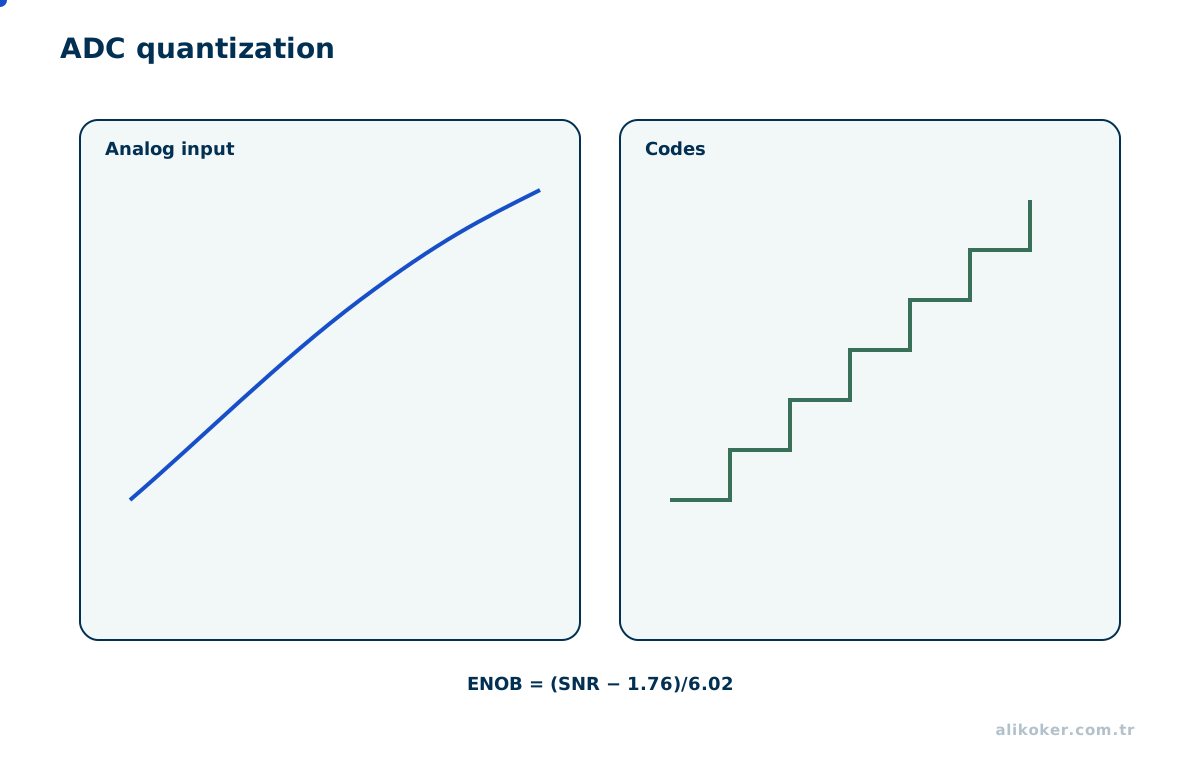
An ideal N-bit ADC provides 2^N codes, but ENOB, offset, gain error, INL, DNL, reference noise, and analog drive conditions limit real performance.
Sampling rate must be selected together with anti-alias filtering, desired time resolution, and processing budget. Digital filtering cannot remove aliasing that has already occurred before sampling.
18.1. Quantization, Reference, and ENOB
For an ideal N-bit ADC, one LSB is approximately V_FS/2^N. Real accuracy also includes offset, gain error, INL, DNL, reference noise, and input-drive error. Effective number of bits (ENOB) often describes dynamic performance more realistically than nominal resolution.
The sample-and-hold capacitor must settle through the source impedance during acquisition time. Excessive source impedance can prevent full settling. Buffering and RC networks therefore serve both filtering and ADC drive requirements.
Unit 19: Data Acquisition and Time
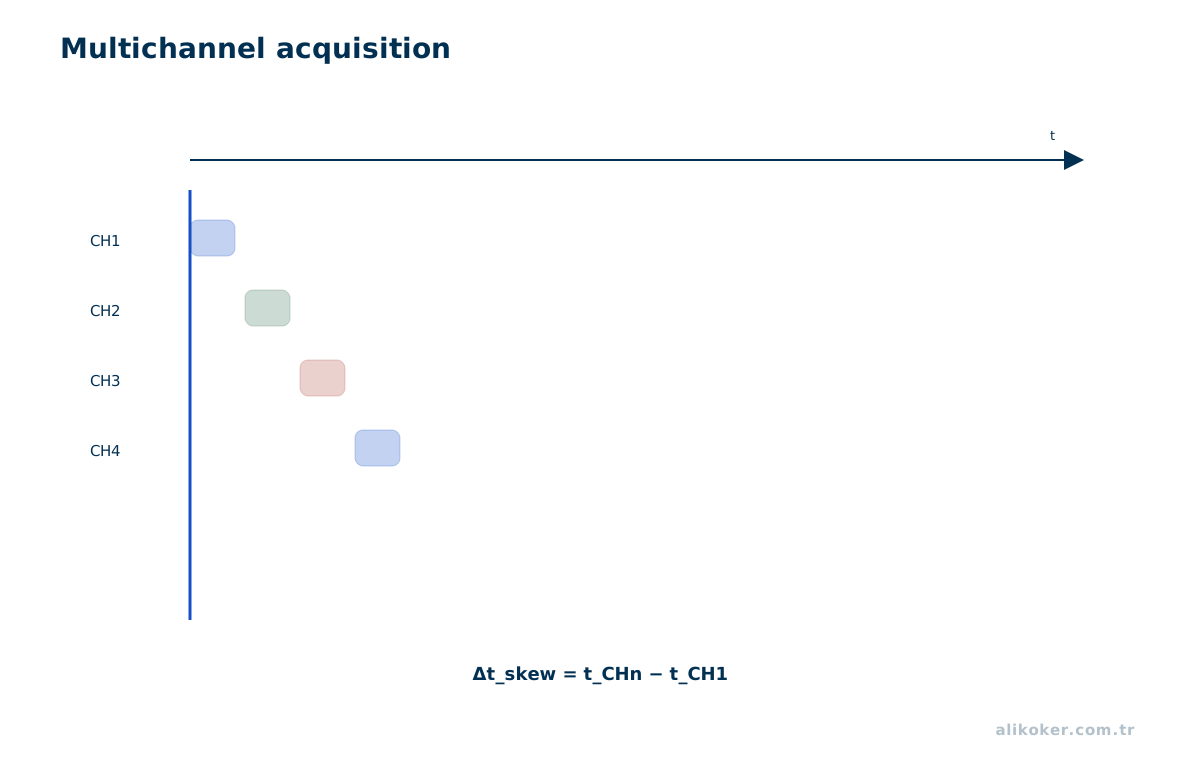
In multi-channel DAQ systems, it matters whether samples are acquired simultaneously or sequentially through a multiplexer. Channel-to-channel delay can become phase error in fast dynamics.
A useful measurement record should preserve, where applicable:
value
unit
timestamp
channel / sensor identity
calibration version
quality / fault state
19.1. Simultaneity in Multichannel Acquisition
A multiplexed ADC samples channels sequentially, not at the same instant. In fast mechanical systems, scan delay can create phase error. Simultaneous-sampling ADCs or external sample-and-hold structures may be required.
DAQ quality also depends on timestamp source, clock drift, buffer overflow, and packet loss. Raw value, channel identity, unit, calibration version, time, and validity flag should be retained together for auditable data.
Unit 20: Calibration and Traceability
Calibration compares an instrument or chain with an appropriate reference and quantifies deviations. Adjustment and calibration are not the same operation; a device may be calibrated without being adjusted.
Traceability connects a result through an unbroken calibration chain to recognized references. Calibration date, conditions, and uncertainty are necessary context; the statement “calibrated” alone is incomplete.
20.1. Calibration Is Not Correction
Calibration characterizes instrument behavior against a reference and records uncertainty. A correction may be applied afterward, but “calibrated” does not mean error-free.
Traceability links the result through an unbroken calibration chain to an appropriate standard, with each link contributing uncertainty. Calibration intervals can be based on drift history, usage, environment, and risk rather than on a fixed calendar habit.
20.2. Dynamic Inverse Calibration in the Presence of Noise
A dynamic measurement chain can be modeled as Y(f) = H(f)X(f) + N(f). Direct division by H(f) amplifies noise at frequencies strongly attenuated by the sensor. Where the magnitude response is 0.05, an additive output disturbance of 0.01 becomes an input-estimation error of 0.20 after inversion. Higher arithmetic precision does not restore information lost to limited measurement bandwidth.
Acceptable reconstruction depends on the frequency range required by the application. One regularized form is X̂(f) = H*(f)Y(f) / (|H(f)|² + λ), where λ > 0 limits amplification near response nulls at the cost of bias in genuine high-frequency components. This parameter should be selected using calibration evidence and separately validated observations, rather than interpreting the smallest fitting error as proof of accuracy. A calibration result must state the usable reconstruction bandwidth and residual uncertainty, not just display a corrected waveform.
For a first-order sensor with transfer function H(s)=1/(τs+1), the ideal inverse is 1/H(s)=τs+1. Inverting the dynamics includes differentiation and can amplify high-frequency measurement noise. With τ=0.2 seconds and angular frequency 50 rad/s, the inverse magnitude is approximately √101, or 10.05. Dynamic compensation must therefore be bounded by sensor bandwidth, noise spectrum, and latency. Accuracy of a static calibration table does not establish that an inverse filter is stable and useful in practice.
20.3. Validating Frequency-Dependent Calibration
Dynamic calibration characterizes frequency-dependent gain, phase, and associated uncertainty rather than only a static scalar correction. Phase calibration is meaningful only if reference and device measurements refer to the same physical excitation and time base. Estimated delay includes cables, filters, and digital buffering; these contributions must be separated before assigning latency to the physical sensor alone.
Validation uses test excitations independent of those used to derive the calibration. Results report not only post-correction error but also valid bandwidth, residual phase error, repeatability, and noise amplification caused by correction. Original waveforms and calibration records are retained; a corrected series is an estimate derived from measurements, not a new primary observation.
20.4. Uncertainty and Repeatability in Shielding Measurements
Shielding effectiveness is a logarithmic difference of two measurements; receiver gain, source stability, positioning, antenna calibration, and background conditions therefore contribute jointly to uncertainty. Correlated components must not be treated as independent by default. Reusing one calibrated receiver in both measurements differs from using two unrelated instruments because some errors may be common to both observations.
SE_dB = L_reference,dB − L_shielded,dB
u²(SE) = u²(L_ref) + u²(L_shielded) − 2 cov(L_ref, L_shielded)
The equation must be applied with appropriate assumptions concerning nonlinearities and decibel conversion. Repositioning between conditions calls for separate repeatability and reproducibility studies. Report attenuation versus frequency together with uncertainty and detection limit, rather than an average attenuation alone. JCGM 100:2008 provides the general uncertainty framework.
Unit 21: Faults, Validity, and Data Quality
Sensor disconnection, short circuit, saturation, ADC overrange, timeout, CRC error, and physically impossible rate of change are different failure classes. Invalid data should not be converted to numeric zero because zero may be a valid physical measurement.
A measurement chain should produce information about confidence as well as magnitude. Critical systems may use plausibility checks, redundancy, and cross-checks based on different sensing principles.
21.1. Separate Value from Quality State
A legitimate measurement can be zero; using zero to mean “no data” or “sensor fault” creates ambiguity. Value, timestamp, and quality status should therefore be separate. Saturation, stale data, CRC failure, calibration invalidity, and physically impossible values can have distinct flags.
Plausibility checks can extend beyond min/max thresholds. Rate of change, energy balance, relationships to other sensors, or a physical model can reveal plausible-but-wrong data. In critical systems, data quality should be an explicit input to the control logic.
Course Boundaries
The physical conversion mechanisms of resistance, capacitance, Hall effect, and piezoelectric sensing are developed in Sensors and Sensing Systems; Fourier and sampling theory in Signals and Systems; and op-amp and ADC circuit structures in Electronics I and II. This course integrates them from the perspective of measurement reliability.
Applied Measurement Design: Current in a PWM Motor Drive
Measuring current in a PWM-driven DC motor connects most measurement concepts in one example. The measurand must first be defined: average current, RMS current, switching ripple, and short-circuit peak current are different quantities and demand different bandwidth.
A low-side shunt uses V_shunt=I*R_shunt but dissipates I_rms^2 R_shunt. A high-side shunt avoids disturbing ground but requires measurement under high common-mode voltage. Hall sensing can provide galvanic isolation with low insertion loss, while offset, temperature drift, and bandwidth remain important.
For oscilloscope work, current-probe bandwidth, zero offset, and deskew matter. For long-duration thermal analysis, DAQ sample rate, anti-alias filtering, and data volume dominate. One physical current can therefore require different measurement chains for different engineering questions.
A result becomes auditable when range, sensor, bandwidth, sampling, uncertainty, and time accompany the value rather than only I=3.2 A.
21.2. Distinguishing Stuck Measurements from Low Noise
A near-zero-variance sensor channel may reflect stable physics or a stuck output. Diagnosis needs expected excitation, sensor resolution, operating mode and independent reference information. A constant reading is not proof of accuracy. Slow bias drift and isolated impulses require different detectors; their shared mathematical foundations are addressed in Anomaly Detection.
References
- Billingsley, J. Mechatronics Experiments with Machine Vision. Springer Nature Switzerland, 2026. DOI: https://doi.org/10.1007/978-3-032-11218-7.
- Celozzi, Salvatore; Araneo, Rodolfo; Lovat, Giampiero. Electromagnetic Shielding. Wiley-IEEE Press, 2008. ISBN 978-0-470-05536-6.
- Doebelin, E. O. Measurement Systems: Application and Design. McGraw-Hill, 2004.
- IEEE. IEEE 299-2006: Standard Method for Measuring the Effectiveness of Electromagnetic Shielding Enclosures. 2006. Historical/inactive edition as of 2026. https://standards.ieee.org/ieee/299/3090/
- JCGM. Evaluation of Measurement Data — Guide to the Expression of Uncertainty in Measurement (JCGM 100:2008), 2008.
- Kuşdoğan, Ş.; Kandemir Beşer, E. Elektrik Ölçme Ders Notları. 2018.
- Necsulescu, D. Advanced Mechatronics: Monitoring and Control of Spatially Distributed Systems. World Scientific, 2009. ISBN 978-981-277-181-0.
- Walter W. Piegorsch, Richard A. Levine, Hao Helen Zhang, Thomas C. M. Lee (eds.). Computational Statistics in Data Science. Wiley, 2022. ISBN 9781119561071.
- Simo Särkkä; Lennart Svensson. Bayesian Filtering and Smoothing, 2nd ed.. Cambridge University Press, 2023. https://doi.org/10.1017/9781108917407