


Actuators, Electrical Machines and Drive Systems


Actuators, electrical machines and drive systems: DC, induction, synchronous, PMSM/BLDC, stepper, reluctance and linear motors; solenoids, hydraulic and pneumatic actuators, load matching, drive interfaces, thermal limits, braking, and safe operation.
An actuator converts low-power control information into a physical output such as force, torque, displacement, pressure, or flow. Electrical machines are the most common members of this class, but mechatronic actuation also includes solenoids, hydraulic systems, pneumatics, and piezoelectric devices selected according to speed, power density, precision, and safe-state requirements.
This course continues the semiconductor and circuit foundation of Electronics I and II and the energy-flow view of Introduction to Mechatronics Engineering. Detailed power-switch drive belongs to Power Electronics, closed-loop speed and position control to Automatic Control, and robotic use to Robotics Engineering.
Unit 1: Actuation and Energy Conversion
An actuator converts power from an energy source into a controllable physical result. Mechanical power is:
P_m=Tωfor rotational motion and:
P_m=Fvfor linear motion.
Selection cannot be based on nominal power alone. Continuous and peak load, speed, acceleration, duty cycle, ambient temperature, mechanical life, power-off behavior, and feedback needs must be evaluated together.
1.1. From Information to Physical Power
The controller produces a low-power reference; the energy source supplies the physical work. This distinction helps diagnose cases where a valid PWM command exists but the actuator cannot produce motion. A command does not prove that the power stage can deliver the required voltage and current.
Actuator selection includes force or torque, speed, stroke, duty cycle, power density, efficiency, maintenance, environment, and safe-state behavior. The same task may be realized by an electric motor, pneumatic cylinder, or hydraulic actuator depending on system constraints.
Unit 2: Requirements and Actuator Selection
A load profile should identify:
position range
speed range
acceleration
continuous load
peak load
operating duration
duty cycle
precision
environment
safe state
Catalog stall torque or short-duration peak force is not a continuous operating point. Thermal time constant and permitted duty must be considered before using peak ratings for sizing.
Actuator selection starts from the load's motion profile over time. Derive instantaneous force or torque from speed, acceleration, and opposing loads, then distinguish continuous from peak duty using the operating cycle. Evaluate reflected inertia, efficiency, and backdrivability when choosing a gear ratio. Verify the selection against drive limits and thermal loading; a choice based only on catalog nominal power may fail during transients.
2.1. Motor Selection Begins with the Load Profile
Average torque is not enough. The motion profile is separated into acceleration, constant-speed, deceleration, and dwell intervals. A thermal RMS torque can be approximated by:
T_rms = sqrt(Σ(T_i^2 t_i) / Σt_i)while manufacturer-specific speed-dependent losses and cooling still need consideration.
Peak torque, speed, and power size the drive; continuous loading sizes the thermal path; stroke and duty cycle influence actuator technology. Safety margin should reflect identifiable uncertainty and transient requirements rather than an arbitrary oversized factor.
Unit 3: Electromagnetic Energy Conversion
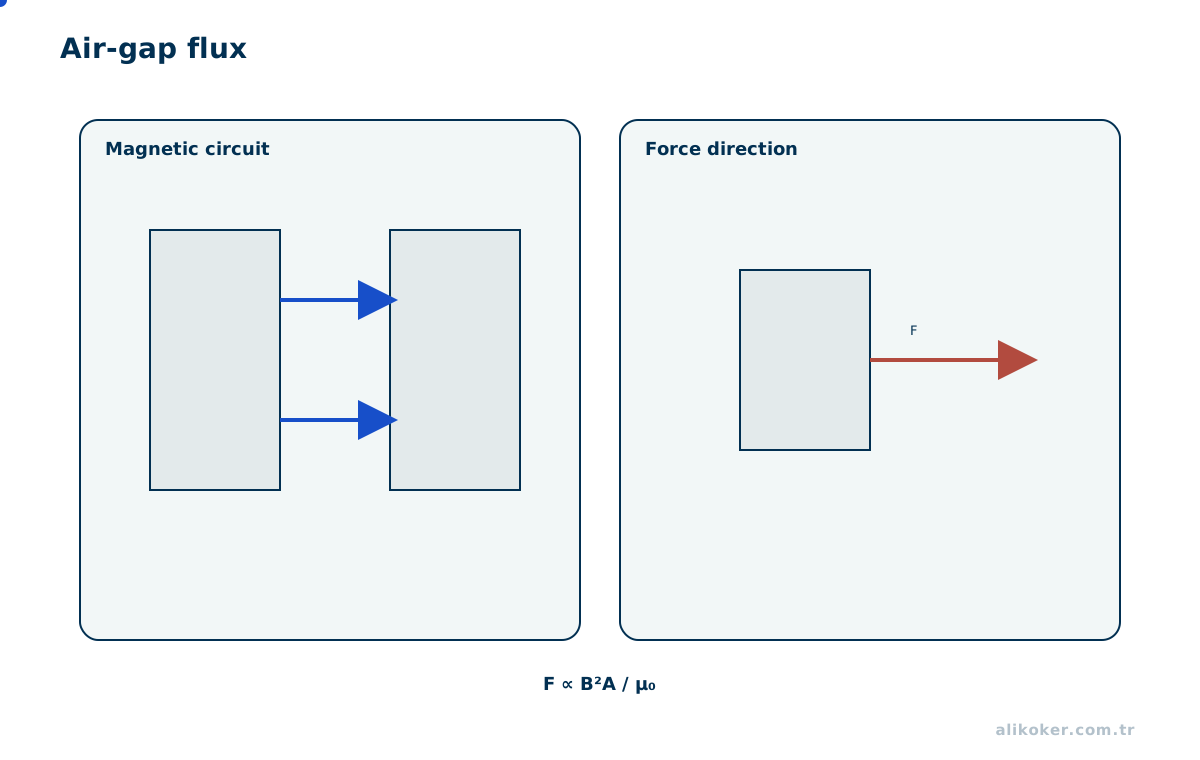
Magnetomotive force is:
F=NIand simplified magnetic reluctance is:
R=(l)/(μ A)giving approximately:
Φ=(F)/(R)Electric machines generate force and torque through interaction of magnetic fields. Saturation, leakage flux, and air gaps are primary departures from an ideal magnetic-circuit model.
3.1. Importance of the Air Gap
Air has far lower magnetic permeability than ferromagnetic core material, so much of a machine's magnetic reluctance can reside in the air gap. Small changes in gap can therefore alter flux, magnetizing current, and force significantly.
Magnetic energy and co-energy provide a useful way to understand force and torque in electromagnets and reluctance machines. Torque can be related to the derivative of magnetic co-energy with rotor position, preventing the oversimplification that current always produces constant torque.
Unit 4: Machine Materials and Thermal Limits
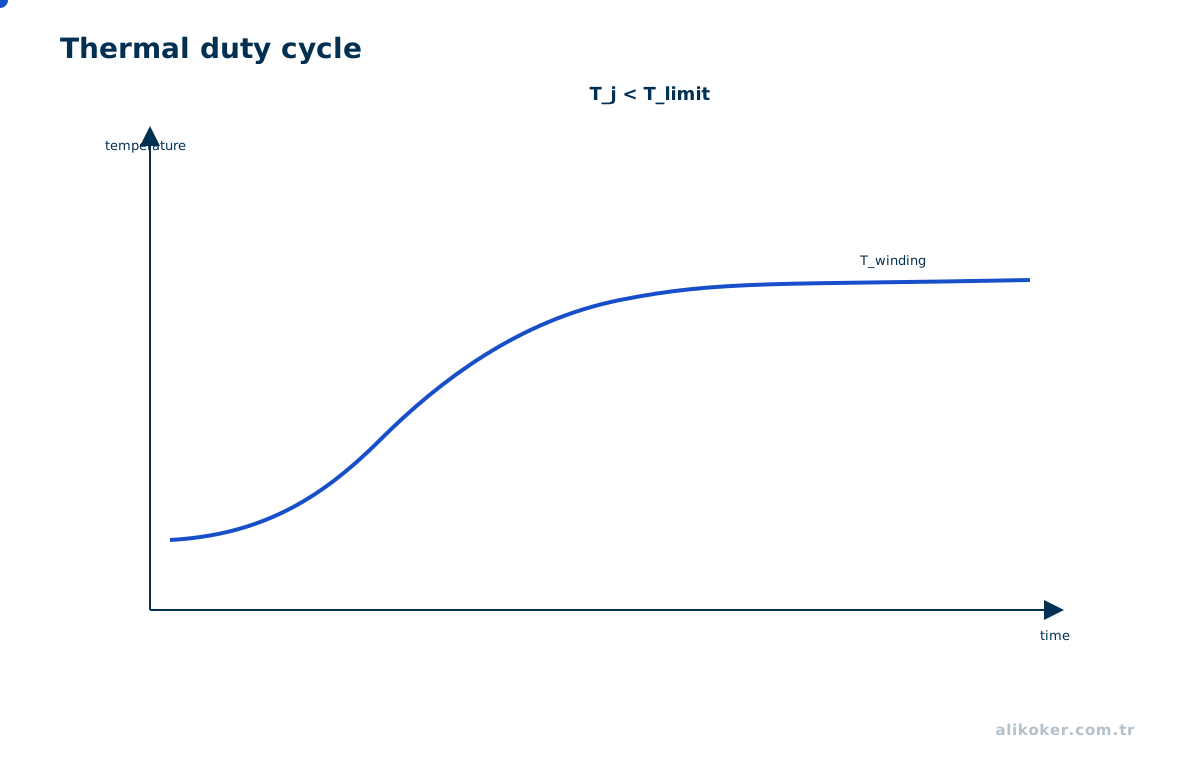
Conductive, magnetic, and insulating materials operate together in an electrical machine. Copper loss is approximately:
P_Cu=I^2Rwhile hysteresis and eddy-current losses occur in the magnetic core. Lamination restricts eddy-current paths.
Insulation class, winding temperature, and cooling determine usable continuous output. A motor that is electrically capable of producing torque may still be thermally unsafe at that operating point.
4.1. Core, Conductor, and Insulation Create a Common Limit
Lamination thickness and electrical-steel properties affect eddy-current and hysteresis loss. At higher electrical frequency, thinner laminations, ferrites, or specialized magnetic materials may be required. Conductor area is selected with current density, slot fill, and heat removal in mind, not DC resistance alone.
Insulation life is strongly temperature dependent. A safe case temperature does not guarantee a safe winding hot spot. Thermal resistance networks and thermal time constants explain why short overload and continuous loading have different limits.
Unit 5: Mechanical Load, Torque, and Inertia
Rotational dynamics may be modeled as:
Jdω/dt=T_m-T_L-BωAcceleration requires torque not only for the external load but also for total inertia.
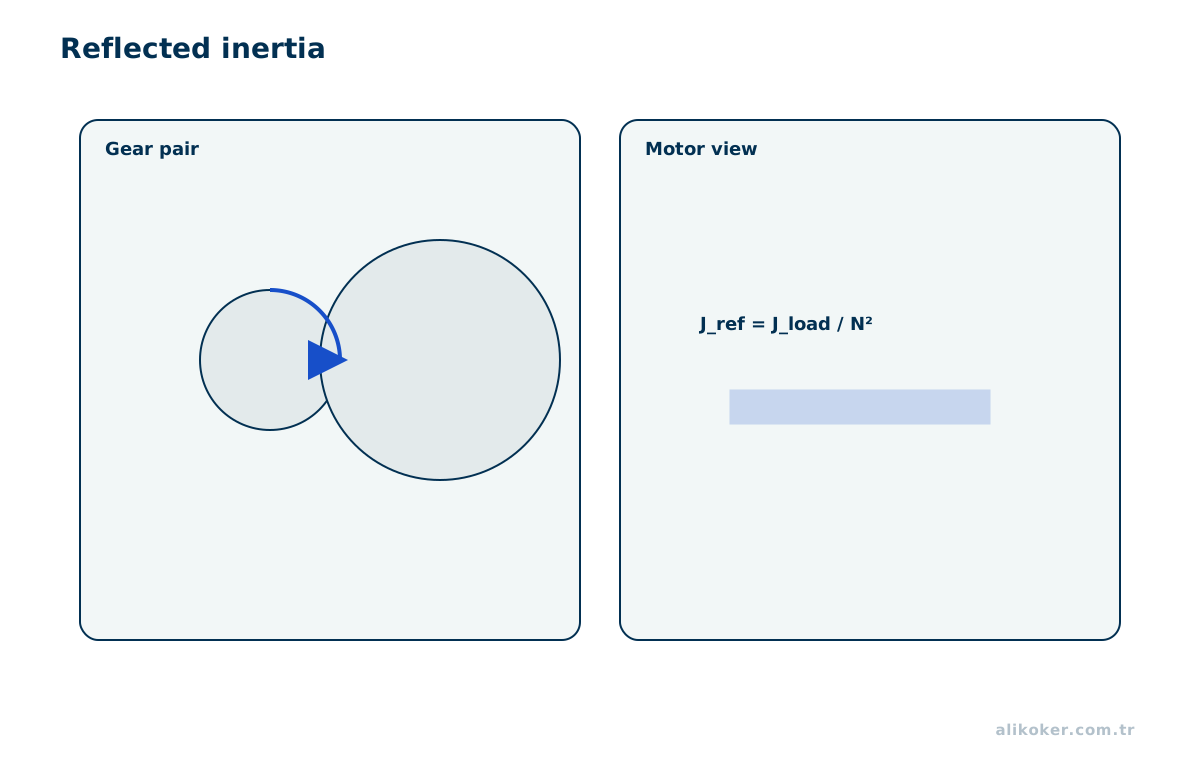
A gearbox transforms torque and speed and reflects load inertia to the motor through the square of the ratio. Motor and gearbox selection are therefore a coupled problem.
Acceleration time for a drive system depends on both total equivalent inertia and available net torque. Subtract opposing load torque from motor torque; if torque varies with speed, a constant-torque assumption cannot represent the full motion range. Recalculate acceleration and time across the speed profile. Comparing the result with current limits, mechanical vibration, and thermal capacity separates theoretically reachable speed from a sustainably safe operating point.
5.1. Reflected Inertia and Acceleration Torque
With gear ratio N, load inertia can be reflected to the motor approximately as J_load/N^2. A larger ratio can reduce reflected inertia but also reduces output speed and changes backlash and efficiency.
Required motor torque can be organized as:
T_motor = T_load + J_eq * dω/dt + T_lossGravity, spring, friction, and process forces should be separated. On a vertical axis, behavior after loss of energy is part of sizing and safety.
Translating linear load requirements into shaft torque. Consider an idealized pulley accelerating a m = 10 kg mass horizontally at a = 2 m/s², against a total resistive force of 15 N, with radius r = 0.05 m. Required tangential force is F = ma + 15 = 35 N, giving load-side torque T = Fr = 1.75 N·m. Corresponding angular acceleration is α = a/r = 40 rad/s². At linear speed v = 1 m/s, angular speed is ω = v/r = 20 rad/s, and instantaneous load-side mechanical power is P = Tω = 35 W. These figures describe only one operating point. Motor selection must additionally account for RMS torque over the duty cycle, peak starting torque, gearbox efficiency, reflected inertia, thermal duty, and design margin. Comparing rated power alone can conceal short-duration torque demand.
5.2. Load Inertia Matching and Acceleration Torque
Rated torque alone is insufficient for selecting a motor. Load inertia reflected to the motor shaft, required acceleration, and transmission efficiency must be considered together. For an ideal gear ratio \(N=\omega_m/\omega_L\), the reflected load inertia is \(J_{L,eq}=J_L/N^2\). A first approximation for acceleration torque is \(T_{acc}=(J_m+J_{L,eq})\alpha_m\); friction, external load, and efficiency must be incorporated separately.
If the combined motor and reflected-load inertia is \(0.002\,\mathrm{kg\,m^2}\) and angular acceleration is \(100\,\mathrm{rad/s^2}\), acceleration alone requires \(0.2\,\mathrm{N\,m}\). This is not the continuous operating torque: acceleration periods, dwell times, braking, and duty cycle determine RMS or an appropriate thermal equivalent. Adequate peak torque does not prove thermal adequacy.
Increasing the gear ratio reduces reflected inertia but changes motor speed, mechanical losses, backlash, and compliance. Minimizing inertia ratio without accounting for control bandwidth and resonance is not necessarily optimal. A complete sizing calculation considers maximum speed, peak and RMS torque, temperature rise, and safe stopping requirements.
Unit 6: DC Machines
For a brushed DC motor:
V_a=R_a i_a+L_a(di_a)/(dt)+e_bwith back EMF:
e_b=K_eωand electromagnetic torque:
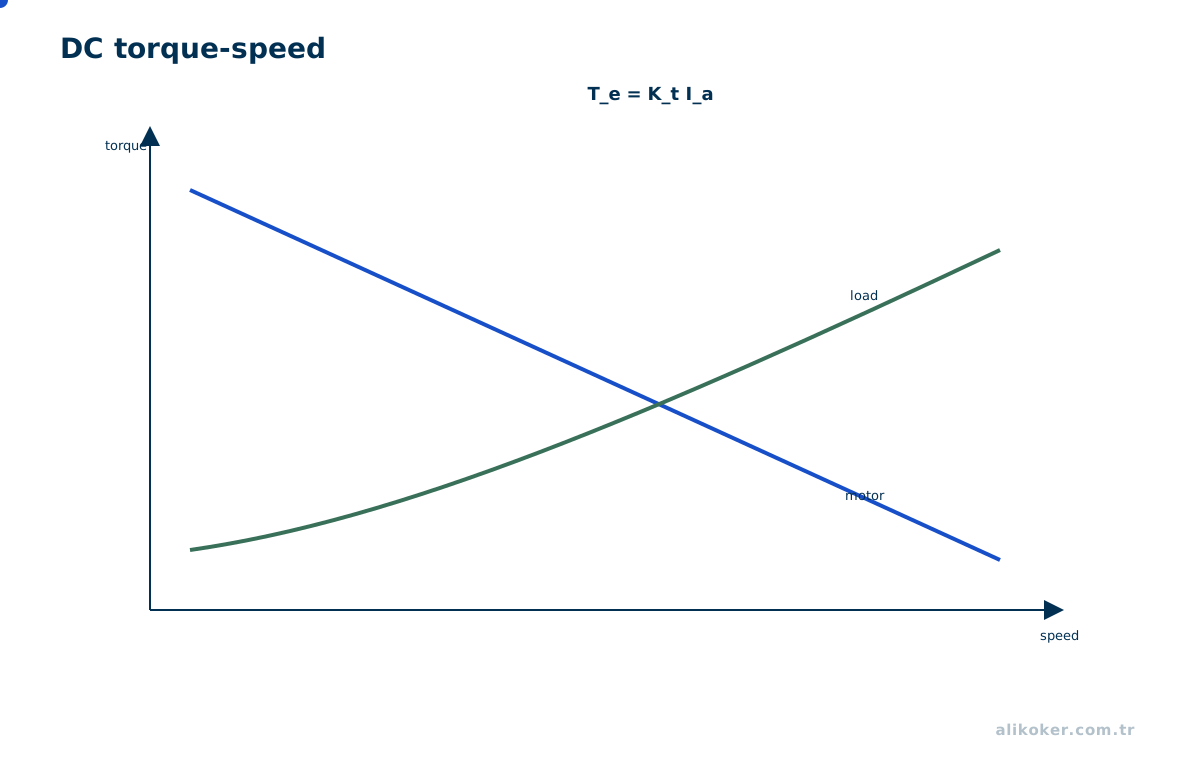
T_e=K_t i_aAt startup, ω≈0, so back EMF is small and:
I_stall≈(V)/(R_a)can be much greater than nominal running current. A power stage sized only from nominal current can therefore fail during startup or stall.
6.1. Torque-speed Characteristic
For a constant-field DC motor at steady state, current is approximately (V-K_eω)/R, and torque is proportional to K_t i. As speed rises, back EMF rises and available current and torque fall, producing the familiar idealized torque-speed line.
At stall, ω=0, back EMF vanishes, and current is mainly limited by winding resistance. At no load, current primarily covers friction and core losses. The rated point lies between these extremes; stall is not a continuous operating condition.
Unit 7: Permanent-Magnet DC Motors
PMDC motors use permanent magnets for the field, eliminating field-winding loss and simplifying many small and medium-power mechatronic drives.
Speed depends on applied armature voltage and load, while torque relates to armature current. PWM can regulate delivered energy while allowing the power switch to operate predominantly in fully on or off states.
Unit 8: Induction Motors
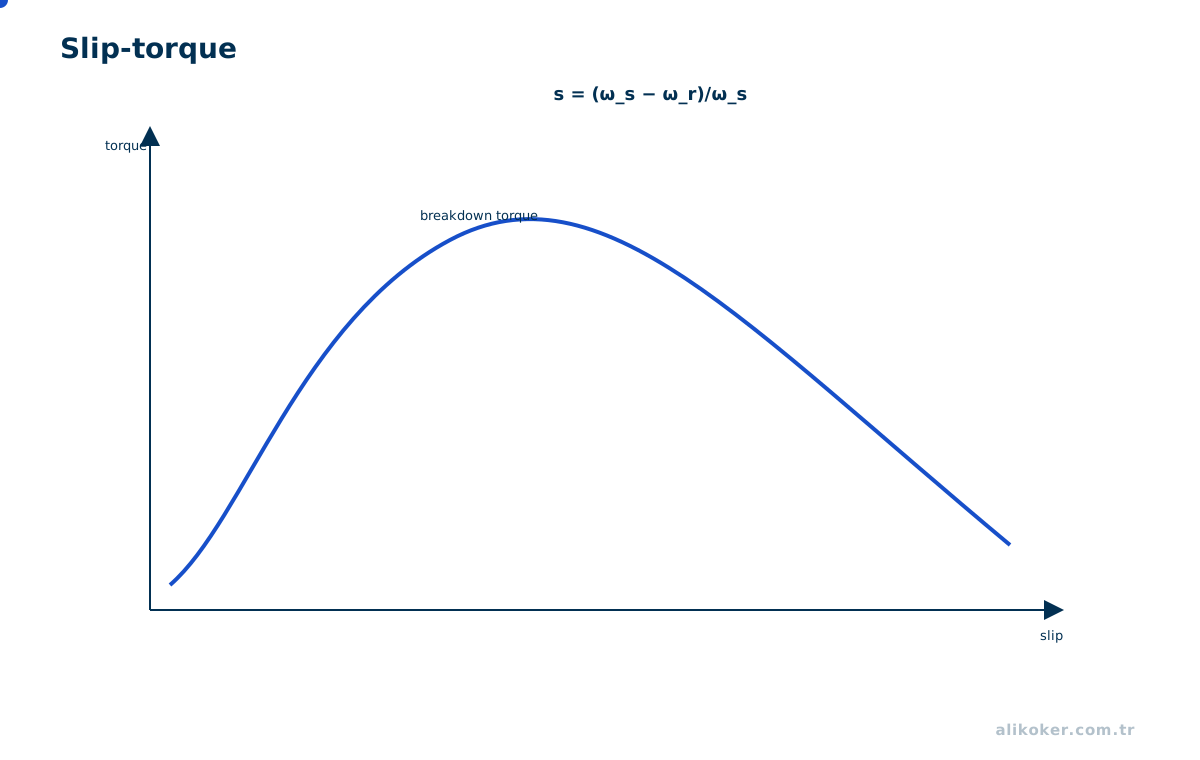
The synchronous speed of a three-phase stator field is:
n_s=(120f)/(p)and slip is:
s=(n_s-n_r)/(n_s)Rotor current is induced by relative motion between rotor and rotating field. Torque-speed behavior, starting current, rotor construction, supply frequency, and voltage all influence application selection. Variable-speed operation uses an inverter to establish the required electrical frequency and voltage.
8.1. Equivalent Circuit and Torque Production
Rotor current is induced because slip creates relative motion between the rotor and the rotating stator field. Near zero slip, rotor frequency approaches zero and little torque-producing rotor current is required. As load rises the rotor slows slightly, slip rises, and electromagnetic torque increases.
The equivalent circuit uses stator resistance/leakage, a magnetizing branch, and slip-dependent rotor terms to analyze operation. Starting current can be high. Inverter drives coordinate voltage and frequency through V/f or vector-control strategies to preserve flux and torque limits.
Unit 9: Synchronous Machines
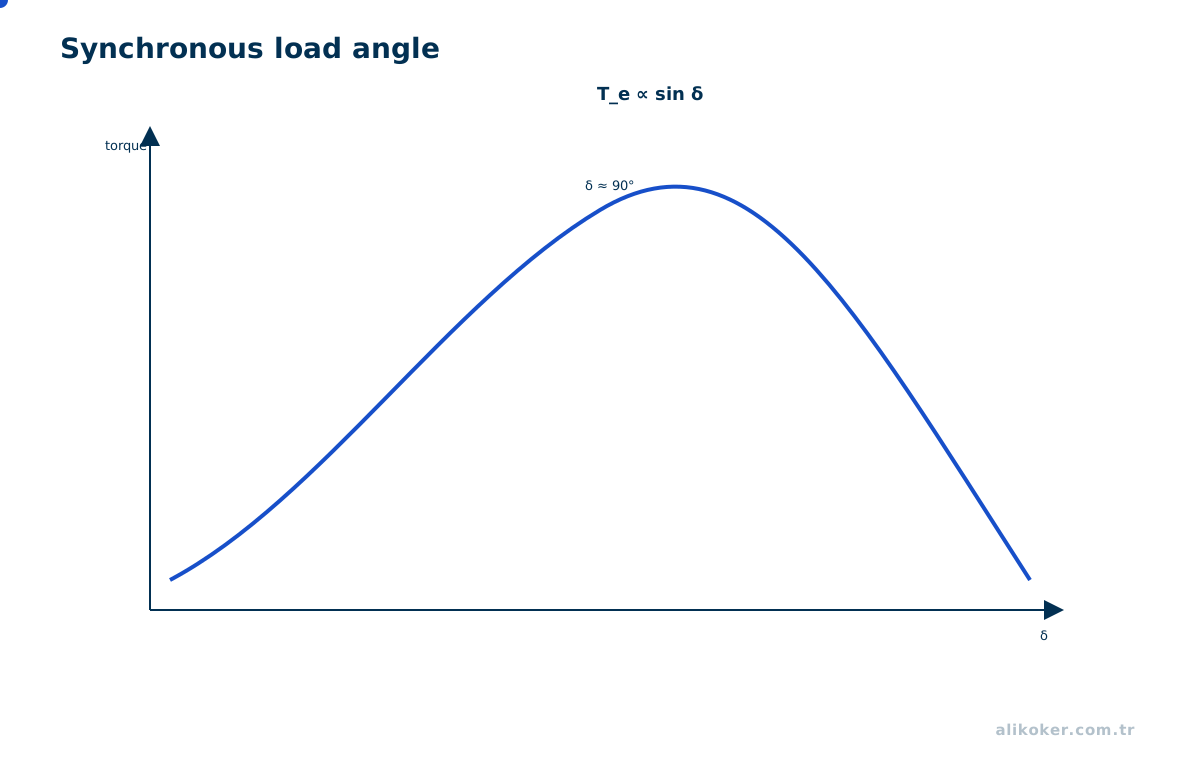
A synchronous-machine rotor field locks to the rotating stator field at synchronous speed. The rotor field may be produced by a field winding or permanent magnets.
Synchronous operation does not imply unlimited load capability. Torque angle, current, and thermal limits constrain the operating region.
9.1. Synchronous Speed and Load Angle
The rotor field rotates at the same average electrical speed as the stator field. Increasing load changes the torque angle rather than creating permanent slip. Beyond the stable torque-angle region, pull-out or loss of synchronism can occur.
Wound-field and permanent-magnet machines share synchronous operation but use different excitation and control. Power factor, field excitation, and inverter current limits shape application behavior.
Unit 10: PMSM and BLDC Motors
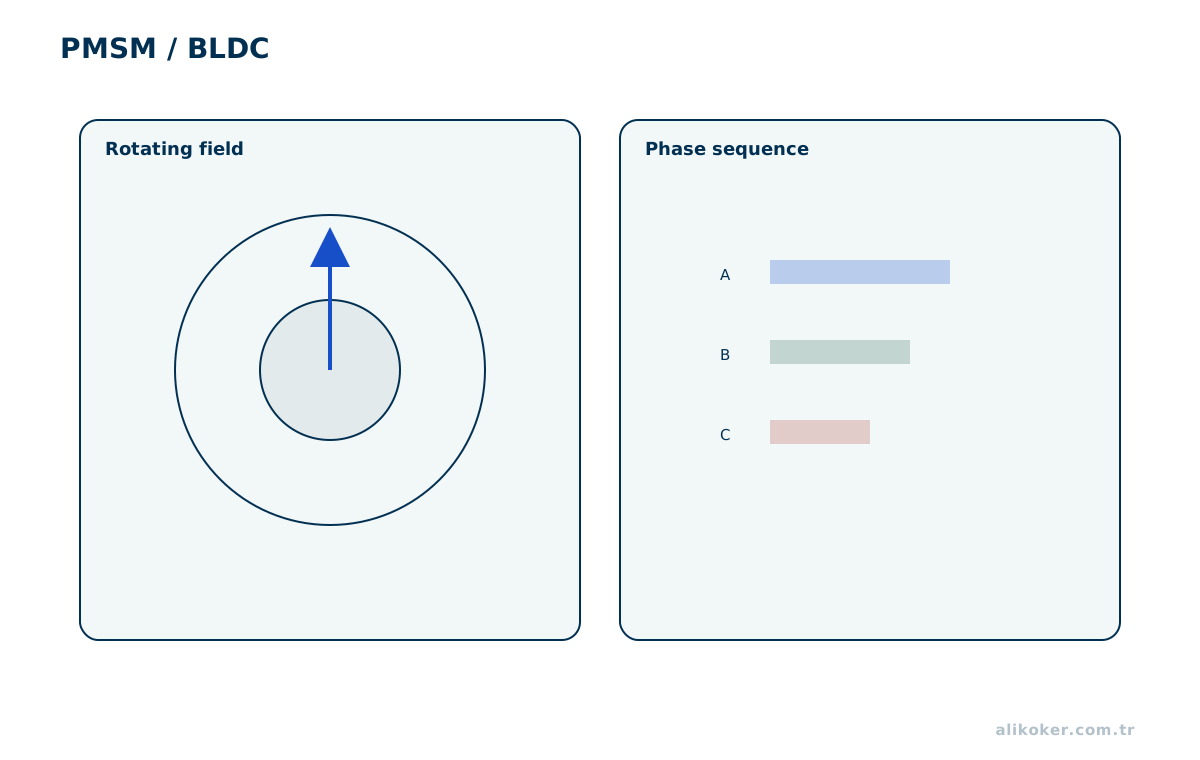
PMSM and BLDC machines use permanent-magnet rotors. Their distinction is largely associated with back-EMF waveform, winding/commutation strategy, and drive method.
A BLDC system contains:
DC source
 -> inverter
 -> phase windings
 -> rotor position / estimation
 -> electronic commutation
Hall sensors can provide low-complexity commutation information, while encoders or resolvers offer finer position feedback. Machine physics is treated here; inverter switching is treated in Power Electronics.
10.1. Commutation and Field Orientation
BLDC drives commonly use trapezoidal back EMF with six-step commutation, while PMSM applications often use sinusoidal currents and field-oriented control. The machine label alone does not uniquely prescribe the drive; winding distribution, actual back EMF, and performance target matter.
Rotor position may come from Hall sensors, encoders, resolvers, or sensorless back-EMF/model-based methods. Back EMF becomes small at low speed, making some sensorless techniques difficult. Inverter dead time, phase-current measurement, and DC-bus variation affect torque accuracy.
Unit 11: Stepper Motors
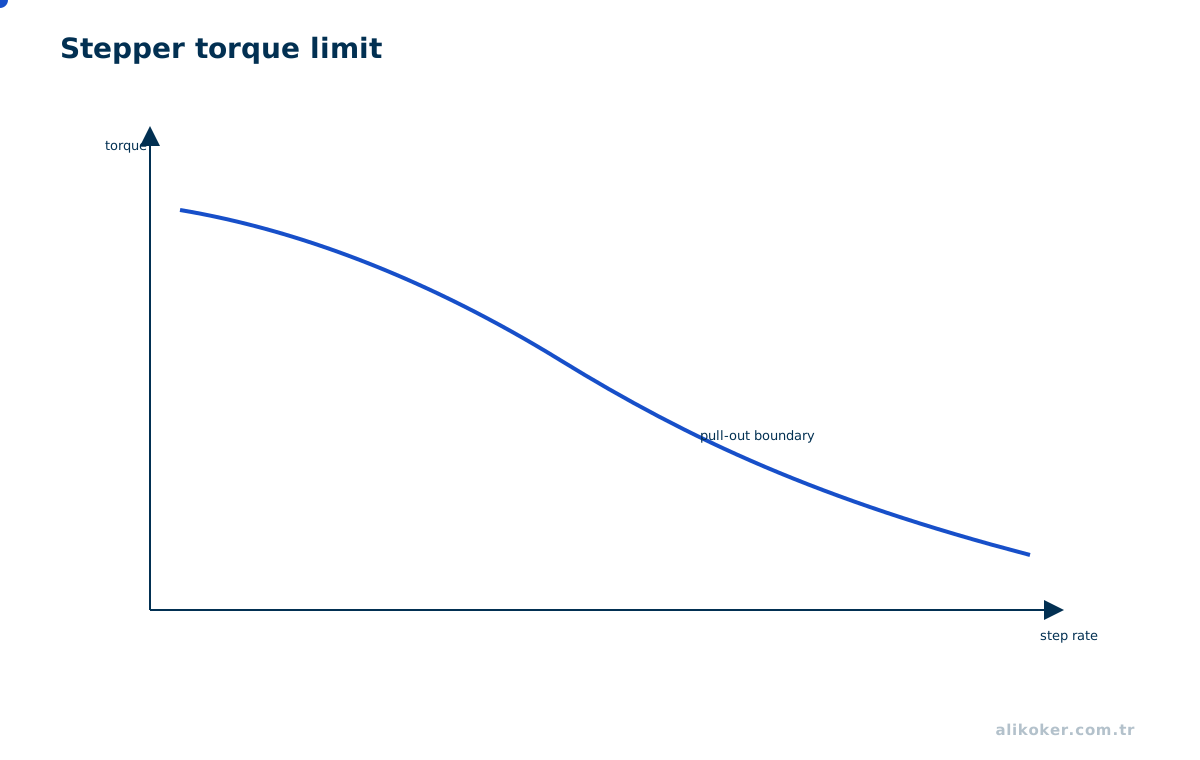
A stepper motor converts command pulses into discrete angular motion. It can be operated open-loop, but counting command pulses does not prove that the rotor actually completed every step.
Overload, aggressive acceleration, and resonance can cause lost steps. Microstepping smooths phase-current references and motion but does not create unlimited mechanical positioning accuracy.
11.1. Dynamic Torque Limit
Holding torque does not describe available torque while moving. As speed increases, winding inductance can prevent current from reaching its target before the next step, reducing torque. This is one reason stepper drives often use higher supply voltage with current-chopper control.
Pull-in and pull-out limits depend on acceleration profile. Commanding a high step frequency directly into a large inertia can lose steps. Resonant regions can be managed through microstepping, damping, and appropriate motion profiles.
Unit 12: Switched-Reluctance Motors
An SRM produces torque by attracting the rotor toward a position of lower magnetic reluctance. The rotor can contain neither windings nor permanent magnets, while phase inductance varies with rotor position.
Correct phase energization requires rotor-angle information or estimation. Turn-on/turn-off angles, current regulation, magnetic saturation, and torque ripple are central drive considerations.
12.1. Position-dependent Inductance
SRM torque uses the change of phase inductance with rotor position. In a simplified unsaturated region:
T ≈ 0.5 i^2 dL/dθThis explains why energizing a phase where dL/dθ is positive produces positive torque.
Saturation, coupling, and actual current shape make the real machine nonlinear. Torque ripple and acoustic noise depend on pole geometry, phase count, current regulation, and commutation timing.
Unit 13: Linear Motors
A linear motor produces electromagnetic force directly along a translation axis rather than converting shaft rotation through a mechanical transmission. Linear induction, synchronous, and reluctance topologies are possible.
Direct force can reduce screws or gears, but long active structures, end effects, magnetic attraction, and thermal distribution become part of the design.
Unit 14: Solenoids and Electromagnets
A solenoid produces linear force by attracting a ferromagnetic moving member with a current-generated field. Force generally increases as the air gap decreases and is nonlinear.
Stored magnetic energy:
E_L=(1)/(2)LI^2must have a safe current path when the drive is turned off. Flyback and clamp design are covered in Power Electronics.
Unit 15: Hydraulic Actuation
For an ideal hydraulic cylinder:
F=pAso force depends on pressure and piston area. High power density is a major advantage, but pumps, valves, leakage, fluid compressibility, temperature, and maintenance all influence system behavior.
Servo or proportional valve dynamics must be considered together with the mechanical load and control loop.
Unit 16: Pneumatic Actuation
Pneumatic systems transmit energy through compressed air. They can be simple, fast, and clean, but air compressibility and pressure variation make precise position control more difficult.
Cylinder position cannot reliably be inferred from valve opening time alone. Air compressibility, seal friction, changing load, and supply pressure can yield different motions under the same command. End-of-stroke design should consider approach velocity and stopping energy, not merely the mechanical stop. When the final position matters, position feedback or explicit end-position confirmation is needed; available pressure alone does not prove that the piston has reached its target.
End-of-stroke impact, flow restriction, valve response, and power-loss behavior must be included in safety analysis.
Unit 17: Piezoelectric and Special Actuators
Piezoelectric actuators generate small but fast and precise deformation under electric field. Stroke may be limited, and high voltage together with capacitive load behavior affects the drive electronics.
Shape-memory alloys, voice coils, and electrostatic microactuators address specialized combinations of force, stroke, speed, and physical scale.
Unit 18: Mechanical Transmission and Load Matching
Direct motor-to-load coupling is not always optimal. Gearboxes, belts, chains, screws, racks, and couplings transform speed, torque, direction, and mechanical impedance.
Load matching should consider continuous and peak torque, speed range, acceleration, reflected inertia, efficiency, backlash, torsional compliance, and mechanical life.
18.1. Gearbox Selection Is More Than Ratio
A reducer must be checked for peak torque, torsional stiffness, backlash, efficiency, and bearing load as well as nominal ratio. In a precision servo axis, small backlash can create visible error during direction reversal. Low-backlash technologies trade against cost, efficiency, and compliance.
Ball screws convert rotation to translation; lead, efficiency, critical speed, buckling, and preload determine the speed-force-precision tradeoff. Motor and transmission should therefore be sized together.
Unit 19: Losses, Efficiency, and Duty Cycle
Machine losses include copper, core, mechanical, and additional stray losses. Efficiency is:
η=(P_out)/(P_in)Short-duration high torque may be possible because of thermal inertia, but repeated operation is governed by RMS current/torque and temperature accumulation. External case temperature is not identical to winding hot-spot temperature.
19.1. Losses Depend on Operating Point
Copper loss rises with I^2R; core loss depends on electrical frequency and flux density; mechanical loss depends on speed, bearings, and ventilation. Efficiency is therefore a map over torque and speed rather than one universal constant.
Winding resistance rises with temperature. A hot motor can have different stall current and copper loss from a cold motor under the same supply. Thermal derating must consider ambient temperature and cooling.
Unit 20: Braking and Regeneration
Stored kinetic energy:
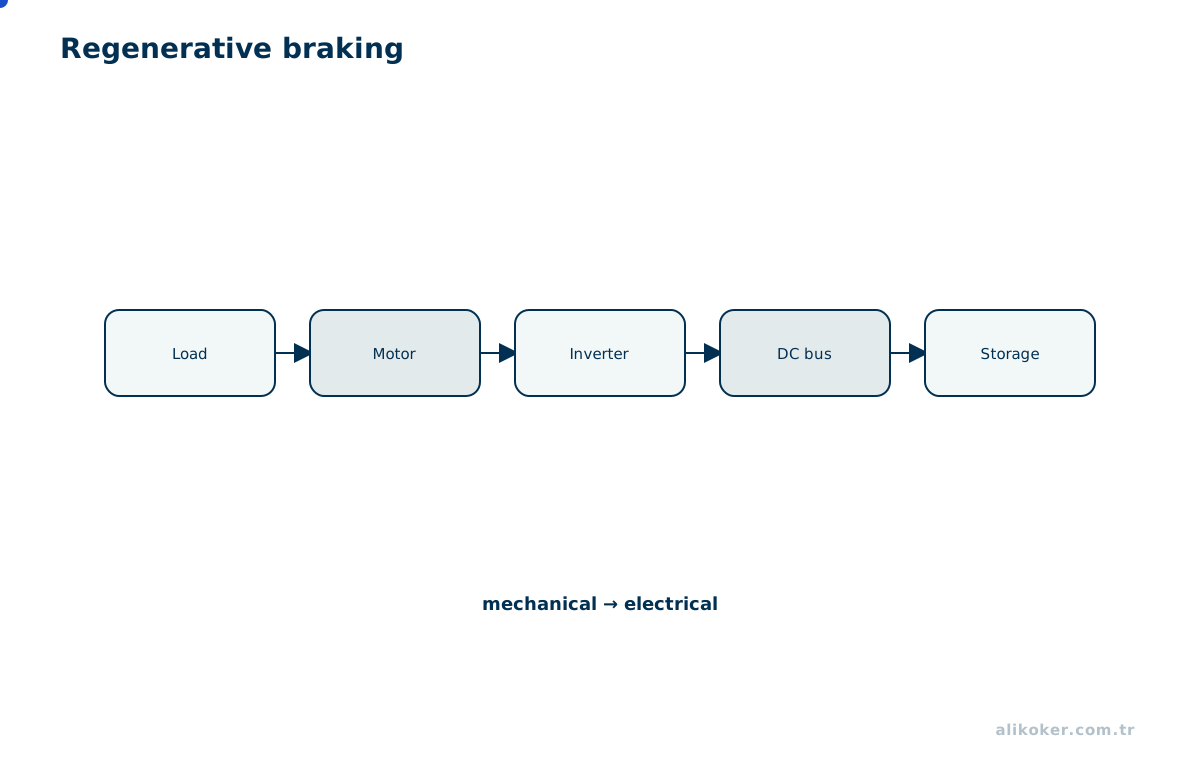
E_k=(1)/(2)Jω^2must go somewhere during deceleration. It may be dissipated as heat or returned electrically to the source.
Dynamic braking, regenerative braking, and mechanical braking serve different purposes. Returning energy to a DC bus that cannot absorb it can raise bus voltage beyond safe limits.
20.1. The Returned Energy Needs a Destination
During deceleration, mechanical energy can be converted back to electrical energy. If the DC bus cannot absorb it, bus voltage rises. A regenerative drive can return energy to the source; otherwise a brake resistor or another dissipative path may be needed.
An emergency stop is not simply PWM=0. Coasting, dynamic braking, and a mechanical brake produce different stop distances and safe-state behavior. Stored mechanical energy must be part of the hazard analysis.
Unit 21: Position and Speed Feedback
Hall sensors, encoders, resolvers, tachometers, and sensorless estimators can provide machine-state information.
Feedback bandwidth, resolution, mounting location, and latency constrain control performance. An encoder on the motor shaft, for example, does not directly observe gearbox backlash at the load.
21.1. Sensor Placement Determines What Is Observed
A motor-shaft encoder measures rotor motion but cannot directly observe gearbox backlash or output compliance. A load-side encoder measures final position but introduces the mechanical resonance into the control path. High-precision systems may use both.
Speed can be estimated from pulse interval or pulse count in a time window. Period measurement can provide better low-speed resolution, while windowed counting may suit higher speed; each creates different latency and quantization behavior.
21.2. Separating motor-shaft Position from Load Position
With a 20:1 reduction gear, a measured motor-shaft change of 0.5° corresponds to 0.025° at the load only under an ideal, backlash-free transmission. If the gearbox has 0.1° of reversal play at the load, higher encoder resolution cannot determine the actual load position within that slack region. The motor may move before the load responds. A small tracking error measured at the motor shaft is therefore not sufficient evidence of accurate output positioning.
Feedback placement determines what the control system can observe. A motor encoder is suitable for fast commutation and speed loops, while an independent load-side sensor can reveal compliance and backlash. With two sensors, flexible-mode resonance must be considered when choosing loop bandwidths; a slower load measurement cannot simply be inserted into the fastest current loop. Verification should include approaches to the same target from opposite directions and simultaneous recording of motor and load positions.
Unit 22: Actuator-Drive Interface
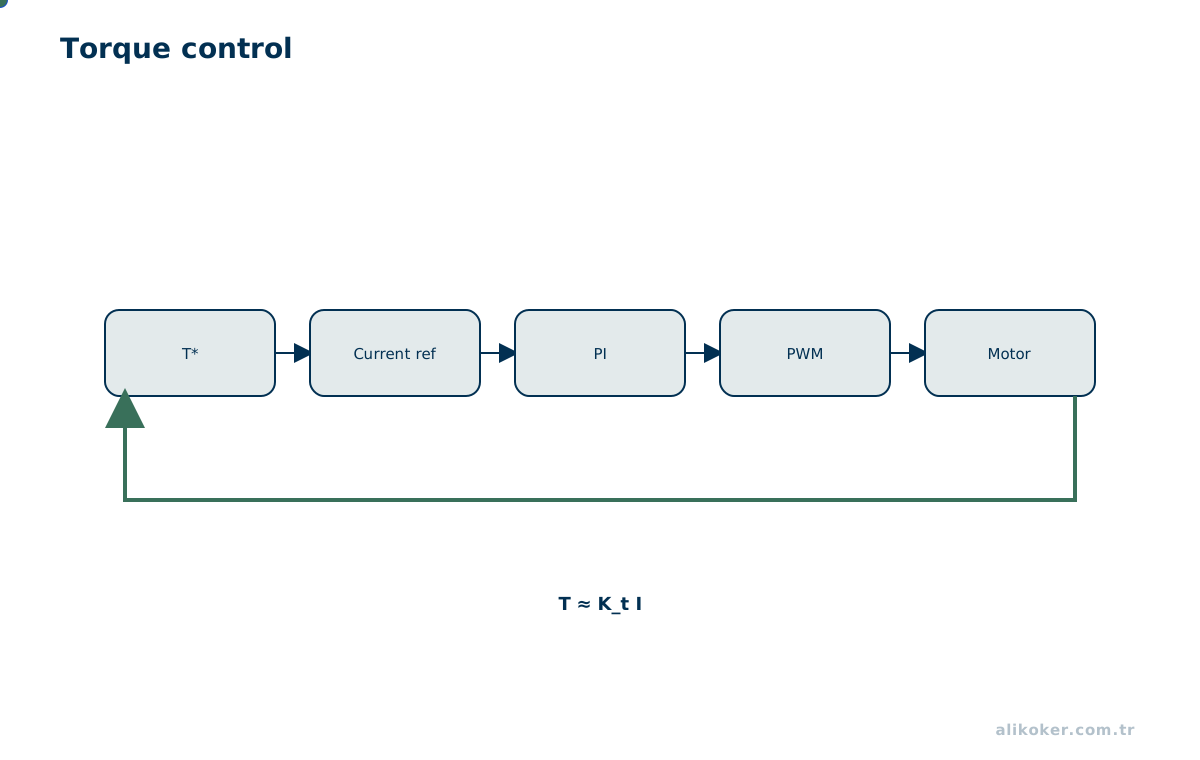
A power drive stands between a controller command and machine current. DC motors may use H-bridges; BLDC/PMSM systems use multiphase inverters; steppers use current-regulated phase drivers.
The drive must manage current limiting, short circuit, overtemperature, undervoltage, and regeneration where applicable. The power stage belongs to Power Electronics, while control-law design belongs to Automatic Control.
22.1. Current Control Is the Foundation of Torque Control
In many electric machines, electromagnetic torque is directly or transform-related to current. Modern drives therefore use a fast inner current loop, with slower speed and position loops outside it. The power stage regulates winding current toward the requested reference.
Drive selection includes peak-current duration, current-sense accuracy, switching frequency, feedback interfaces, braking capability, and fault behavior, not only nominal voltage and current. How the controller responds to a drive fault is part of system safety.
Unit 23: PWM DC-Motor Example
PWM switches energy delivered to the motor. Duty cycle is:
D=(t_on)/(T)Motor speed, however, is not equal to duty cycle. Supply voltage, load torque, winding resistance, back EMF, mechanical losses, and the control architecture determine the operating point. At very low duty, static friction may prevent startup.
Generating PWM with a timer such as the NE555 belongs to Electronics I and II, MOSFET and flyback design to Power Electronics, and motor current-torque-speed behavior to this course.
23.1. PWM Is More Than Average Voltage
At sufficiently high switching frequency, motor inductance smooths current and average armature voltage can be approximated by D*V_bus. At low frequency, low inductance, or rapidly changing load, current ripple and torque ripple become significant.
Raising PWM frequency can move acoustic components upward but increases MOSFET switching loss. Too low a frequency can create visible current and torque pulsation. Frequency is chosen from motor electrical time constant, semiconductor losses, EMI, and acoustic requirements.
Stall current, freewheel path, and drive current limit should be known before the first powered test. Breadboards and thin jumper wires are not suitable high-current motor power paths.
Unit 24: Safe State and Fault Behavior
A stalled motor can draw far more current than its nominal running value. Continuing to command an actuator after sensor loss or mechanical jamming can create thermal or mechanical damage.
A protection architecture may combine current limiting, short-circuit protection, thermal protection, mechanical limits, speed/position plausibility checks, watchdogs, controlled braking, and appropriate fusing. A fuse should not be treated as the only protection against fast semiconductor transients.
24.1. Control Stored Energy During Faults
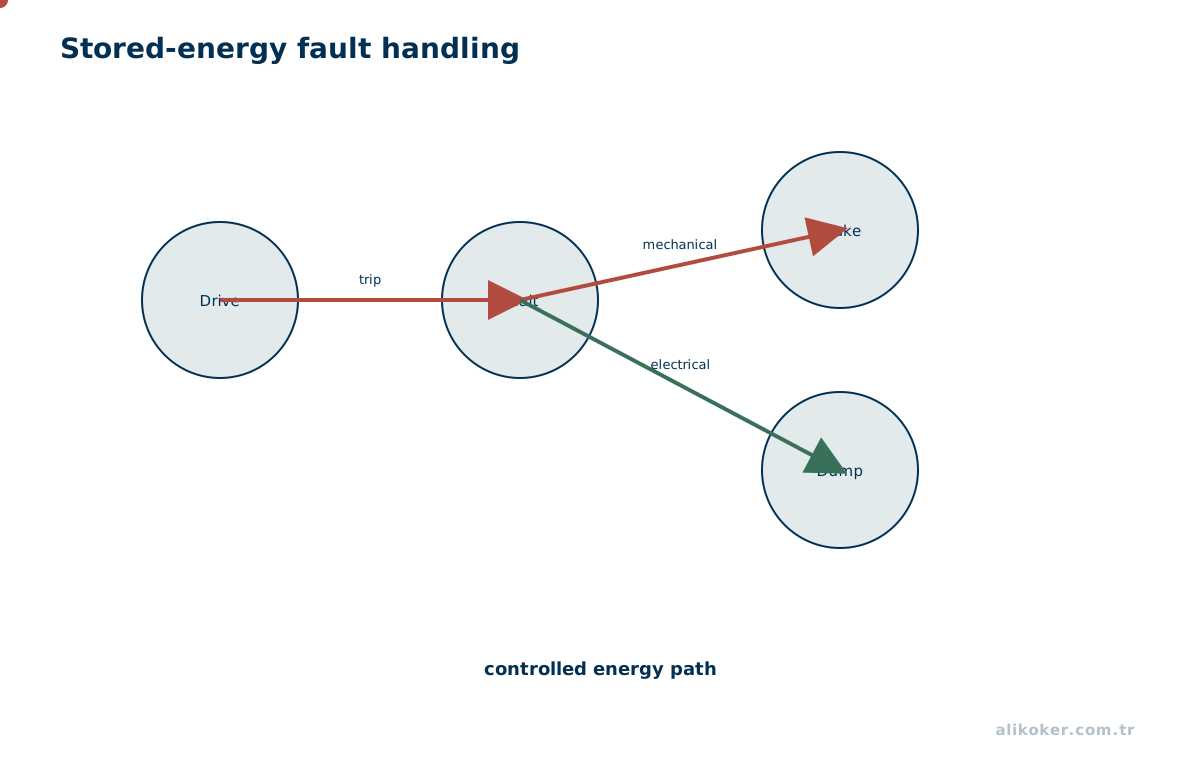
When an actuator fails, stored energy may remain in rotating inertia, elevated loads, compressed fluid, springs, or the DC-link capacitor. Disconnecting the source does not instantly remove that energy.
Fault response may combine current limiting, torque removal, mechanical braking, safe valve position, and controlled discharge. A safety design that depends on one software condition can become a common single point of failure.
Related Courses
- Electronics I and II: semiconductor and basic switching behavior
- Power Electronics: drives, converters, and inverters
- Sensors and Sensing Systems: feedback sensors
- System Modeling and Simulation: electromechanical models
- Automatic Control: current, speed, and position loops
- Robotics Engineering: multi-axis actuation and system integration
Example: Motor and Actuator Sizing
A motor for a linear axis cannot be selected by matching catalog power to nominal load power. The motion profile is defined first. Payload, transmission, friction, gravity, and required acceleration are converted into motor-side torque, then the torque-speed curve is checked at maximum speed.
motion profile
 -> linear force
 -> transmission ratio / efficiency
 -> motor torque and speed
 -> peak + RMS torque
 -> drive peak/RMS current
 -> thermal verification
The drive and supply are then sized. If acceleration or stall demand enters the source current limit, nominal power is insufficient information. During braking, returned energy can raise the DC bus; a brake resistor or regenerative path may be required when the source cannot absorb it.
Final verification includes cold startup, hot motor, maximum payload, and repeated duty cycle. This converts motor selection from one catalog number into an electromechanical and thermal design process.
References
- Bolton, W. Mechatronics: Electronic Control Systems in Mechanical and Electrical Engineering. Pearson, 2011.
- Gürdal, O. Elektrik Makinalarının Tasarımı. Bursa Orhangazi University Press, 2015.
- Isermann, R. Mechatronic Systems: Fundamentals. Springer, 2005.
- Billingsley, J. Mechatronics Experiments with Machine Vision. Springer Nature Switzerland, 2026. DOI: https://doi.org/10.1007/978-3-032-11218-7.